机器人日报
机器人论文日报 — 2026-09-16
🤖 Scanned 278 papers from today’s arXiv announcement (cs.RO / eess.SY / cs.LG), picked 5 for modular & legged robotics — summarized by DeepSeek.
🤖 从今日 arXiv 新论文(cs.RO / eess.SY / cs.LG)中扫描 278 篇,围绕模块化与足式机器人精选 5 篇 — 由 DeepSeek 生成双语摘要。
1. Optimized Wrench Polytope Analysis for Real-Time Stability Control of Legged Robots in Complex Multi-Contact Configurations
面向复杂多接触构型下足式机器人实时稳定控制的优化力旋量多面体分析
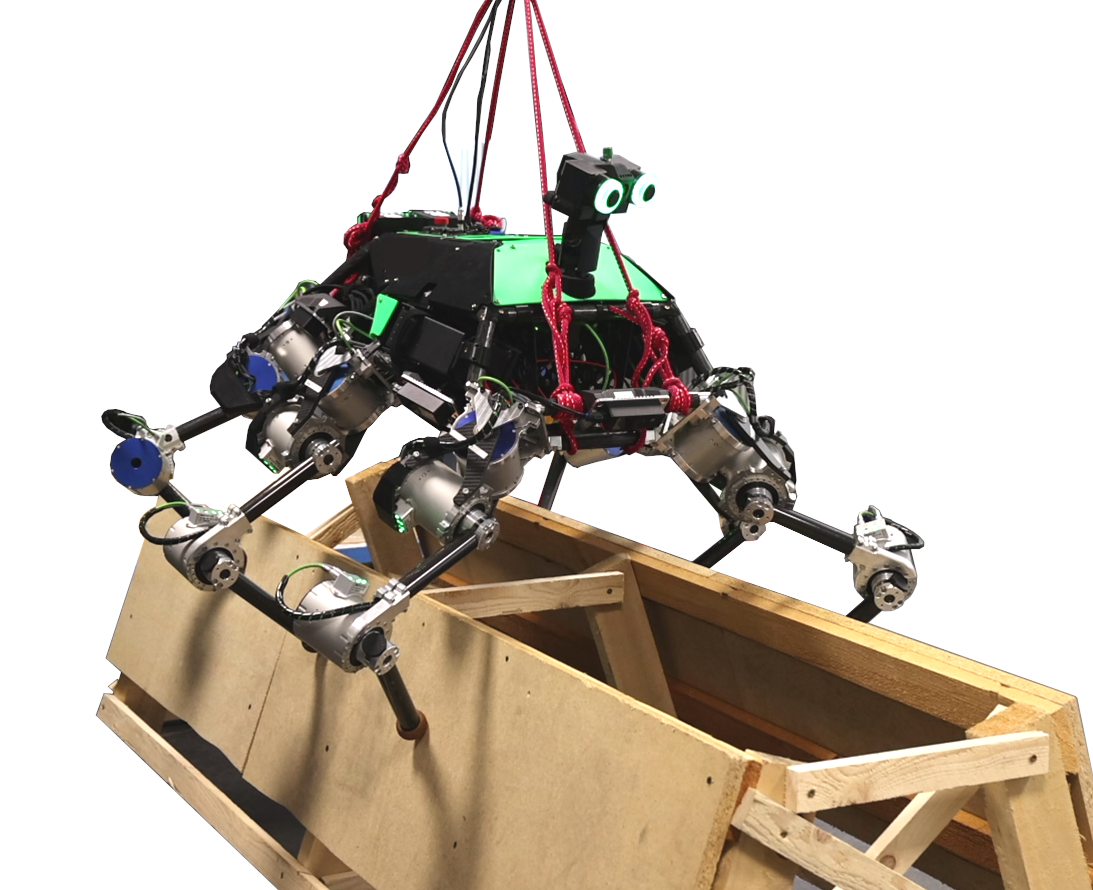
Authors / 作者: Friedrich Graaf, Elias Birkefeld, Christian Eichmann, Elias Hofele, Tristan Schnell, Georg Heppner et al.
arXiv: 2609.17405 · PDF
The paper presents an optimized algorithm to compute the full actuatable wrench polytope for arbitrary contact configurations, enabling joint torque computation at 49 Hz inside a regular control loop. The approach was validated in simulation and on real walking robot hardware, achieving stability in complex scenarios (slopes, caves, scaffolding) not achievable by prior controllers.
中文摘要: 该文提出一种优化算法,用于评估任意接触构型下足式机器人的完整可驱动力旋量多面体,使各关节力矩可在49 Hz的控制频率内实时计算。该算法可嵌入常规控制回路,从而在不同接触场景下驱动机器人位姿。作者在仿真中进行了大量稳定性测试,并在实际行走机器人硬件上验证了其适用性;所提控制器在斜坡、洞穴、脚手架等此前控制器难以应对的复杂场景中实现了稳定控制。
💬 Directly relevant to legged locomotion control: real-time wrench polytope evaluation with hardware validation for challenging multi-contact terrain.
💬 与足式运动控制直接相关:面向多接触复杂地形的实时力旋量多面体评估,并完成硬件验证。
Why read it / 推荐理由: It offers a real-time, hardware-validated stability criterion that can be integrated into MPC/WBC frameworks for modular or multi-legged robots traversing complex terrain. 该工作提供了可实时运行并经硬件验证的稳定性判据,可集成到模块化或多足机器人的MPC/WBC框架中,以应对复杂地形。
2. Fingers as Legs: Learning Self-Supported Locomotion and Manipulation with an Anthropomorphic Hand
手指即腿:利用拟人手学习自支撑运动与操作
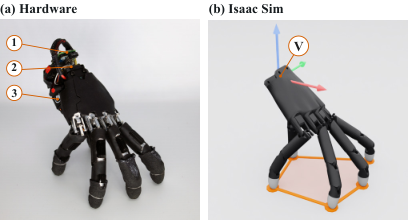
Authors / 作者: Amirhossein Kazemipour, Hehui Zheng, Robert Katzschmann
arXiv: 2609.17172 · PDF
The authors train an anthropomorphic robotic hand, using reinforcement learning with a simulator calibrated from hardware, to reuse its fingers for self-supported crawling, steering, fall recovery, and object pushing. The hand also executes keyboard commands without vision and uses overhead visual feedback for manipulation, demonstrating a compact mobile manipulator without a separate locomotion mechanism.
中文摘要: 本文研究一种拟人机械手,使其在保留手指设计与位置控制器的前提下,利用同一组手指完成移动、支撑体重和与环境交互。作者采用强化学习方法,考虑手指的不对称性,并在根据硬件测量校准的仿真器中训练。仿真结果表明,所提奖励公式使手部移动速度快于为四足机器人调优的奖励设计。在真实硬件上,任务专用策略实现了无缆爬行、转向和跌倒恢复;手部在支撑自身重量的同时,还能在无视觉条件下执行连续键盘指令,并利用俯视视觉反馈将物体推至目标位置。这展示了一种无需独立移动机构的紧凑型移动操作平台。
💬 Novel embodiment that borrows quadruped RL reward design for a hand, with real-robot results in locomotion and manipulation.
💬 新颖的具身形式,将四足RL奖励设计迁移至机械手,并在真实机器人上实现了运动与操作。
Why read it / 推荐理由: Useful for modular legged robotics researchers as it shows how RL policies and contact-rich control can be transferred to unconventional limb configurations and validated on hardware. 对模块化足式机器人研究者有参考价值:展示了RL策略与富接触控制如何迁移到非常规肢体构型并在硬件上验证。
3. Collision-Aware Humanoid Whole-Body Control under Imperfect Tracking Targets
不完美跟踪目标下的碰撞感知人形全身控制
Authors / 作者: Mohitvishnu S. Gadde, Ashish Malik, Pranay Dugar, Aayam Kumar Shrestha, Alan Fern
arXiv: 2609.16405 · PDF
The paper proposes RECAL, a Robot-Environment Cross-Attention Layer that wraps a blind whole-body controller to trade off target tracking and collision avoidance using scene point clouds, including held objects. In simulation it improves collision avoidance while preserving tracking across locomotion, carrying, and manipulation, and is demonstrated on a real Digit V3 humanoid.
中文摘要: 本文提出RECAL,即机器人-环境交叉注意力层,用于包裹一个不感知场景几何的全身控制器(WBC),利用外部场景几何在目标跟踪与避碰之间进行权衡。RECAL支持浮动基座与末端执行器指令的碰撞感知跟踪,并包含对持握物体的避碰。该方法将机器人、持握物体和环境表示为点云,通过机器人/物体点与环境点之间的交叉注意力生成几何感知的控制特征。仿真中,RECAL在冻结臂与自适应臂运动、物体搬运和站立操作等场景下,相比其他几何感知WBC架构,在保持跟踪性能的同时提升了避碰能力。作者进一步在真实Digit V3人形机器人上验证了该控制器。
💬 Provides a geometry-aware wrapper for WBC that is orthogonal to the controller and validated on real humanoid hardware.
💬 提出一种与底层控制器正交的几何感知WBC封装层,并在真实人形硬件上验证。
Why read it / 推荐理由: Directly applicable to whole-body control of legged robots: it shows how to make a blind WBC collision-aware using cross-attention, with real-robot demonstration. 可直接应用于足式机器人全身控制:展示了如何利用交叉注意力使盲式WBC具备碰撞感知能力,并给出真实机器人验证。
4. WholeBodyWAM: Generalizing Pre-trained World-Action Priors to Humanoid Loco-Manipulation via WBC-Grounded Coordination
WholeBodyWAM:通过基于WBC的协调将预训练世界-动作先验泛化至人形移动作业
Authors / 作者: Zhuo Li, Yiming Yao, Jim Tan, Mengjie Jing, Zhipeng Dong, Fei Chen
arXiv: 2609.16644 · PDF
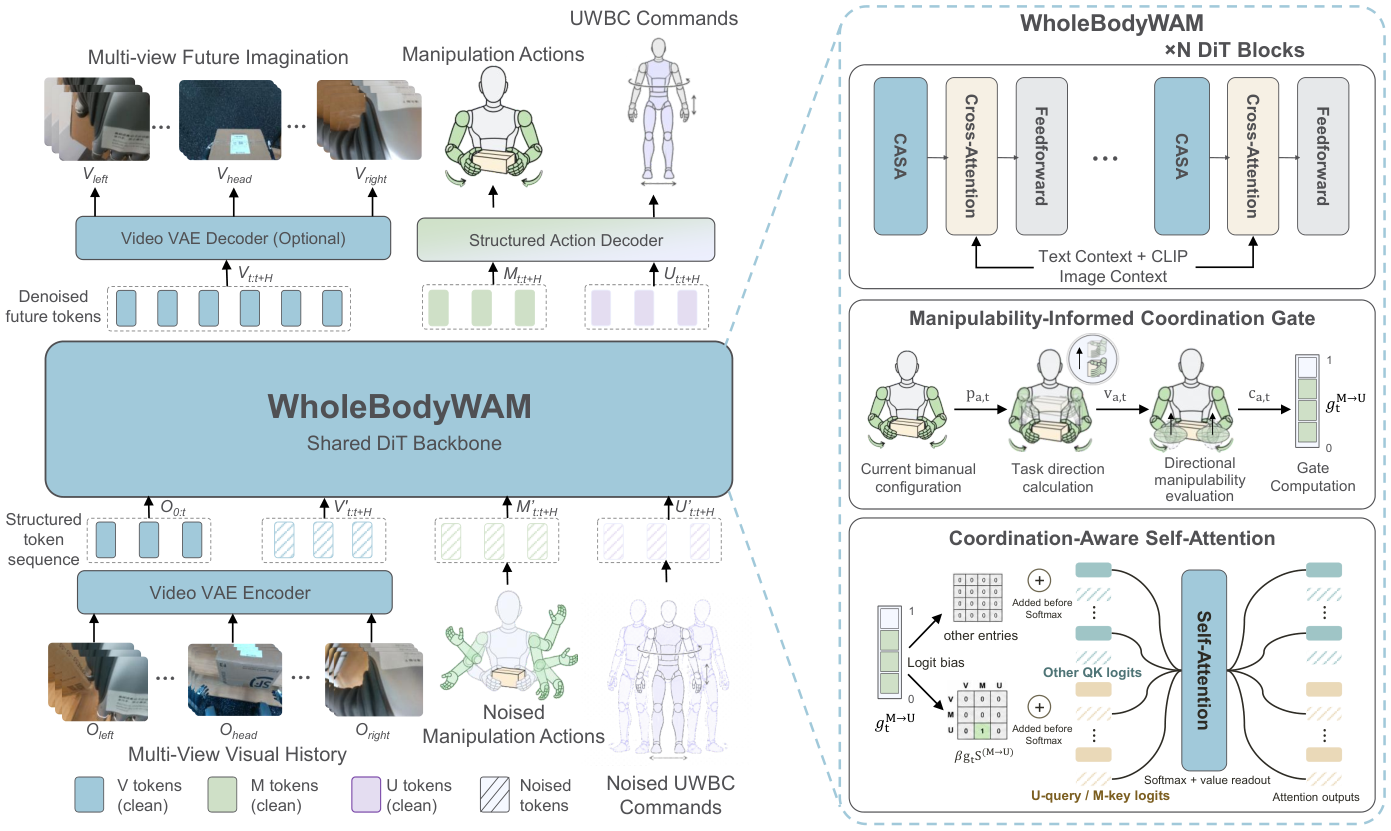
WholeBodyWAM jointly predicts future visual dynamics, manipulation actions, and whole-body control intents for humanoid loco-manipulation, grounding pre-trained world-action priors to heterogeneous WBC semantics. It achieves 91.9% simulation success, a 0.23 improvement in real-world out-of-distribution task progress, and 70% reduction in success-rate variance across WBCs.
中文摘要: 本文提出WholeBodyWAM,面向人形机器人的移动操作,联合预测未来视觉动态、操作动作和全身控制意图。该方法在保留预训练世界-动作先验的同时,将其与异构全身控制器(WBC)语义对齐,并协调全身行为。大量实验表明,WholeBodyWAM在仿真中总体任务成功率达到91.9%,真实世界分布外任务进展提升0.23,跨不同WBC的成功率方差降低70%。这些结果表明,通过结构化的WBC对齐与协调来扩展预训练世界-动作先验,而非从头重新学习全身行为,是迈向可扩展人形全身智能的一条路径。
💬 Shows how to ground world-action priors into WBC intents for humanoid loco-manipulation, with strong sim and real-world results.
💬 展示了如何将世界-动作先验与WBC意图对齐以用于人形移动操作,并取得优异的仿真和真实世界结果。
Why read it / 推荐理由: Relevant for WBC and loco-manipulation researchers: it addresses WBC heterogeneity and generalization, with a clear sim-to-real pipeline. 对WBC与移动作业研究者有参考价值:解决了WBC异构性与泛化问题,并给出清晰的仿真到真实迁移流程。
5. Continual Learning for Traversability Prediction with Uncertainty-Aware Adaptation
面向可通行性预测的持续学习与不确定性感知自适应
Authors / 作者: Hojin Lee, Yunho Lee, Daniel A Duecker, Cheolhyeon Kwon
arXiv: 2609.17141 · PDF
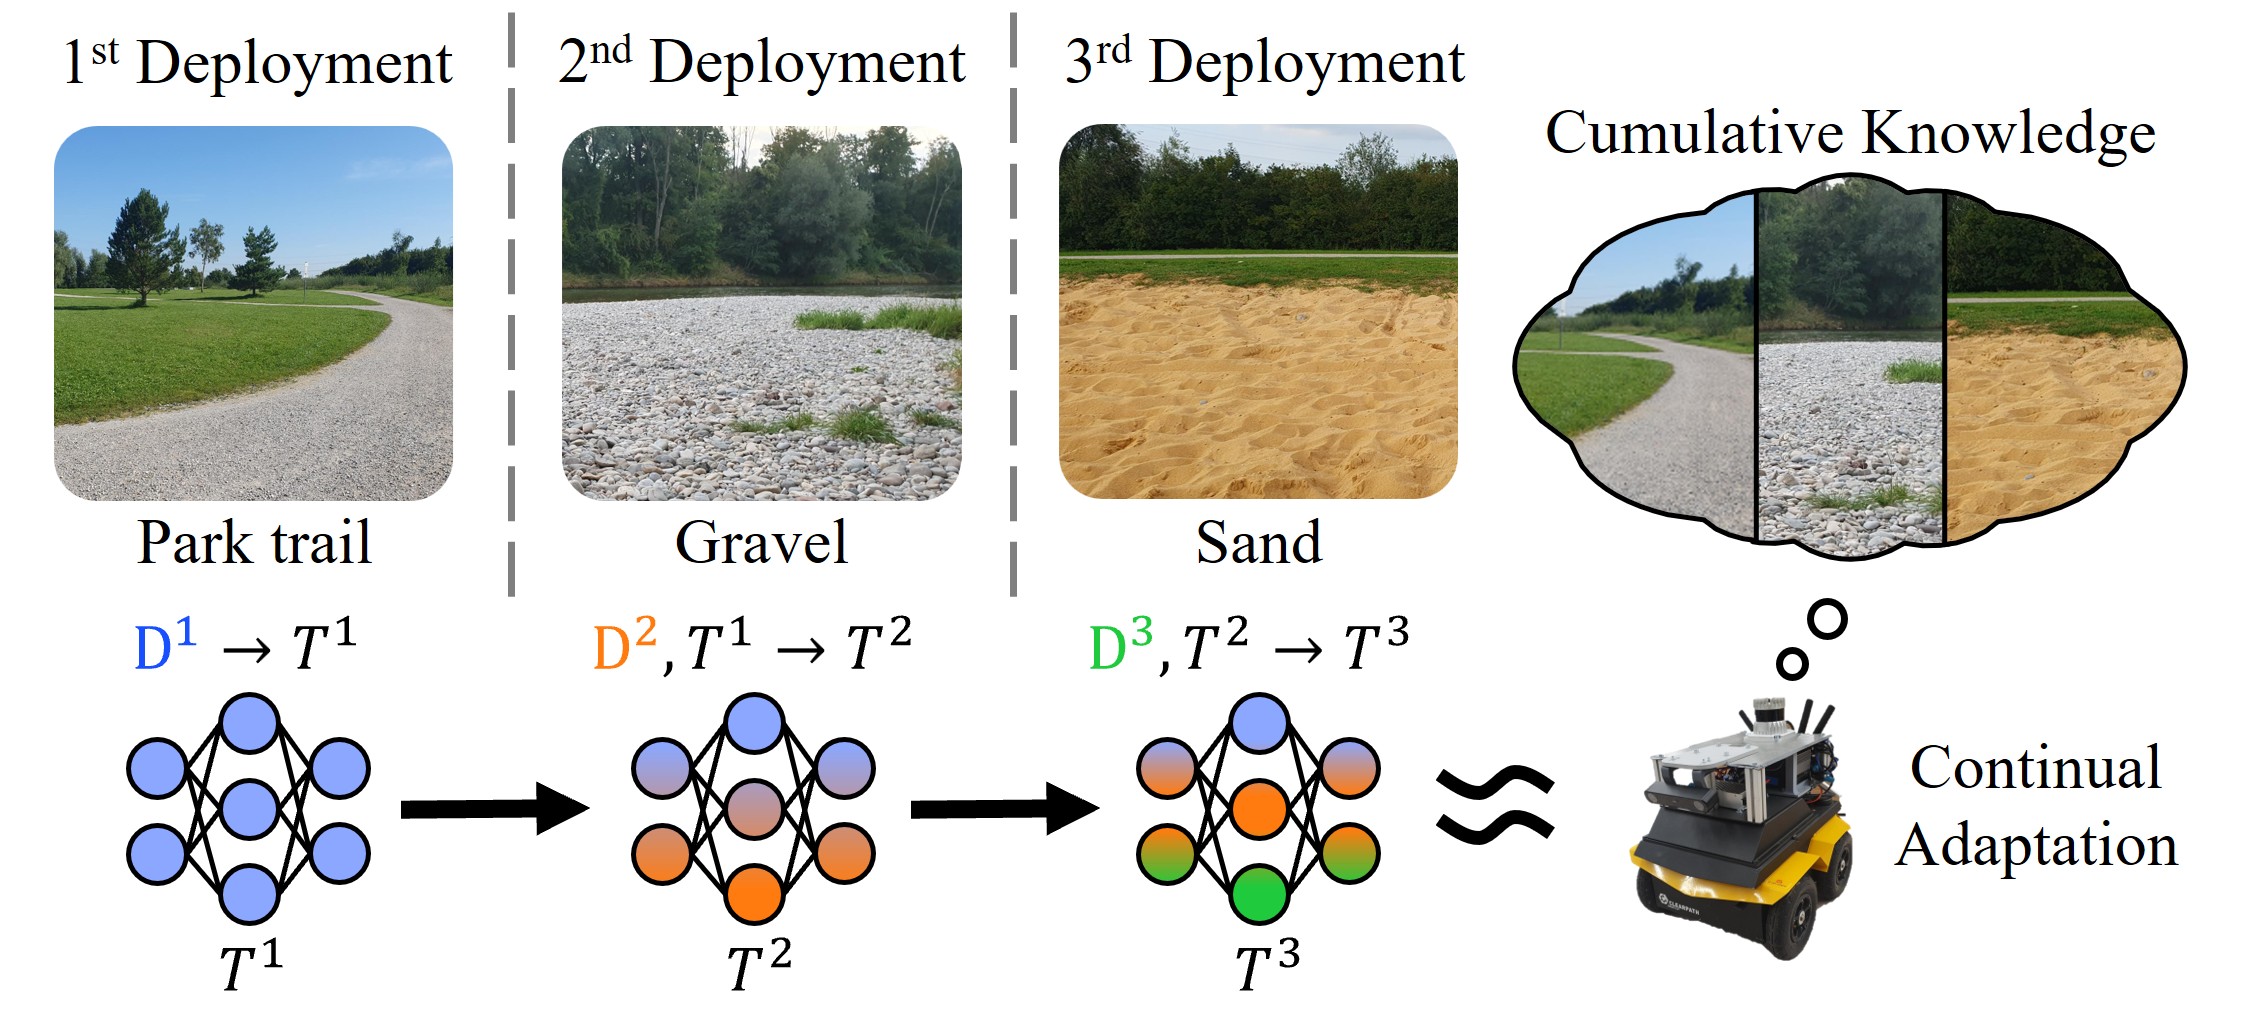
The paper proposes a continual learning framework for traversability prediction that incrementally adapts to new terrains using a generative experience recall model, avoiding storage of past data and incorporating uncertainty for adaptation. Real-world experiments on a skid-steering robot demonstrate adaptation across diverse environments while mitigating catastrophic forgetting.
中文摘要: 本文提出一种用于可通行性预测的持续学习框架,利用生成式经验回放模型增量适应新地形,无需存储过往数据,并引入回放样本的不确定性以实现不确定性感知的自适应。该框架的两个关键优点是:i)不存储历史数据即可保留先前经验;ii)融合回放模型生成样本的不确定性,实现不确定性感知的适应。在滑移转向机器人上的真实世界实验表明,该框架能够在多种环境中连续适应,同时缓解灾难性遗忘。
💬 Directly addresses traverse-capability-aware path planning with real-robot validation and a continual learning angle.
💬 直接针对可通行性感知路径规划,结合真实机器人验证与持续学习视角。
Why read it / 推荐理由: For a researcher working on traverse-capability-aware planning, this offers a data-efficient continual learning method with uncertainty and real-world robot experiments. 对研究可通行性感知规划的研究者而言,该方法提供了数据高效的持续学习方案,并融合不确定性且完成真实机器人实验。