机器人日报
机器人论文日报 — 2026-09-07
🤖 Scanned 264 new arXiv papers (cs.RO / eess.SY / cs.LG, last 96 h), picked 5 for modular & legged robotics — summarized by DeepSeek.
🤖 扫描了近 96 小时 arXiv(cs.RO / eess.SY / cs.LG)的 264 篇新论文,围绕模块化与足式机器人精选 5 篇 — 由 DeepSeek 生成双语摘要。
1. Headroom-Aware Stochastic Adaptive Model Predictive Control for Load Frequency Control in Microgrids
Headroom-Aware Stochastic Adaptive Model Predictive Control for Load Frequency Control in Microgrids
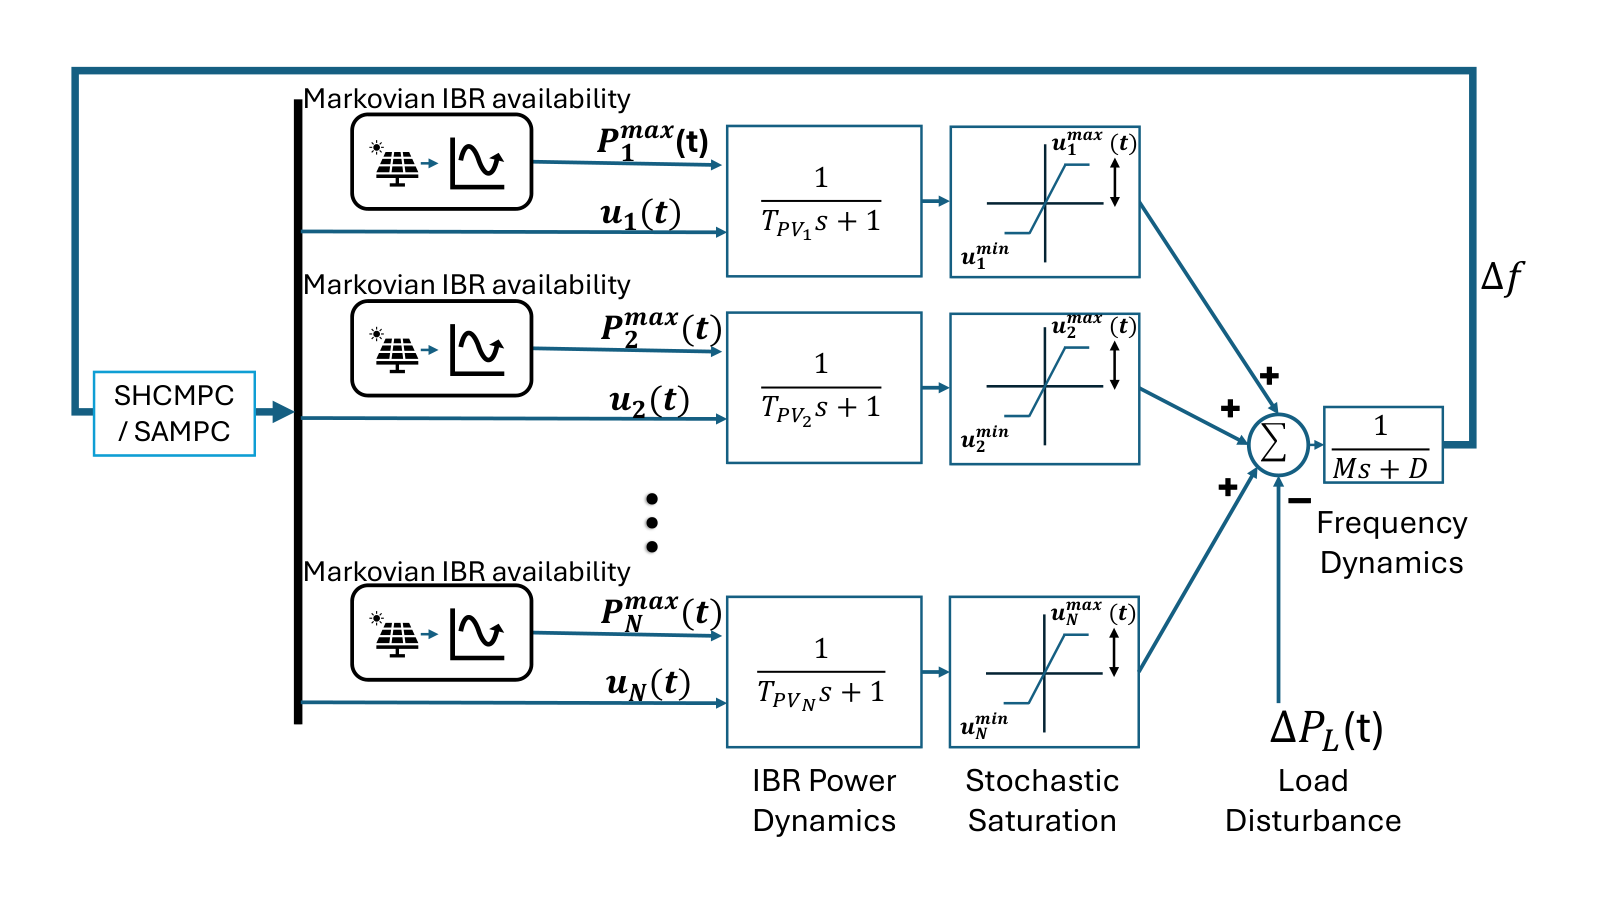
Authors / 作者: Erfan Mehdipour Abadi, Shuo Yuan, Le Yi Wang, Caisheng Wang, Feng Lin
arXiv: 2609.05332 · PDF
As the penetration of inverter-based resources (IBRs) increases in microgrids, they are increasingly expected to play a greater role in load frequency control (LFC). Model predictive control (MPC) is attractive for LFC because it incorporates system dynamics and operational constraints. However, most MPC-based LFC formulations rely on fixed reserve headroom based on forecasted renewable availability or storage systems. Under short-term renewable intermittency, IBR headroom is stochastic and time-varying, causing optimal control commands to exceed the physically deliverable regulation capabilit
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
2. Modular Deep Recurrent Neural Network: Application to Quadrotors
Modular Deep Recurrent Neural Network: Application to Quadrotors
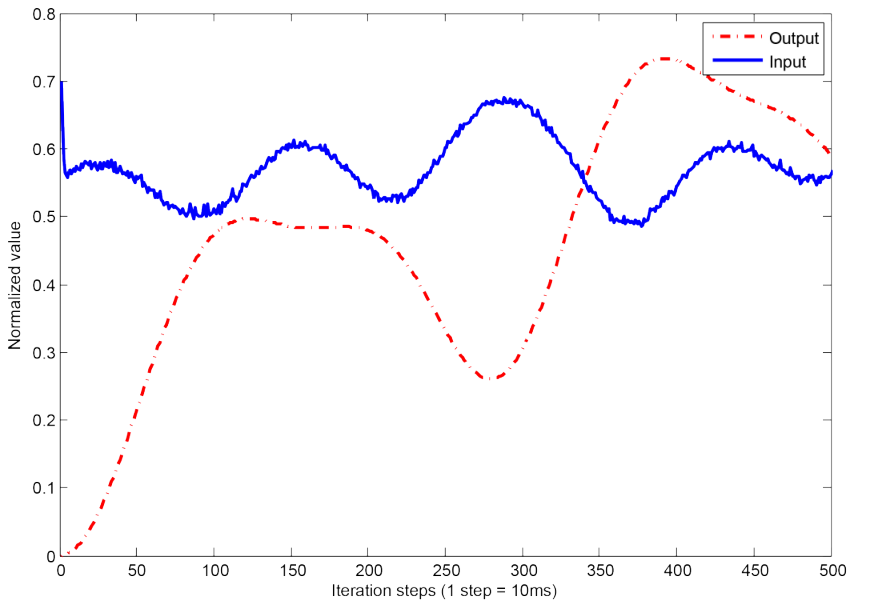
Authors / 作者: Nima Mohajerin, Steven L. Waslander
arXiv: 2609.04339 · PDF · citations: 23
A modular deep Recurrent Neural Network (RNN) is introduced to facilitate the process of deploying various architectures of RNNs, and to automatically compute derivatives for gradient-based learning methods. The modularity leads to a set of new architectures, one of which includes feedforward inter-layer connections. By adding feedforward inter-layer connections in a multi-layer RNN, it is observed that the capability of the RNN to learn and model high-order dynamics and nonlinearities is significantly improved. The problem of vanishing/exploding gradient in space for a multilayer RNN is also
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
3. Morphology and actuation as inductive biases in robotic hand manipulation
Morphology and actuation as inductive biases in robotic hand manipulation
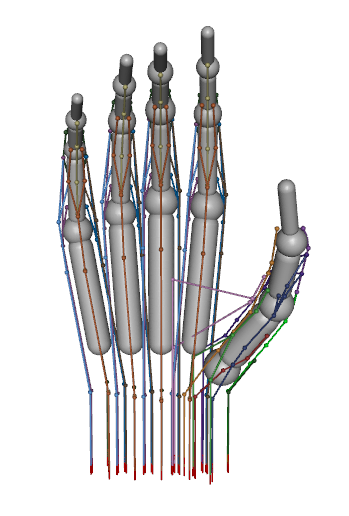
Authors / 作者: Zalán Tari, Eszter Birtalan, Péter Polcz, Miklós Koller
arXiv: 2609.05206 · PDF
Robotic hands vary widely in anatomical fidelity and mechanical complexity, and these structural choices influence the coordination of joint motions and the difficulty of controlling the system. A unified framework is presented in which the kinematic and actuation stages are analysed separately and in composition, through the conditioning of the task Jacobian, the actuation matrix, and their product. It is applied to two hands representing opposing design philosophies, the Shadow Dexterous Hand and the Anatomically Correct, Biomechatronic Hand, along four morphological aspects: joint axis geom
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
4. Grid-Mode-Aware Model Predictive Control of Hybrid Energy Storage Systems for AI Data Center Power Smoothing
Grid-Mode-Aware Model Predictive Control of Hybrid Energy Storage Systems for AI Data Center Power Smoothing
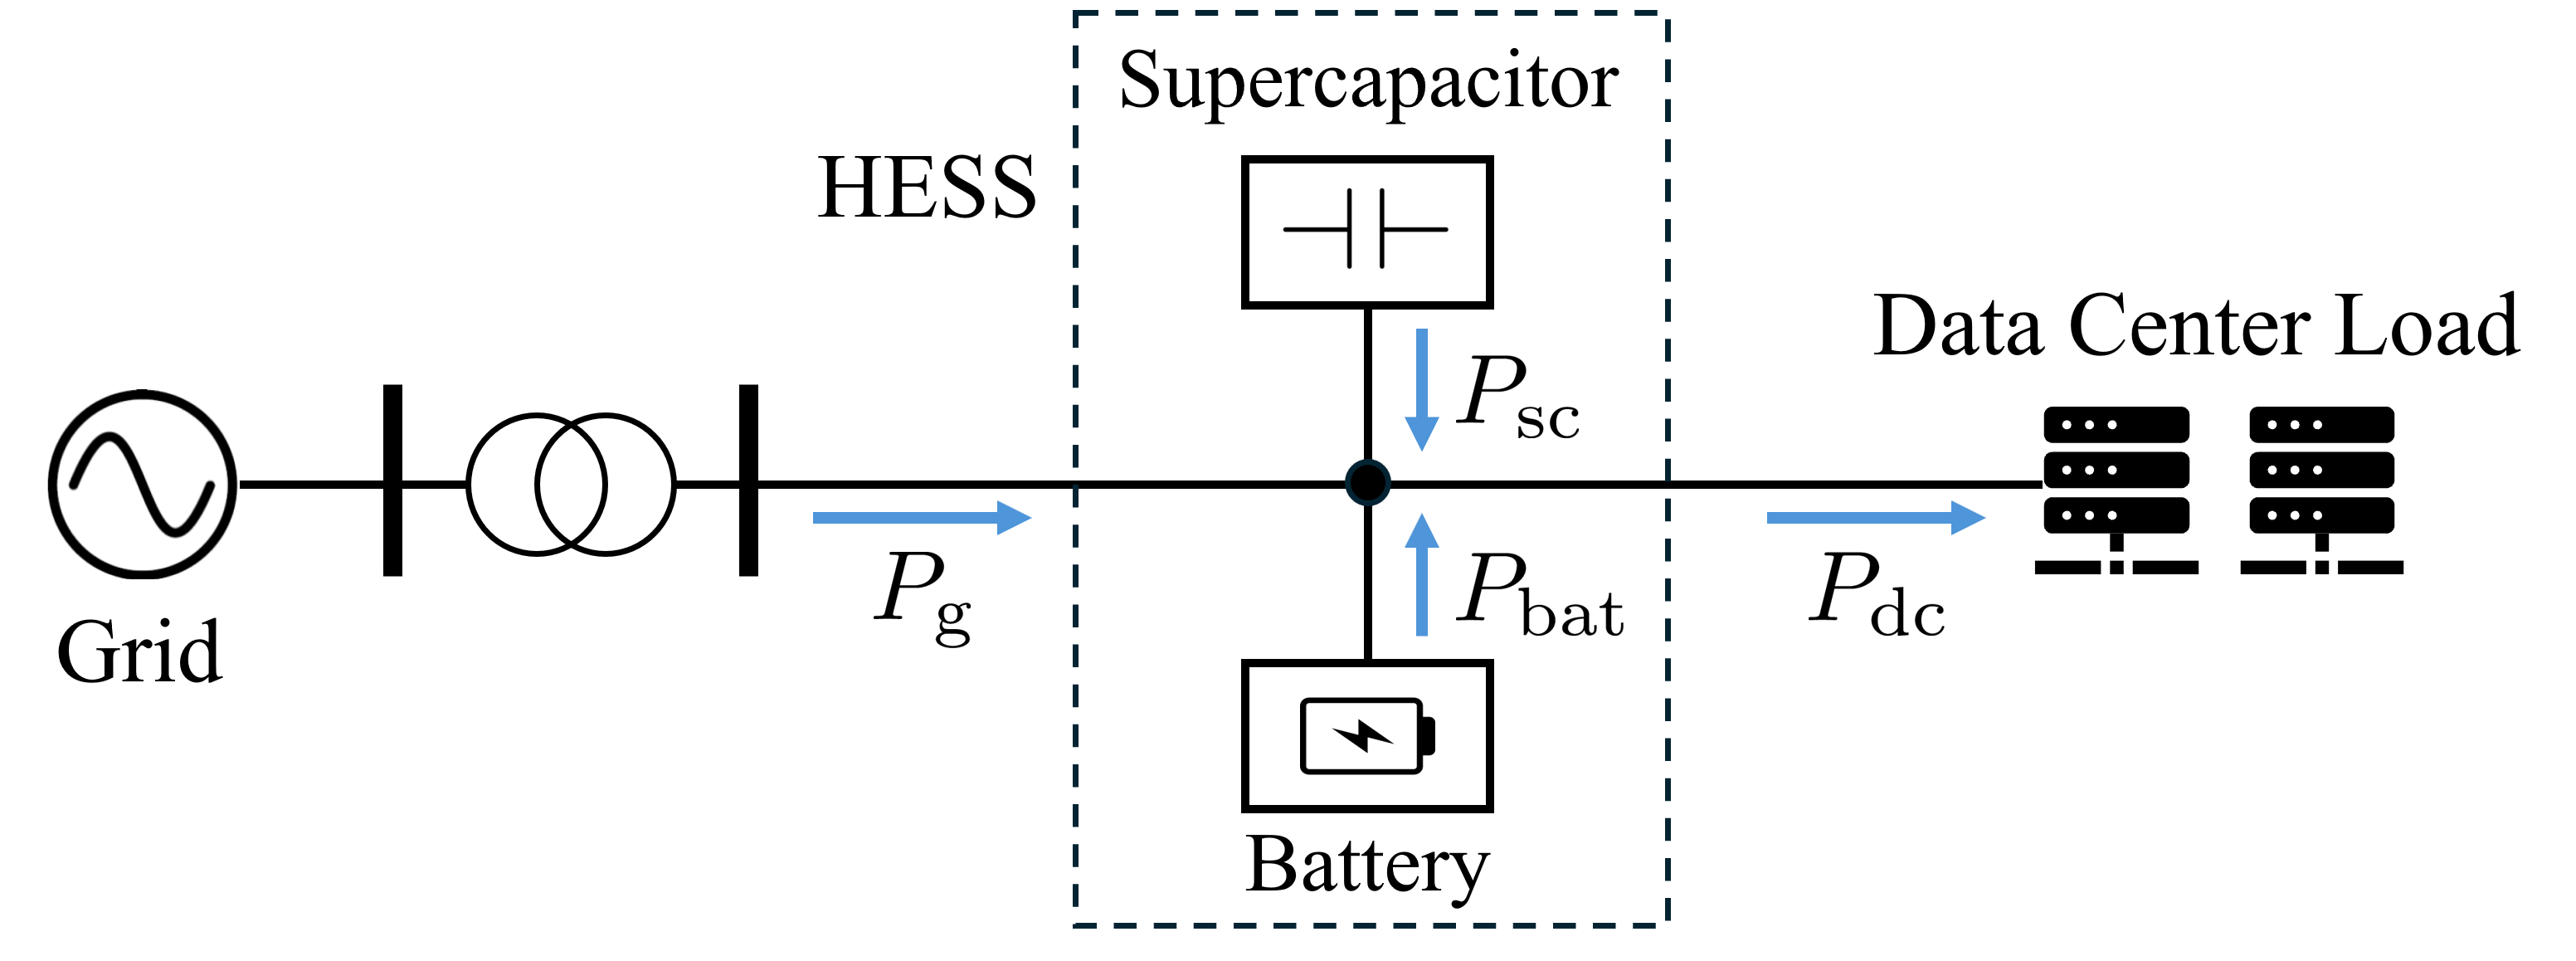
Authors / 作者: Xin Chen
arXiv: 2609.04398 · PDF
To facilitate the grid-friendly integration of highly variable AI data center loads, this paper proposes a grid-mode-aware model predictive control (G-MPC) framework for managing a hybrid energy storage system (HESS) to smooth grid-side power demand. The framework optimally coordinates a battery energy storage system (BESS) and a supercapacitor (SC) by solving a multi-step optimization problem in a receding-horizon manner. In particular, band-pass filter dynamics are directly embedded in the G-MPC formulation to extract and suppress grid-side power components associated with vulnerable grid os
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
5. Continual Field-Adaptive Models (CFAMs) for Post-Deployment Physical AI
Continual Field-Adaptive Models (CFAMs) for Post-Deployment Physical AI
Authors / 作者: Amarjot Singh, Tanmay R. Pancholi, Jainam Kothari, Shrirang Mahajan, Ketan Bansal, Zackory Erickson et al.
arXiv: 2609.04552 · PDF
Unattended interactive autonomy - machines that step into danger in place of humans and complete tasks with human tools - remains a missing capability in mission-critical operations. These domains offer scarce training data and only onboard compute, yet deployed systems must face novelty without erasing prior competence. We introduce Continual Field-Adaptive Models (CFAMs), which learn efficiently in the lab and continue learning after deployment through autonomous, gradient-free, on-device updates. CFAM uses a complementary learning architecture with a frozen slow-learning component and a fas
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。