机器人日报
机器人论文日报 — 2026-07-29
🤖 Scanned 249 new arXiv papers (cs.RO / cs.SY / cs.LG, last 48 h), picked 5 for modular & legged robotics — summarized by DeepSeek.
🤖 扫描了近 48 小时 arXiv(cs.RO / cs.SY / cs.LG)的 249 篇新论文,围绕模块化与足式机器人精选 5 篇 — 由 DeepSeek 生成双语摘要。
1. Amortising Trajectory Optimisation for Residual MPC via Implicit Contact Differentiation
通过隐式接触微分摊销残余MPC的轨迹优化
Authors / 作者: Daniel Layeghi, Thomas Corbères, Calum Arnott, Aditya Kamireddypalli, Hashim Al-Obaidi, Steve Tonneau et al.
arXiv: 2607.24959 · PDF
This paper introduces an AD-assisted implicit derivative for regularised smooth contacts, applied to MuJoCo MJX, based on the Implicit Function Theorem. It avoids solver unrolling and hand-assembled KKT systems, thus memory grows slowly with solver iterations. The method is used for optimiser distillation in residual MPC, significantly improving success rates for contact-rich tasks on Finger, Franka, and Unitree robots.
中文摘要: 本文提出了一种基于隐函数定理的自动微分辅助隐式微分方法,用于正则化光滑接触,并应用于MuJoCo MJX。该方法避免了求解器展开和手动组装KKT系统,因此内存随求解器迭代缓慢增长。该方法用于残余MPC中的优化器蒸馏,在Finger、Franka和Unitree机器人上的接触丰富任务中大幅提高了成功率。
💬 Key contribution to differentiable simulation and MPC for contact-rich control, directly applicable to legged locomotion.
💬 对接触丰富的控制中的可微模拟和MPC做出了关键贡献,直接适用于腿式运动。
Why read it / 推荐理由: Introduces a memory-efficient implicit differentiation technique for contact dynamics, enabling real-time MPC for legged robots. 引入了一种内存高效的接触动力学隐式微分技术,使得腿式机器人能够实现实时MPC。
2. Transformer Transformer: A Unified Model for Motion-Conditioned Robot Co-design
Transformer Transformer:用于运动条件化机器人协同设计的统一模型
Authors / 作者: Huy Ha, C. Karen Liu, Shuran Song
arXiv: 2607.25798 · PDF
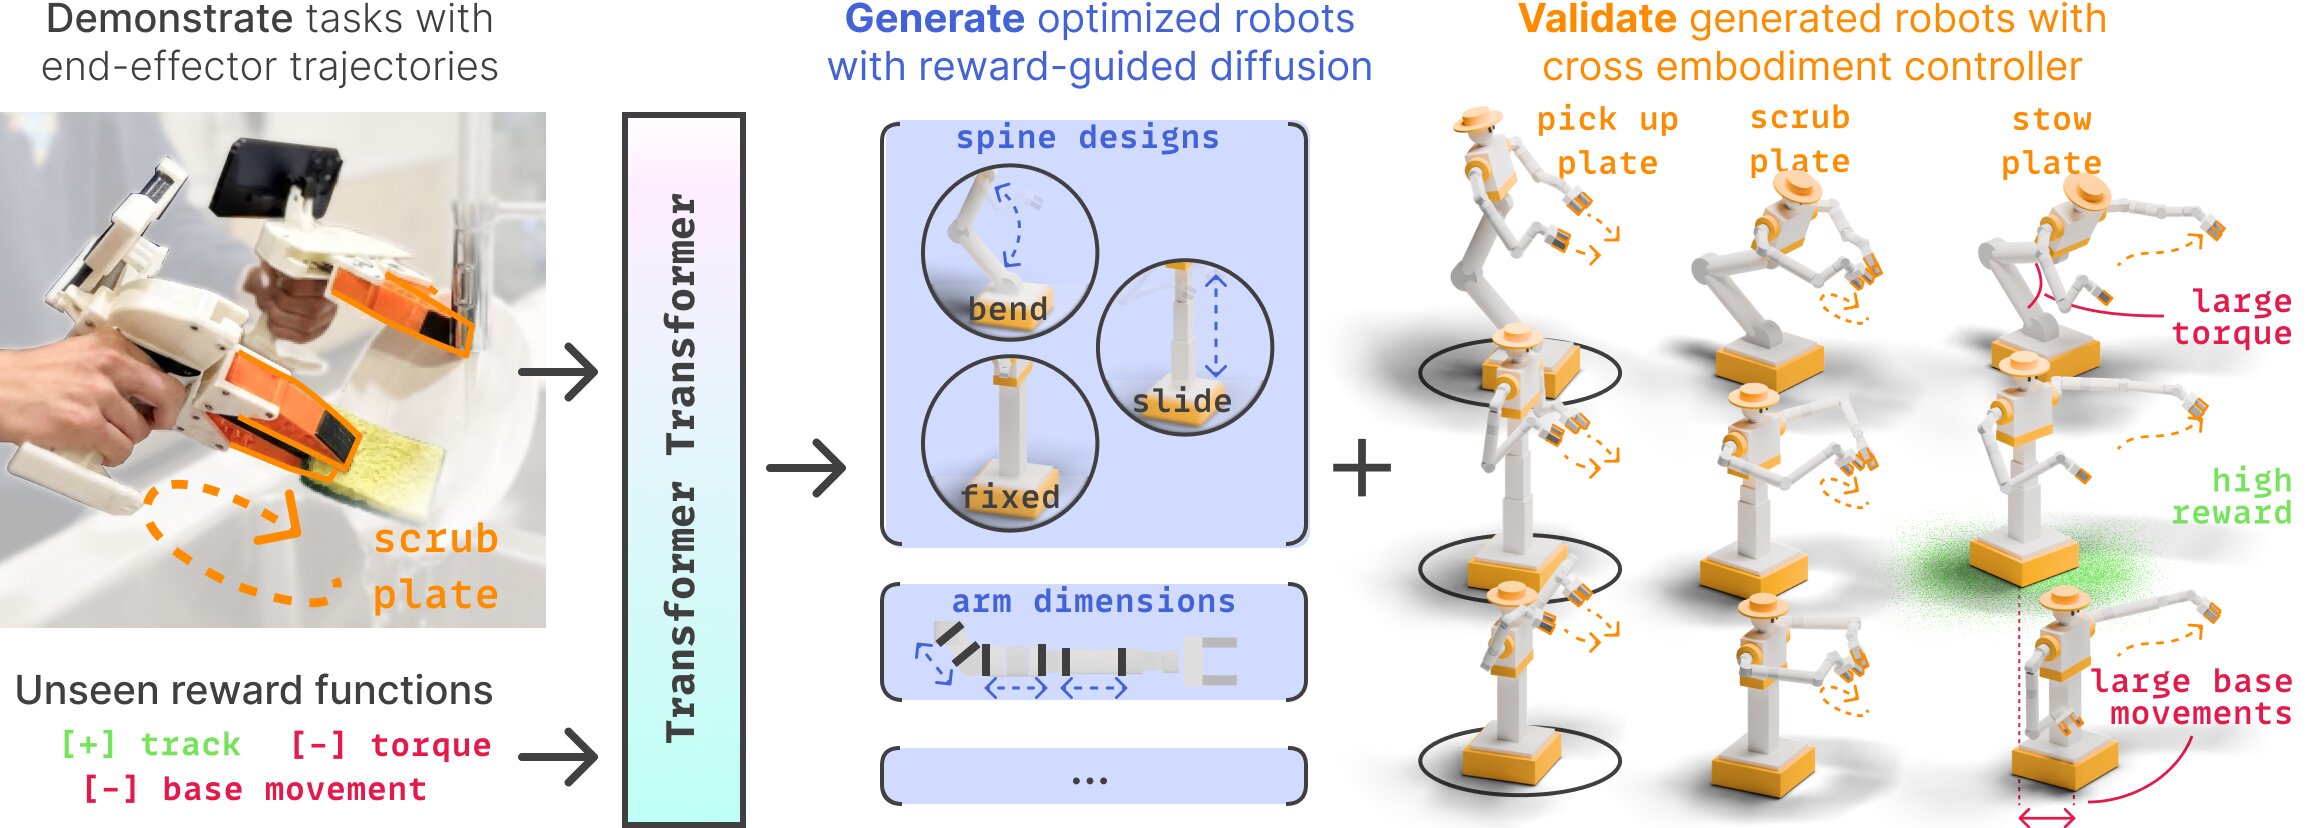
This paper proposes a diffusion transformer trained on tokenized robot embodiments for motion-conditioned robot co-design. The model generates complete robot designs that track target end-effector trajectories while optimizing user-defined rewards. Experiments across wheeled bimanual, quadruped, and humanoid design spaces show zero-shot optimization of unseen rewards, outperforming evolutionary baselines. An optimized ALOHA design reduced tracking error by over 70%.
中文摘要: 本文提出了一个基于扩散Transformer的模型,该模型在标记化的机器人形态上训练,用于运动条件化的机器人协同设计。该模型生成完整的机器人设计,跟踪目标末端执行器轨迹,同时优化用户定义的奖励。在轮式双臂、四足和人形设计空间上的实验显示,对未见过奖励的零样本优化优于进化基线。优化后的ALOHA设计将跟踪误差降低了70%以上。
💬 Relevant for generating modular leg designs that optimize for specific motions, such as gaits.
💬 对于生成针对特定运动(如步态)优化的模块化腿部设计具有相关性。
Why read it / 推荐理由: Enables automated design of modular robots conditioned on desired locomotion trajectories, bridging embodiment and control. 实现了基于期望运动轨迹的模块化机器人自动设计,桥接了形态与控制。
3. When Does Legacy Data Start to Help? Emergent Transfer in Cross-Configuration Robot Learning
遗留数据何时开始起作用?跨配置机器人学习中的涌现迁移
Authors / 作者: Tao Wang, Hudson Hou, Yingdong Hu, Yufeng Liu, Qinghai Li, Yingjie Jiang et al.
arXiv: 2607.25593 · PDF
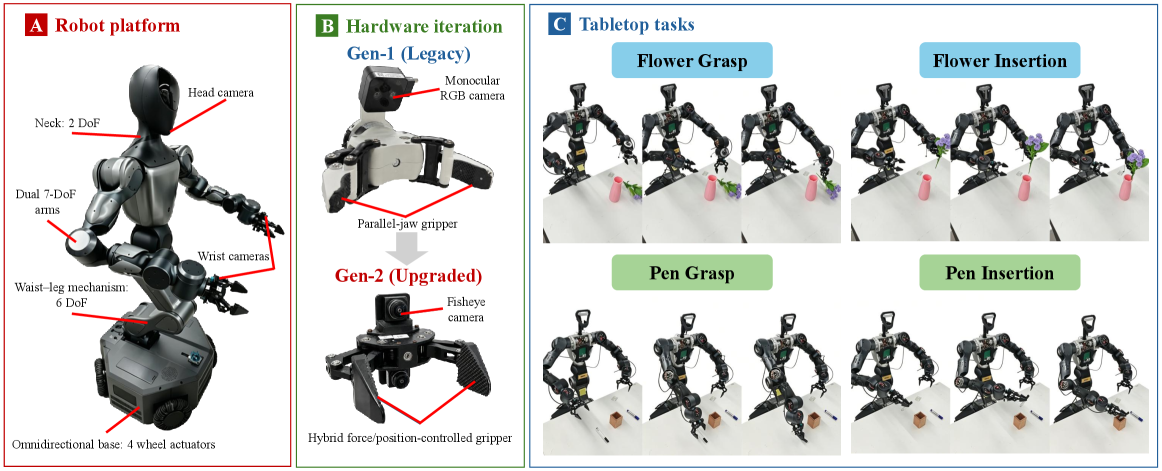
This paper investigates when legacy demonstration data from a previous robot configuration benefits learning on an upgraded configuration. On a wheeled humanoid platform, they observe a grokking-like transition: legacy data remains ineffective until the new hardware achieves a minimum competence level, then sharp gains occur. The study provides a phase-aware rule for deciding when to collect new data versus reuse legacy data, with real-robot experiments showing significant improvements in success rates.
中文摘要: 本文研究了先前机器人配置的遗留演示数据何时对升级后的配置学习有益。在一个轮式人形平台上,他们观察到了一个类似顿悟的转变:直到新硬件达到最低能力水平之前,遗留数据一直无效,之后会急剧提升。该研究提供了一个相位感知规则,用于决定何时收集新数据与重用遗留数据,真实机器人实验显示了成功率的显著提高。
💬 Directly relevant for modular robots where hardware configurations change; guides efficient use of cross-configuration data.
💬 与硬件配置变化的模块化机器人直接相关;指导跨配置数据的高效使用。
Why read it / 推荐理由: Addresses a practical problem in modular robotics: how to leverage data from previous leg module designs to accelerate learning on new ones. 解决了模块化机器人的一个实际问题:如何利用先前腿部模块设计的数据来加速新模块的学习。
4. Temporal-Distance JEPA: Plan-Aware Representation Learning for Latent World Model Predictive Control
时间距离JEPA:用于潜在世界模型预测控制的计划感知表示学习
Authors / 作者: Jiaxin Bai, Jiaxuan Xiong
arXiv: 2607.25337 · PDF
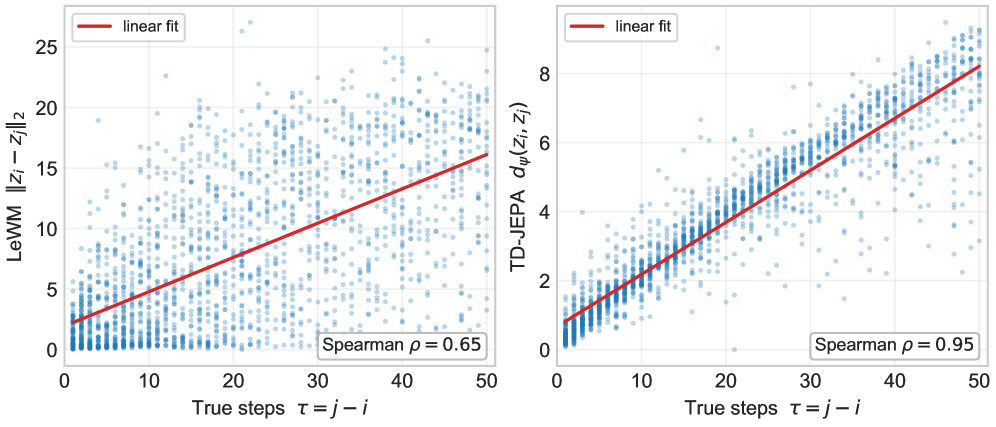
This paper proposes temporal-distance JEPA (TD-JEPA), which mines a directed temporal cost from reward-free demonstration trajectories for planning in latent world models. The mined cost serves both as a planning metric and as a representation signal that improves Euclidean planning. Experiments show significant improvements in success rates on several tasks, including OGB-Cube and Push-T.
中文摘要: 本文提出了时间距离JEPA(TD-JEPA),它从无奖励的示范轨迹中挖掘有向时间成本,用于潜在世界模型中的规划。挖掘的成本既作为规划度量,也作为改进欧几里得规划的表示信号。实验显示在多个任务上成功率显著提高,包括OGB-Cube和Push-T。
💬 Relevant for learning world models for MPC in legged locomotion, especially in long-horizon tasks.
💬 对于腿式运动中的MPC学习世界模型相关,特别是长时任务。
Why read it / 推荐理由: Proposes a novel approach to learn planning costs from demonstrations, which can enhance MPC performance for complex gaits. 提出了一种从示范中学习规划成本的新方法,可以增强复杂步态的MPC性能。
5. Decompose and Reorganize: Planning with Primitives and Visuomotor Policies Learned from Demonstrations
分解与重组:利用从示范中学习的基元和视觉运动策略进行规划
Authors / 作者: Yizhou Chen, Hang Xu, Dongjie Yu, Yupu Lu, Tengye Xu, Zeqing Zhang et al.
arXiv: 2607.25397 · PDF
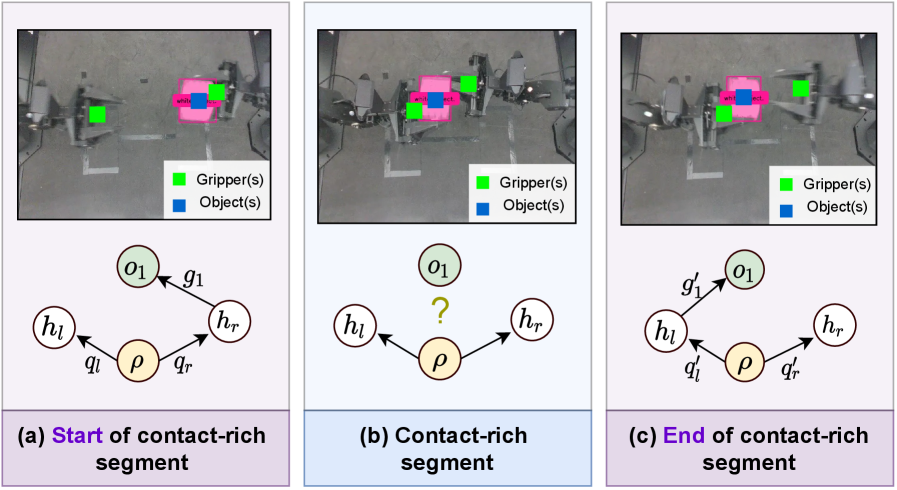
This paper presents DR-LfD, a framework that integrates visuomotor policies into TAMP-gated decision making. It decomposes human demonstrations into atomic skills (visuomotor policies or object-centric primitives) with modeled initiation, termination, and constraints. Skills from different sources can be reorganized via TAMP for long-horizon manipulation. The approach scales linearly with the number of skill types, enabling generalization across tasks.
中文摘要: 本文提出了DR-LfD框架,将视觉运动策略集成到TAMP门控的决策中。它将人类示范分解为原子技能(视觉运动策略或物体中心基元),并建模启动、终止和约束。不同来源的技能可以通过TAMP重新组织,用于长时操作。该方法随技能类型数量线性扩展,实现了跨任务的泛化。
💬 Relevant for whole-body control of modular legged robots, combining task planning with learned motion primitives for complex locomotion.
💬 对于模块化腿式机器人的全身控制具有相关性,结合任务规划与学习到的运动基元进行复杂运动。
Why read it / 推荐理由: Shows how to compose learned skills hierarchically, which can be applied to gait generation and reconfiguration in modular robots. 展示了如何分层组合学习到的技能,可应用于模块化机器人的步态生成和重新配置。