Robotics Digest
Robotics Paper Digest — 2026-09-23
🤖 Scanned 352 papers from today’s arXiv announcement (cs.RO / eess.SY / cs.LG), picked 5 for modular & legged robotics — summarized by DeepSeek.
🤖 从今日 arXiv 新论文(cs.RO / eess.SY / cs.LG)中扫描 352 篇,围绕模块化与足式机器人精选 5 篇 — 由 DeepSeek 生成双语摘要。
1. SG-CPG: Severity-Gated Central Pattern Generators for Adaptive Quadruped Locomotion under Continuous Actuator Degradation
SG-CPG:用于连续执行器退化下自适应四足运动的严重度门控中枢模式发生器
Authors / 作者: Adarsh Kumar Kosta, Kaushik Roy
arXiv: 2609.25687 · PDF
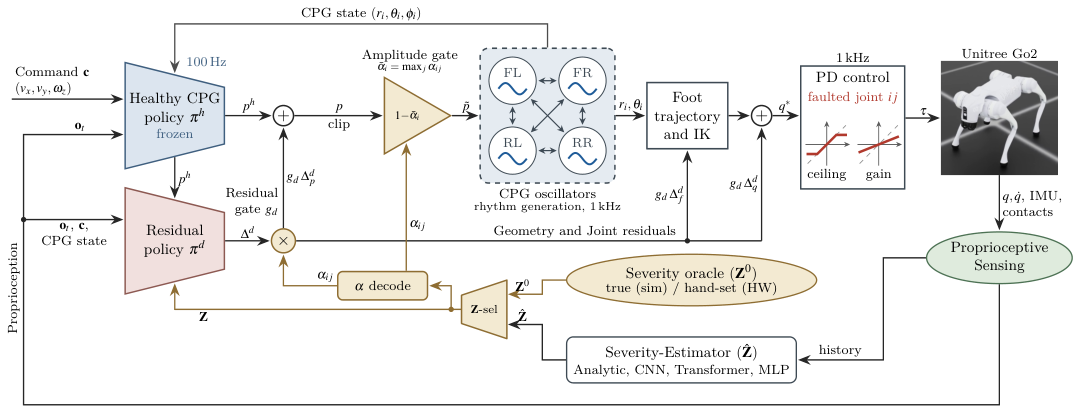
SG-CPG augments a frozen healthy central pattern generator policy with two severity-driven gates: a residual gate that re-coordinates all four legs and an amplitude gate that shortens the weakened leg’s stride. Simulations on a Unitree Go2 show 100% survival and command tracking within 8% under up to 95% joint strength loss, and real-robot experiments confirm survival; ablating either gate raises torque clipping at the weakened joint from 4.4% to 13.6-26.3% of steps at 80% loss.
中文摘要: 该工作受生物在肢体力量减弱时并非直接切换步态、而是卸载受损肢体并重新协调其余肢体的启发,提出 SG-CPG,用于连续执行器退化条件下的四足运动控制。方法保留一个冻结的健康中枢模式发生器(CPG)策略,并引入两个由退化严重度驱动的门:残差门重新协调四条腿的运动,幅度门随退化程度逐步缩短受损腿的步幅。作者通过降低关节力矩上限和缩放底层控制器增益两种机制模拟渐进退化。在 Unitree Go2 仿真中,即使关节力量损失达 95%,SG-CPG 仍能以 100% 存活率维持 trot 步态并保持命令跟踪误差在 8% 以内;真实 Go2 上也验证了存活能力。消融实验表明,在 80% 退化下移除任一严重度路径会使受损关节的力矩饱和比例从 4.4% 升至 13.6% 与 26.3%。该工作对模块化/多足平台容错控制具有直接参考价值。
💬 A rare example of graceful, severity-graded gait adaptation to actuator degradation that is validated on real hardware, directly relevant to fault-tolerant modular legged locomotion.
💬 这是少见的、按退化严重度平滑调节步态并完成真机验证的工作,对模块化足式机器人的容错运动控制很有参考价值。
Why read it / 推荐理由: It shows how to keep a quadruped trotting under continuous actuator weakening without discrete mode switching, with concrete ablations and a real Unitree Go2 demonstration. 它展示了如何在执行器持续退化下不依赖离散模式切换仍保持四足 trot 运动,并给出了明确的消融实验和 Unitree Go2 真机验证。
2. Learning Air-Ground Motion Control with Temporal Mode Switching and Cross-Terrain Tracking
基于时序模式切换与跨地形跟踪的空中-地面运动控制学习
Authors / 作者: Ruitian Pang, Mingrui Li, Xuanting Liu, Tiancheng Lai, Juncheng Chen, Xiangyu Li et al.
arXiv: 2609.26564 · PDF
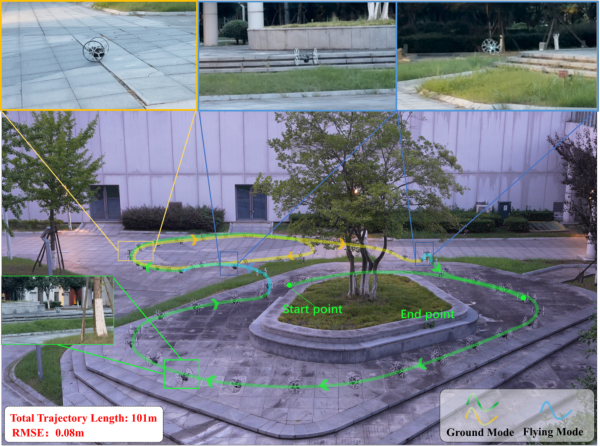
This paper proposes a learning-based air-ground motion control framework for passive-wheeled terrestrial-aerial bimodal vehicles, combining a learned mode selector that uses historical single-point ToF measurements and robot states with future references, and a reinforcement learning trajectory-tracking policy using proprioception plus future references. Multi-terrain training and dynamics randomization yield robust ground tracking across terrains, with the learned selector outperforming a rule-based one and the controller achieving lower position RMSE than PID and remaining effective where NMPC fails, in both simulation and real-world experiments.
中文摘要: 本文针对被动轮式地面-空中双模态车辆(TABV),提出一种基于学习的空中-地面运动控制框架,解决有限机载感知下的可靠模态切换与跨地形地面轨迹跟踪问题。框架包含两部分:一是学习式模态选择器,利用历史单点飞行时间(ToF)测量与机器人状态,并结合未来参考信息决定当前运动模式;二是强化学习轨迹跟踪策略,将本体感知与未来参考结合以预判轨迹变化。通过多地形训练和动力学随机化,地面控制器在不同地形上实现鲁棒跟踪。仿真与真机实验表明,学习式选择器在困难切换场景下优于规则选择器,地面控制器在所有测试条件下位置 RMSE 均低于 PID,并在 NMPC 失效的场景下仍保持较好的跟踪性能。该工作为足式/轮足平台在复杂地形中的运动控制与切换提供了可迁移的思路。
💬 The temporal mode selector plus cross-terrain RL tracking is a clean formulation that generalizes to hybrid legged-wheeled platforms and offers a useful comparison against NMPC.
💬 时序模态选择器与跨地形强化学习跟踪的组合思路清晰,可推广到轮足混合平台,并给出了与 NMPC 的对照结论。
Why read it / 推荐理由: It provides a concrete recipe for learned mode switching and terrain-robust tracking, including a comparison where the learned controller beats PID and survives cases where NMPC fails. 它给出了学习式模态切换与地形鲁棒跟踪的具体方案,并证明其在地面跟踪上优于 PID、且在 NMPC 失效时仍可用。
3. HOTICE: Whole-Body Humanoid Object Transportation in Cluttered Environments
HOTICE:杂乱环境中的人形机器人全身物体运输
Authors / 作者: Toan Nguyen, Weiduo Yuan, Siheng Zhao, Yue Wang, Daniel Seita
arXiv: 2609.25363 · PDF
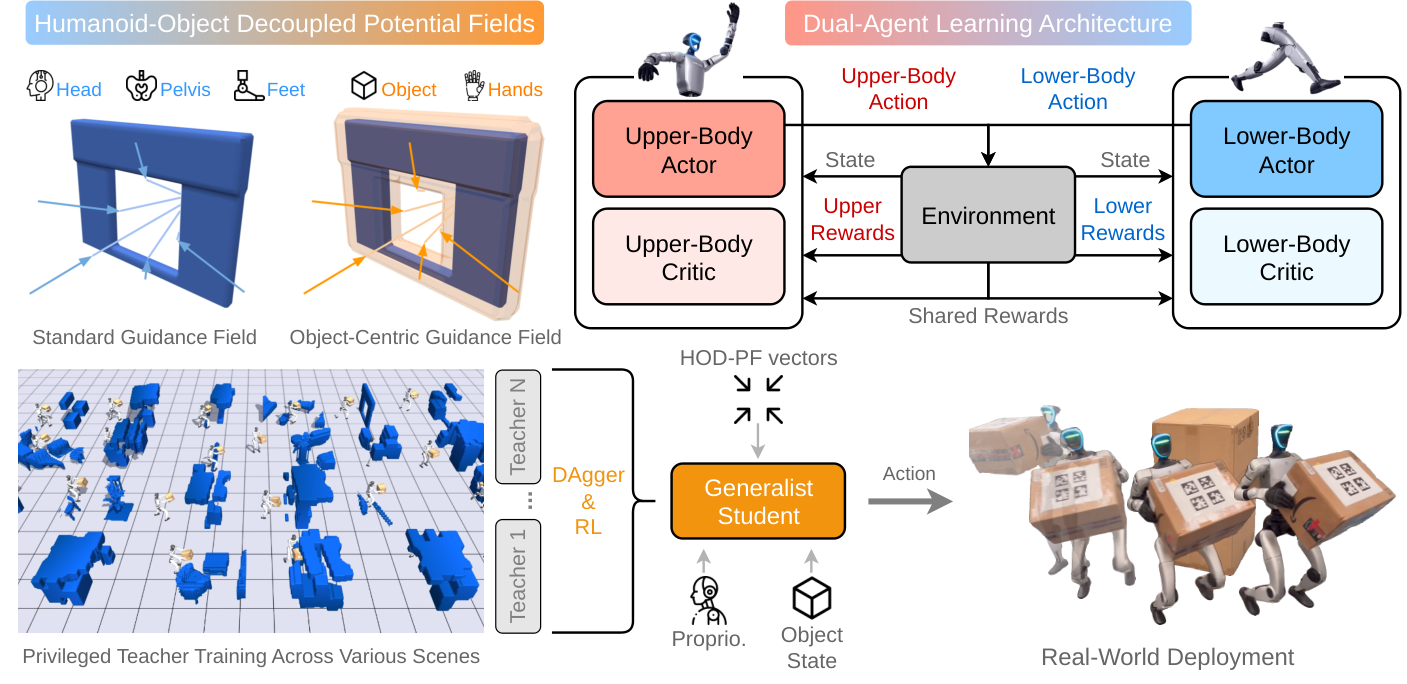
HOTICE tackles whole-body humanoid object transportation in cluttered spaces with Humanoid-Object Decoupled Potential Fields that jointly encode obstacle avoidance for the robot and payload, a dual-agent RL architecture decoupling upper- and lower-body control while sharing state and rewards, and specialist-to-generalist distillation from privileged teachers into a deployable student. Evaluated in MuJoCo and on a real Unitree G1, it transports objects of varying shapes robustly and generalizes to unseen cluttered scenes.
中文摘要: 本文提出 HOTICE,一个在杂乱环境中进行全身人形机器人物体运输的学习框架。方法包含三部分:一是“人形-物体解耦势场”,同时为机器人本体和所搬运物体编码避障引导,使二者协调地绕开障碍;二是双智能体强化学习架构,将上身与下身控制解耦,但通过共享状态观测和奖励保持全身协调;三是专家到通才的蒸馏策略,将带特权信息的教师策略蒸馏为单一可部署学生策略,从而泛化到多样杂乱场景。作者在 MuJoCo 仿真和真实 Unitree G1 人形机器人上评估,结果表明该方法能在不同形状物体的杂乱场景中实现稳健运输,并对未见场景有良好泛化,同时可靠地协调全身运动与物体感知避障。
💬 Decoupled whole-body control with object-aware potential fields is a strong template for modular legged platforms that must coordinate body and payload in clutter.
💬 解耦式全身控制结合物体感知势场,为需要在杂乱环境中协调本体与负载的模块化足式平台提供了很好的范式。
Why read it / 推荐理由: It offers a practical whole-body learning pipeline with real humanoid deployment and explicit handling of the carried payload’s collision avoidance. 它给出了一套可落地的全身学习流程,在人形真机上完成部署,并显式处理了所搬运物体的避障问题。
4. REDACT: Robust Perceptive Locomotion under Unseen Visual Corruption
REDACT:未见视觉损坏条件下的鲁棒感知运动
Authors / 作者: Natapat Kirdwichai, Tobias Driskell-Poole, Andrei Sontea, Jadu Dash, Muhammad Burhan Hafez, Danesh Tarapore
arXiv: 2609.25450 · PDF
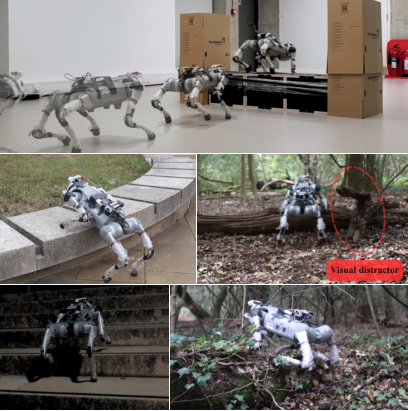
REDACT is a teacher-student framework for depth-conditioned legged locomotion that combines an improved visual encoder, persistent feature masking, and a consensus-gating algorithm using approximate conformal calibration on clean observations to retain useful depth under unmodeled corruption. Trained only on clean simulated depth, it sustains higher traversal success than parkour baselines under unseen corruptions, and transfers zero-shot to structured and forested real-world environments with unfamiliar scene content.
中文摘要: 本文提出 REDACT(Retaining Evidence Despite Artifacts for Continued Traversal),解决深度条件化足式运动策略在训练分布之外的视觉损坏下行为不可预测的问题。框架采用师生结构,结合改进的视觉编码器架构、持续特征掩码以及一种新的共识门控算法:该门控仅利用干净观测进行近似保形校准,无需事先知道损坏类型,即可在未建模损坏下保留有用的深度信息。训练仅在干净仿真深度上进行,REDACT 在未见损坏条件下仍能保留有效视觉信息,穿越成功率高于现有跑酷基线;对多种损坏族的深度增强评估也显示,在增强覆盖不足处 REDACT 仍能提升鲁棒性。真机试验实现了对结构化环境与林地的零样本迁移。
💬 Distribution-free conformal gating for depth corruption is a novel robustness mechanism that maps well onto sim-to-real deployment of perceptive legged controllers.
💬 面向深度损坏的无分布保形门控是一种新颖的鲁棒性机制,可直接用于感知型足式控制器的仿真到现实部署。
Why read it / 推荐理由: It addresses the practical failure mode of unseen depth corruption with a calibration-based gate and demonstrates zero-shot transfer to real forested terrain. 它用基于校准的门控解决了未见深度损坏这一实际失效模式,并展示了向真实林地环境的零样本迁移。
5. Predict Before You Step: Auditable Occupancy Forecasting for Dynamic Obstacle Avoidance under Sparse Guidance
先预测再迈步:稀疏引导下动态避障的可审计占据栅格预测
Authors / 作者: Yuhui Mao, Fen Liu, Shenghai Yuan, Tianxin Hu, Ruimeng Liu, Rong Su
arXiv: 2609.25969 · PDF
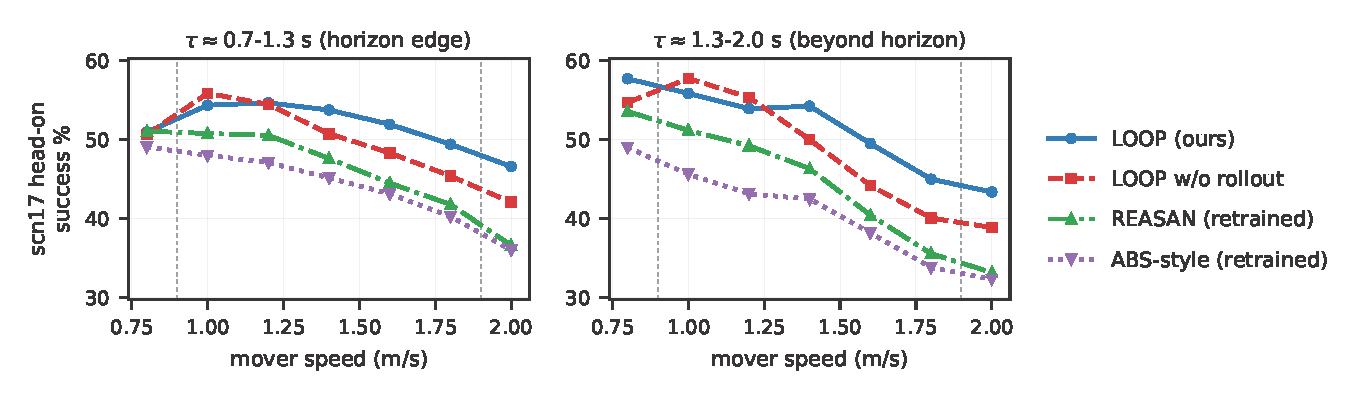
LOOP is a local avoidance policy that connects sparse waypoint guidance to a frozen locomotion controller at 50 Hz, using a recurrent predictor over occupancy and ego-velocity histories to forecast future occupancy 1 s ahead by warping the current map with learned flow and visibility gates. These forecasts drive velocity selection via map-derived features and geometric risk, providing an inspectable interface; it reaches 57.1% head-on success at 2.5-3.2 m/s in Isaac Lab, runs onboard a Unitree Go2 in 14.5 ms, and completes all 16 real-world crossing trials without collision.
中文摘要: 本文提出 LOOP(Latent-recurrent Occupancy rollOut Policy),用于稀疏路点引导下足式机器人在动态障碍环境中的局部避障。该策略以 50 Hz 连接稀疏路点引导与一个冻结的运动控制器:从占据栅格与自车速度历史出发,递归预测器通过用学习到的流场和可见性门对当前地图进行形变,预测未来 1 秒的占据情况。这些预测图通过地图导出特征和几何风险评估来指导速度选择,并为检查或替换预测模块提供了显式接口。在 Isaac Lab 的对遇场景评估中,障碍速度 2.5-3.2 m/s 时正面遭遇成功率为 57.1%,比重新训练的纯反应式基线高 8.2 个百分点;与无推演的 BEV 策略相比,预测分支在穿越成功率和降低种子间波动方面有场景相关收益。控制器在 Unitree Go2 上以每步 14.5 ms 运行,16 次真实穿越试验全部无碰撞完成。
💬 A prediction-based local planner with an explicit, auditable occupancy interface is a valuable complement to traverse-capability-aware path planning on legged robots.
💬 具备显式可审计占据栅格接口的预测式局部规划器,是对足式机器人可通行性感知路径规划的有益补充。
Why read it / 推荐理由: It bridges learned occupancy forecasting with a frozen locomotion controller and backs the design with onboard timing and real-world collision-free trials. 它把学习式占据预测与冻结的运动控制器结合起来,并给出了机载运行时间和真机无碰撞试验验证。