Robotics Digest
Robotics Paper Digest — 2026-09-11
🤖 Scanned 314 new arXiv papers (cs.RO / eess.SY / cs.LG, last 48 h), picked 5 for modular & legged robotics — summarized by DeepSeek.
🤖 扫描了近 48 小时 arXiv(cs.RO / eess.SY / cs.LG)的 314 篇新论文,围绕模块化与足式机器人精选 5 篇 — 由 DeepSeek 生成双语摘要。
1. Morphology-Aware Human Motion Retargeting for Wheeled-Humanoid Loco-Manipulation
Morphology-Aware Human Motion Retargeting for Wheeled-Humanoid Loco-Manipulation
Authors / 作者: Chenbo Xia, Chao Ye
arXiv: 2609.11357 · PDF
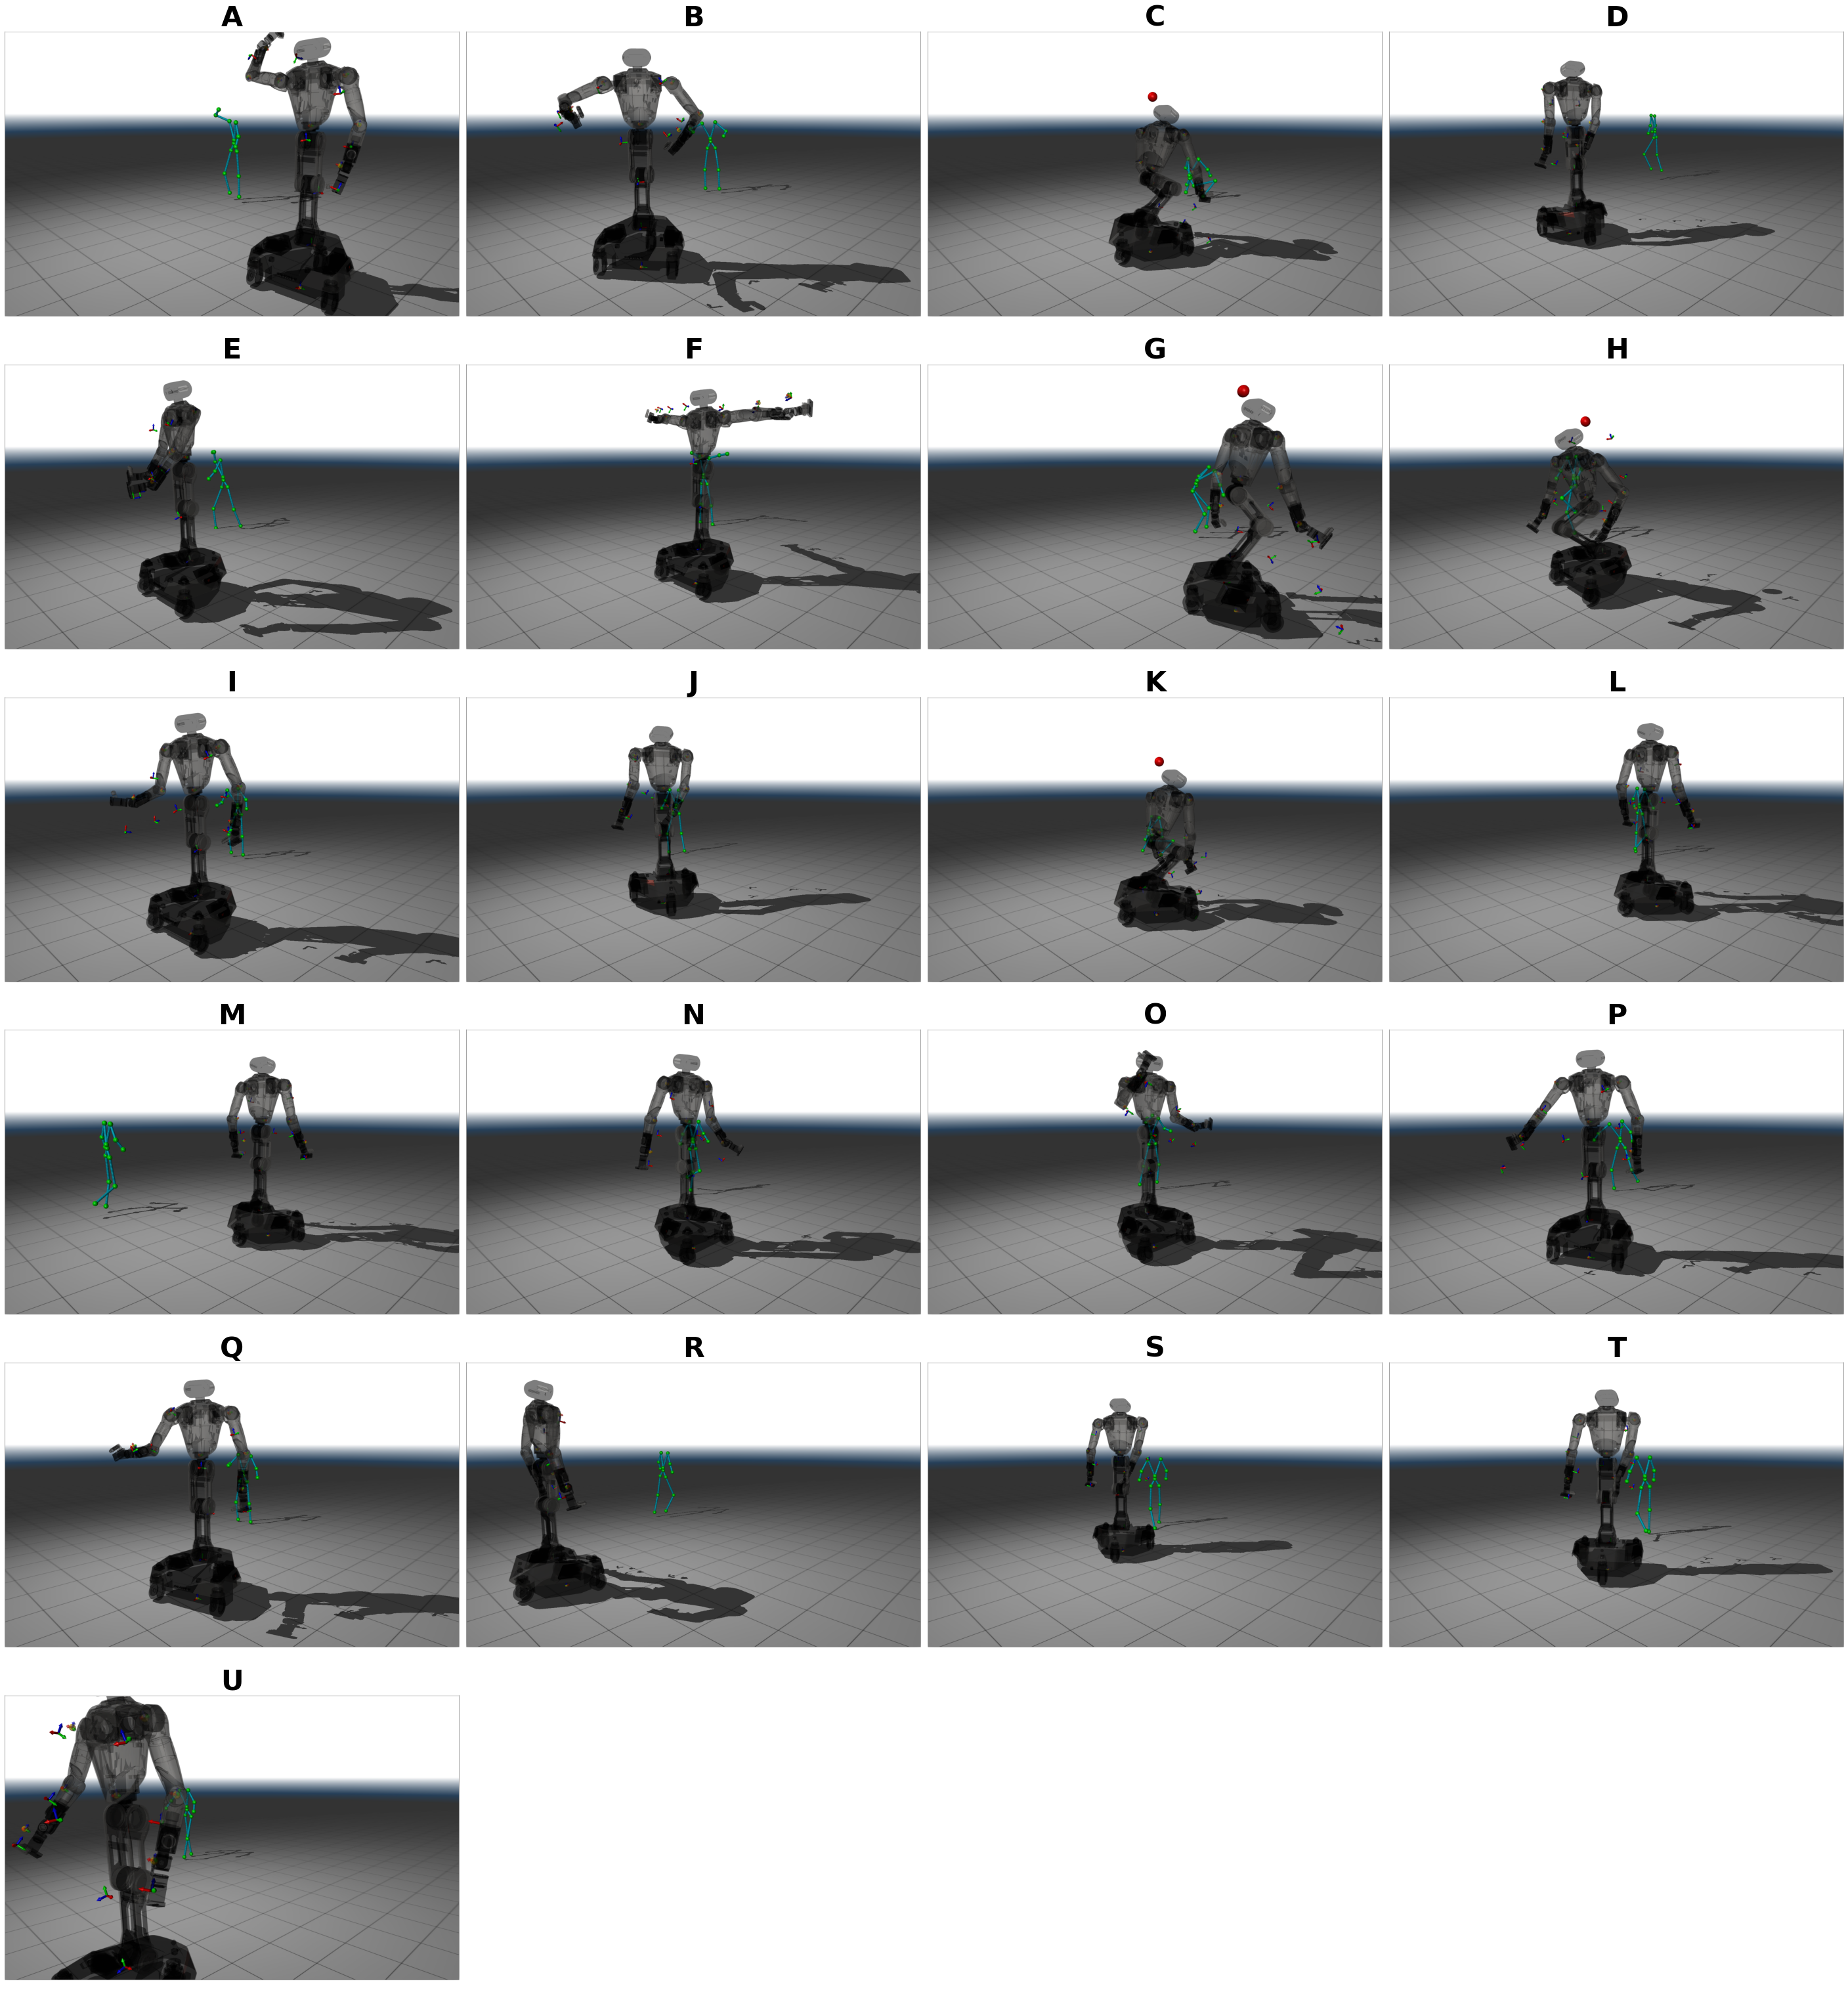
Human-to-humanoid retargeting has largely been studied on legged platforms, while comparatively few wheeled-humanoid systems support coupled locomotion and manipulation from general human motion. Building on GMR’s configurable general-motion retargeting and BeyondMimic’s physically simulated R1 Pro learning framework, we present a reproducible pipeline that converts multi-dataset SMPLX motion into executable loco-manipulation behavior for the Galaxea R1 Pro wheeled humanoid. The robot has a planar three-wheel base, a serial torso, and two arms but no leg joints, so human lower-body motion must
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
2. Gait-Dependent Effects on Quadruped Locomotion for Load-Carrying using Passive Mechanism
Gait-Dependent Effects on Quadruped Locomotion for Load-Carrying using Passive Mechanism
Authors / 作者: Giovanni B. Dessy, Claudio Semini, Victor Barasuol
arXiv: 2609.11059 · PDF
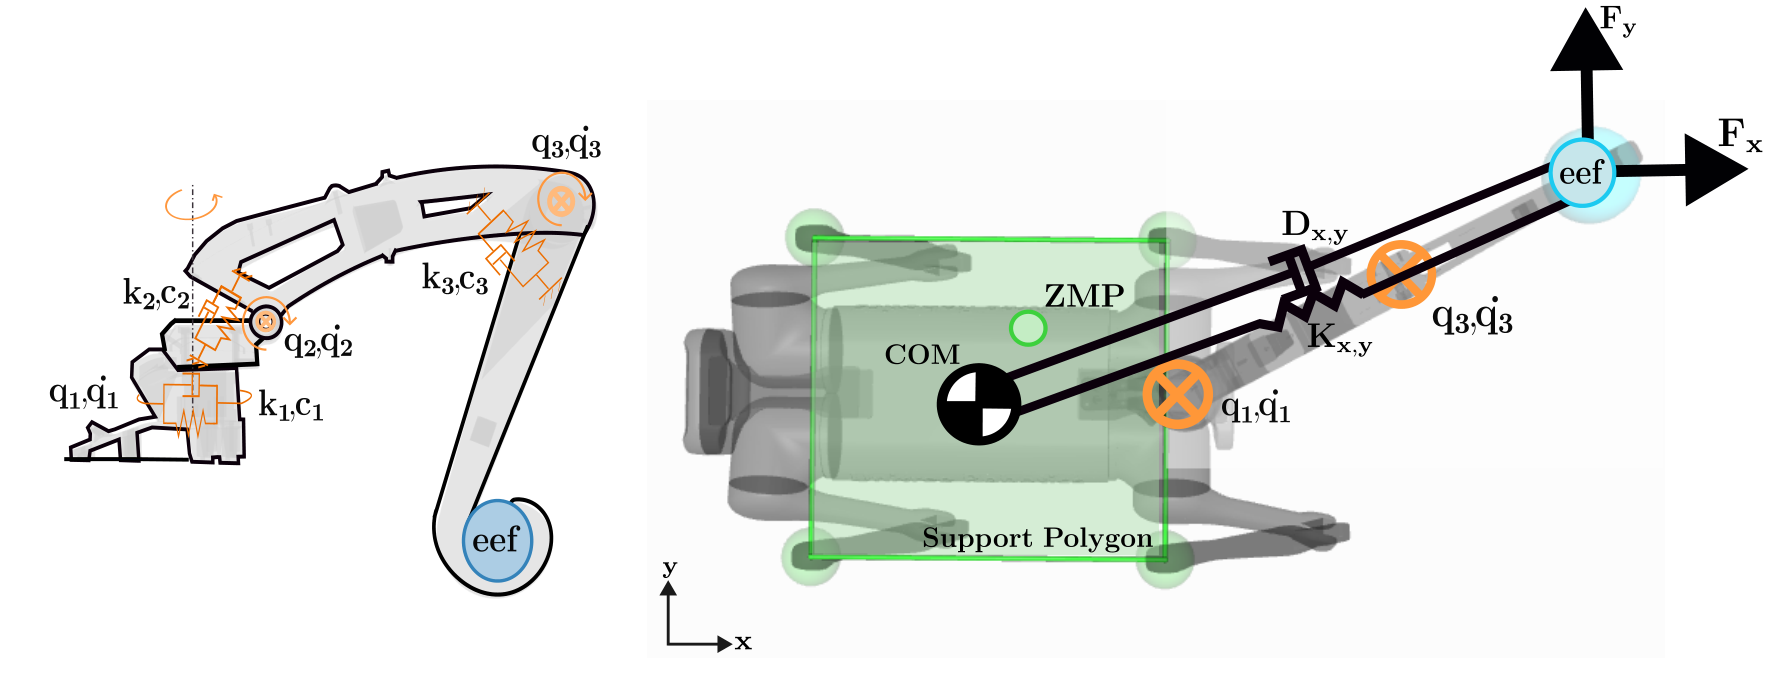
Passive mechanical interfaces offer a lightweight alternative to actuated manipulators for quadruped payload carrying, but their impedance directly couples the payload dynamics with the locomotion pattern. This paper analyzes how passive-arm stiffness-damping selection affects payload-carrying locomotion under different gait and payload conditions. We compare damped and underdamped passive-arm impedance configurations in simulation during flat-ground locomotion. For crawl gaits, where the support polygon remains well defined, the results show that underdamped impedance increases passive-joint
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
3. CAP: Continuously Adaptive Perception-Blind Humanoid Locomotion via Learned Denoising
CAP: Continuously Adaptive Perception-Blind Humanoid Locomotion via Learned Denoising
Authors / 作者: Hongjin Chen, Zijun Xu, Shihao Ma, Yi Zhao, Xilai Liu, Ke Ma et al.
arXiv: 2609.11553 · PDF
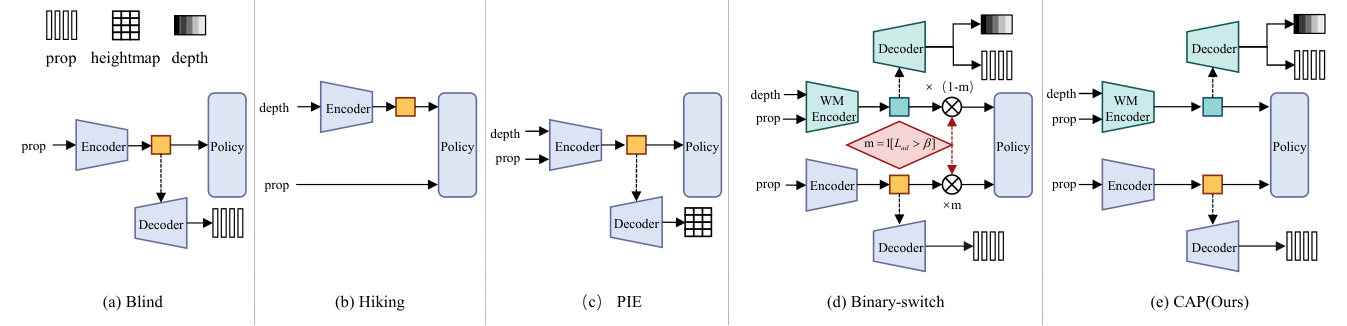
Humanoid locomotion across complex terrain demands forward-looking exteroception to anticipate obstacles, yet this signal is unreliable in real-world deployment, failing partially and intermittently. Existing perceptive policies often assume that depth observations remain clean and in-distribution, while recent attempts to unify perceptive and blind control typically route or switch between separate sub-policies, leaving recoverable information in partially corrupted depth unexploited. We instead propose CAP, a single-stage humanoid locomotion policy that recovers this signal with a perceptive
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
4. GeoTrussRover: Morphological Computation with Contact-Semantic Control Primitives
GeoTrussRover: Morphological Computation with Contact-Semantic Control Primitives
Authors / 作者: Muyuan Ma, Yi Zhang, Yang Yang, Xuanyan Zheng, Ruiqi Hu, Boxuan Ke et al.
arXiv: 2609.11361 · PDF
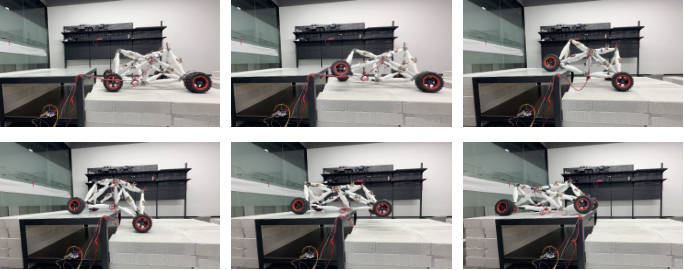
Reconfigurable robots can change their contact geometry when a fixed body cannot negotiate an obstacle. A variable-geometry truss (VGT) distributes this shape change through a load-bearing structure, but coupling it to a mobile base creates a high-dimensional coordination problem. GeoTrussRover combines an electrically actuated VGT, a wheeled base, and contact-semantic morphology planning and control. We solve one source traversal and extract four contact-semantic primitives that describe coordination among 21 members. Physics-constrained projection adapts them to unseen step heights with the
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
5. Reflex-Informed Neuromuscular Reinforcement Learning for Muscle-Driven Locomotion
Reflex-Informed Neuromuscular Reinforcement Learning for Muscle-Driven Locomotion
Authors / 作者: Jian Zhou, Xingyu Zhang, Rui Ma, Yu Cao, Shane Xie, Zhi-qiang Zhang
arXiv: 2609.11733 · PDF
Muscle-driven locomotion provides a physically grounded approach to generating realistic human movement. However, achieving both physiological plausibility and adaptability to changes in musculoskeletal capacity and external disturbances remains a fundamental challenge. To address this limitation, we propose a Reflex-Informed Neuromuscular Reinforcement Learning framework for muscle-driven locomotion. Within this framework, a fixed phase-dependent reflex controller serves as the underlying neuromuscular control mechanism, while the reinforcement learning policy produces four biomechanically me
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。