Robotics Digest
Robotics Paper Digest — 2026-09-05
🤖 Scanned 96 new arXiv papers (cs.RO / eess.SY / cs.LG, last 48 h), picked 5 for modular & legged robotics — summarized by DeepSeek.
🤖 扫描了近 48 小时 arXiv(cs.RO / eess.SY / cs.LG)的 96 篇新论文,围绕模块化与足式机器人精选 5 篇 — 由 DeepSeek 生成双语摘要。
1. RoughSense: Lightweight Terrain-Induced Rover Vibration Prediction Using Point Clouds and IMU Feedback
RoughSense: Lightweight Terrain-Induced Rover Vibration Prediction Using Point Clouds and IMU Feedback
Authors / 作者: Gabriel Manuel Garcia, Stephanie Aravecchia, Miguel Angel Olivares-Mendez
arXiv: 2609.03720 · PDF
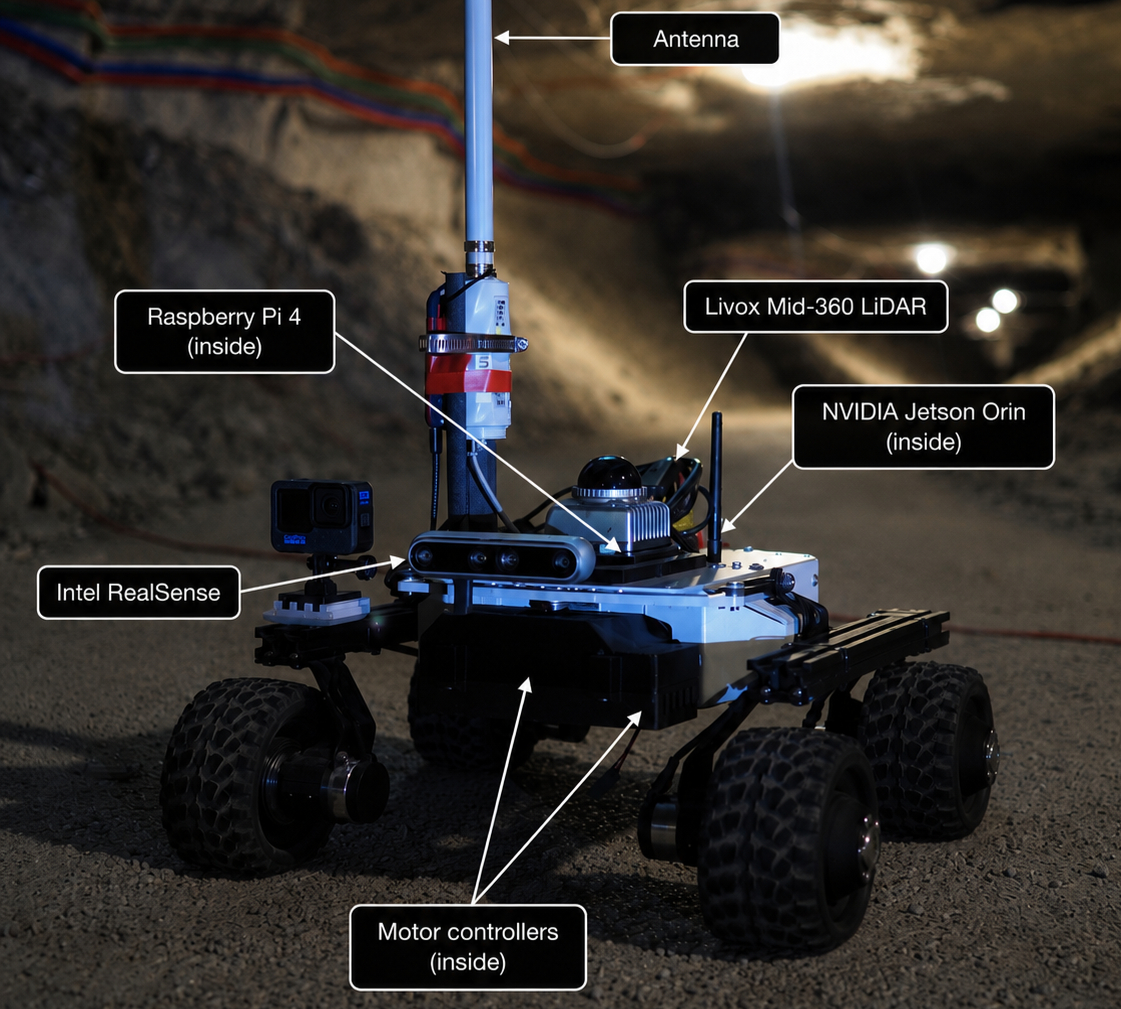
Autonomous navigation in space requires reliable terrain assessment for safe operations, especially in underground environments with limited communication, computing resources, and power budget. This paper presents a lightweight method for real-time vibration-aware traversability mapping using a Light Detecting And Ranging (LiDAR) point cloud and Inertial Measurement Unit (IMU) measurements. An initial vibration proxy is estimated from terrain geometry by applying Random sample consensus (RANSAC) to local point-cloud patches produced by a Simultaneous Localisation And Mapping (SLAM) algorithm.
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
2. Revisiting Topological Graphs for Macro Action based Closed-loop Reinforcement Learning of Vision Language Navigation in Continuous Environment
Revisiting Topological Graphs for Macro Action based Closed-loop Reinforcement Learning of Vision Language Navigation in Continuous Environment
Authors / 作者: Shuhao Ye, Sitong Mao, Yuxiang Cui, Yufei Wei, Xuan Yu, Shichao Zhai et al.
arXiv: 2609.03906 · PDF
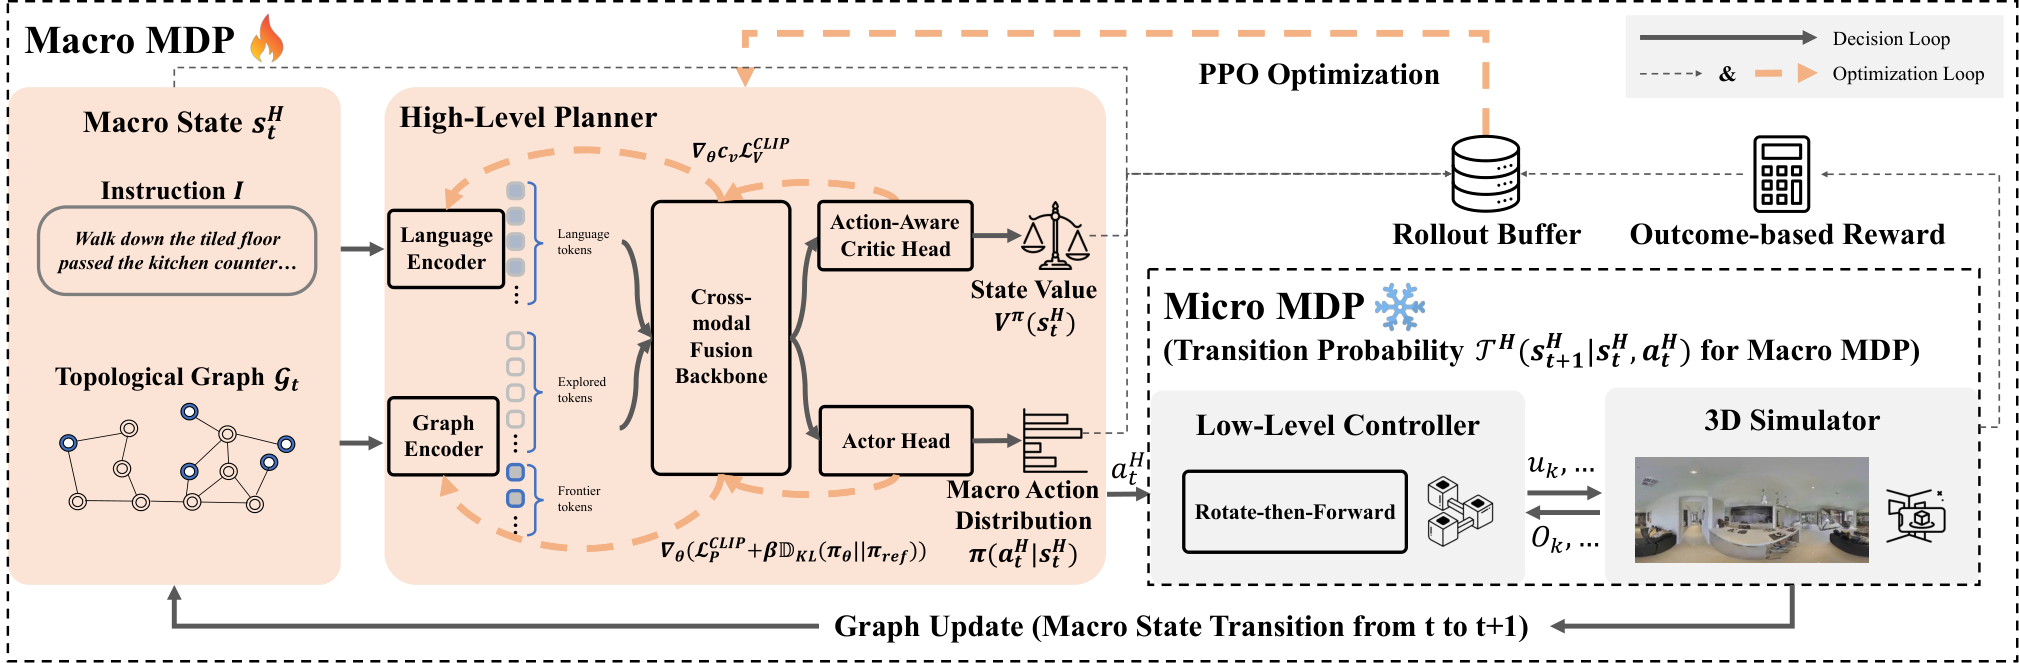
Vision-Language Navigation in Continuous Environments (VLN-CE) requires an agent to follow natural language instructions through unseen environments. Existing imitation learning (IL) pipelines struggle in this closed-loop setting: behavior cloning suffers from distribution shift, and DAgger’s expert actions become ambiguous upon trajectory deviation. While Reinforcement Learning (RL) offers a natural paradigm to address this, directly applying RL to micro action spaces is sample-inefficient due to reward sparsity. To overcome this bottleneck, we reformulate VLN-CE as a Hierarchical Markov Deci
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
3. Predictive Zonotope Reduction: Precise Runtime Monitoring under Uncertainty
Predictive Zonotope Reduction: Precise Runtime Monitoring under Uncertainty
Authors / 作者: Vladimir Krsmanovic, Florian Kohn, Bernd Finkbeiner, Milan Simovic
arXiv: 2609.03699 · PDF
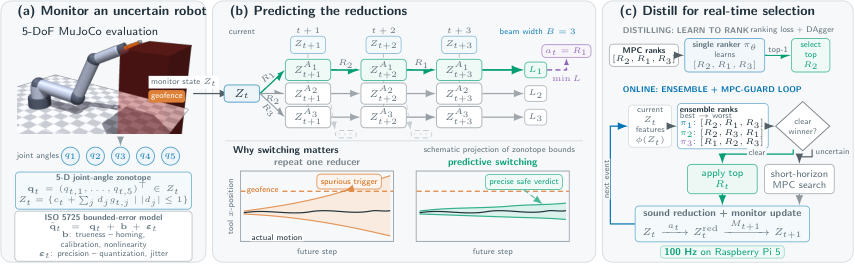
Robots operating in physical environments make control decisions based on uncertain sensor measurements, which can lead to unsafe or suboptimal actions. Runtime monitors that check their behavior against safety specifications must represent this uncertainty soundly. Zonotopes are a widely used representation, but continuously incorporating new measurements grows their order unboundedly, so monitors must periodically apply an over-approximating reduction. The choice of the reduction method substantially affects the zonotope’s precision, yet existing approaches typically utilize a fixed method t
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
4. Can Julia land on the Moon? On the development of a GNC simulation framework for the Argonaut lunar lander
Can Julia land on the Moon? On the development of a GNC simulation framework for the Argonaut lunar lander
Authors / 作者: Francesco Capolupo, Frederik Markus
arXiv: 2609.03843 · PDF
No, the Julia programming language cannot land on the Moon - but it can play a crucial role in designing and analysing the Guidance, Navigation, and Control (GNC) algorithms required for doing so. This paper presents the development of a lunar landing simulation framework implemented in Julia at the European Space Agency (ESA), within the Argonaut lunar lander programme. ATLAS (Argonaut Tools for Landing Analysis and Simulation) is a modular suite of analysis and simulation tools that cover the complete descent and landing phase of Argonaut, integrating high fidelity translational and rotation
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
5. Two-Stage Reinforcement Learning for Sound and Adversarial Test Generation in Code LLMs
Two-Stage Reinforcement Learning for Sound and Adversarial Test Generation in Code LLMs
Authors / 作者: Jiacheng Xu, Wentao Zhang, Zhiyi Lyu, Fuxiang Zhang, Chaojie Wang, Yang Liu et al.
arXiv: 2609.03955 · PDF
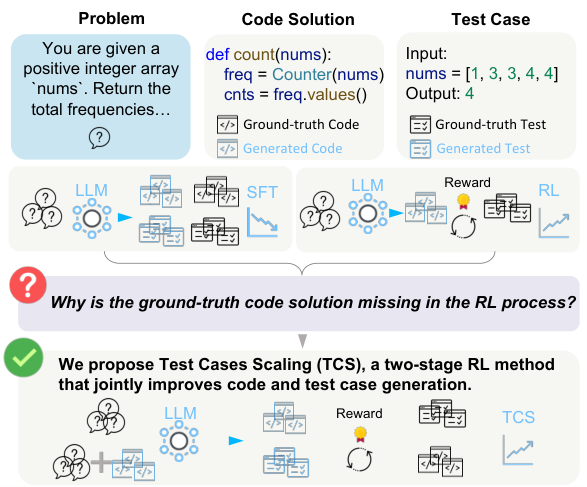
Reinforcement learning (RL) has substantially advanced code generation with large language models (LLMs) through executable feedback. The feedback for coding problems mainly comes from specific test cases, where high-quality test cases are often scarce since they should be both sound and discriminative. We thus turn to study the auto-generation of test cases using the learned model. We find this is naturally an adversarial RL problem: the model is expected to generate effective test cases as counterexamples, depending on the solver’s current failure modes. We propose Test Cases Scaling (TCS),
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。