Robotics Digest
Robotics Paper Digest — 2026-09-01
🤖 Scanned 258 new arXiv papers (cs.RO / eess.SY / cs.LG, last 48 h), picked 5 for modular & legged robotics — summarized by DeepSeek.
🤖 扫描了近 48 小时 arXiv(cs.RO / eess.SY / cs.LG)的 258 篇新论文,围绕模块化与足式机器人精选 5 篇 — 由 DeepSeek 生成双语摘要。
1. SleepWalking: Privileged Representation Shaping for End-to-End Blind Locomotion in Legged Robots
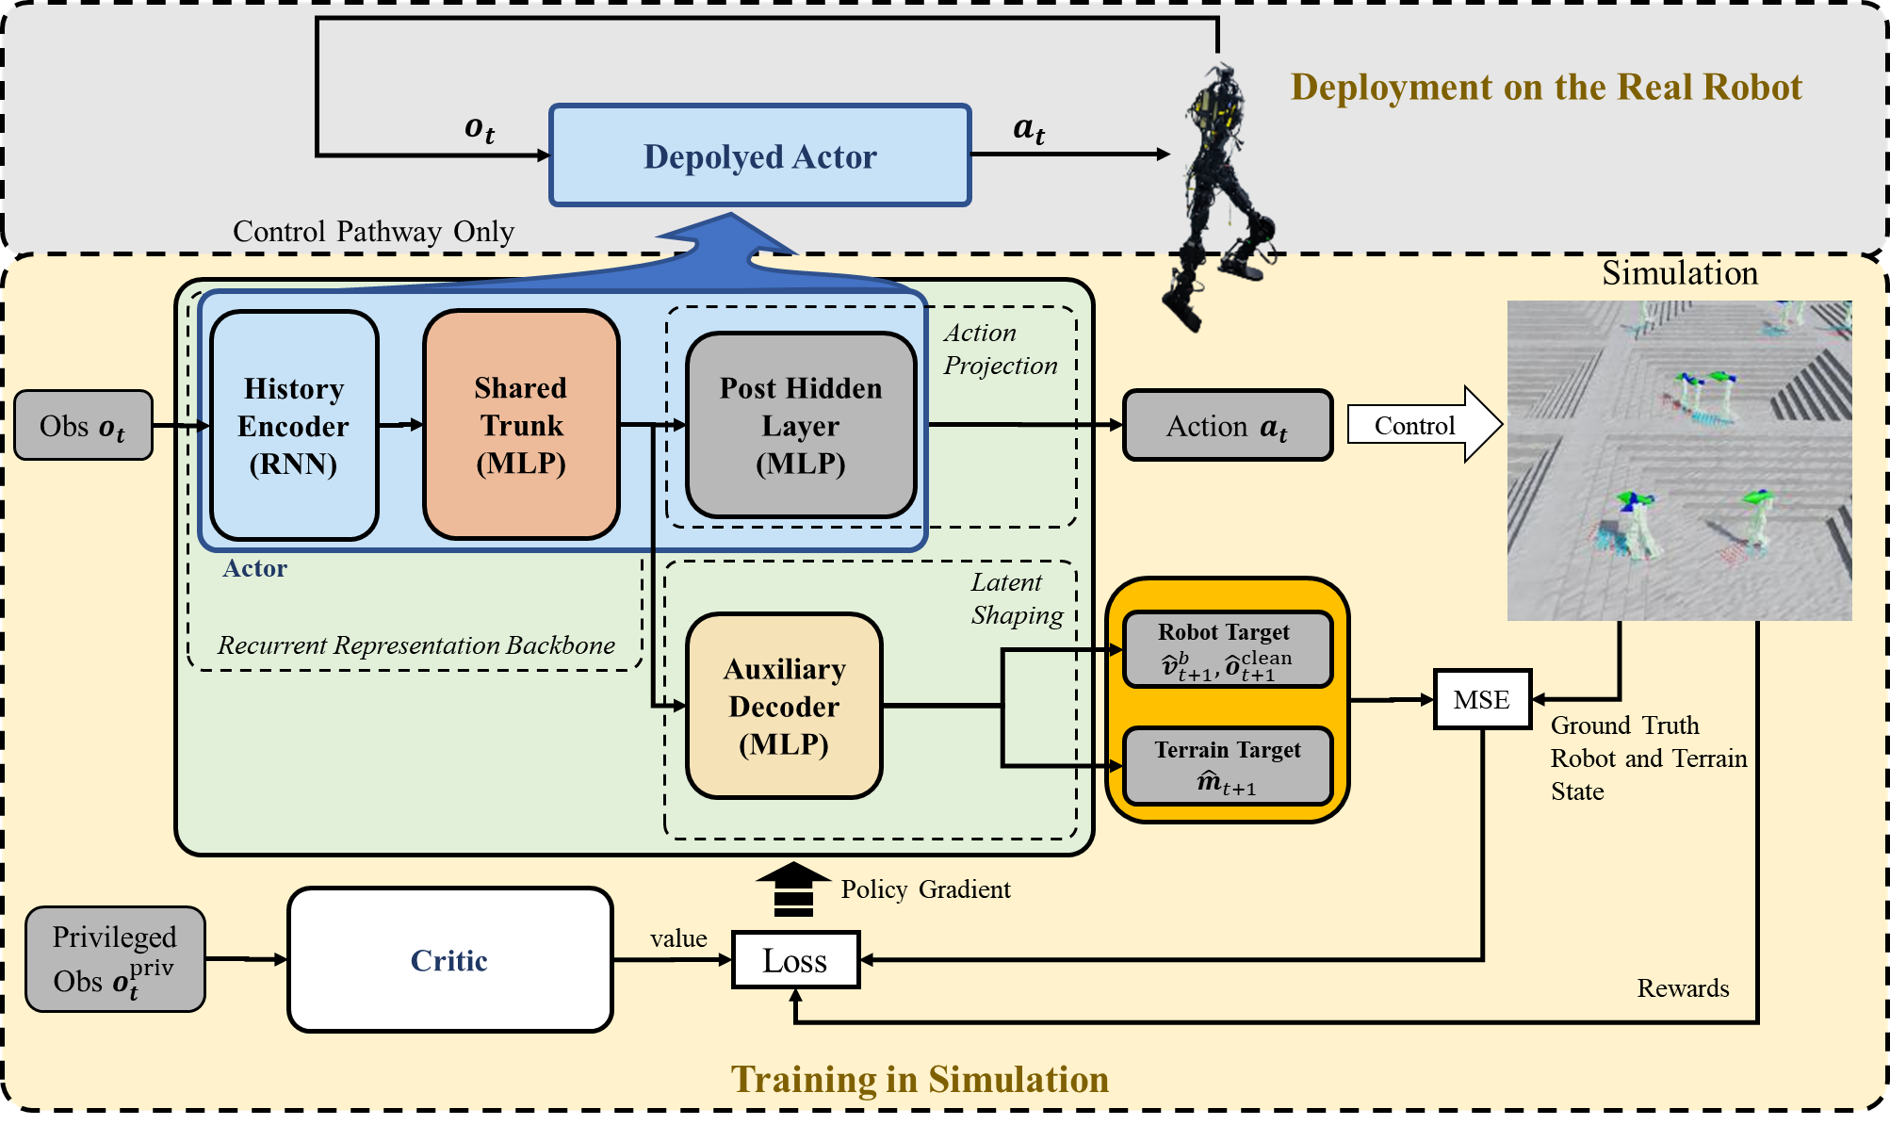
SleepWalking: Privileged Representation Shaping for End-to-End Blind Locomotion in Legged Robots
Authors / 作者: Zheng Pan, Tenghui Wang, Peilin Li, Shiyu Zhou, Hao Sun, Yan Ma et al.
arXiv: 2608.30883 · PDF
Partially observable locomotion requires a policy to act when task-relevant properties of the robot—environment state are not fully specified by instantaneous observations. Existing approaches often address this challenge by explicitly estimating missing physical variables or processing extended observation histories through structured architectures. We take a different view: partial observability is fundamentally an information-retention problem. The decisive question is not how task-relevant information enters the network, but whether the policy’s internal state retains it. Guided by this p
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
2. A Dual-Cam Parallel Elastic Actuator with Shared Gas-Spring Compensation for Humanoid Ankles
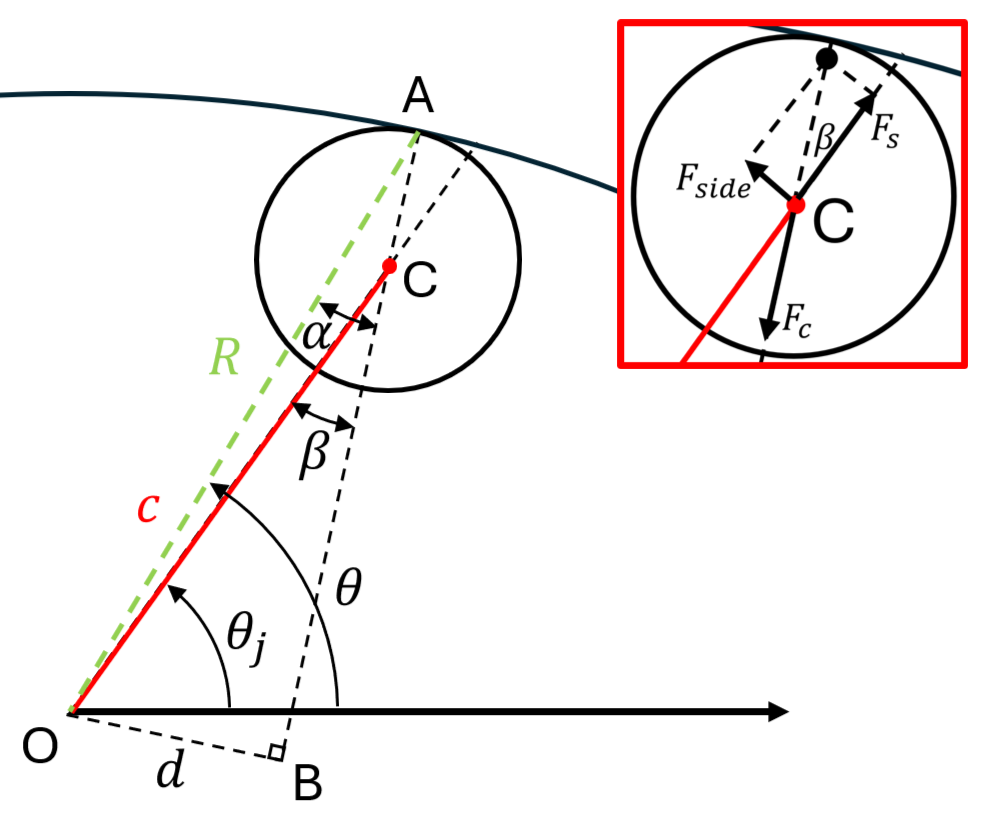
A Dual-Cam Parallel Elastic Actuator with Shared Gas-Spring Compensation for Humanoid Ankles
Authors / 作者: Jingcheng Jiang, Yifang Zhang, Nikos G. Tsagarakis
arXiv: 2608.30832 · PDF
To improve torque capacity and energy efficiency of humanoid ankles, this paper proposes a 2-DoF parallel elastic actuator (PEA). The main novelty of the proposed design lies in its dual-cam, single-gas-spring architecture, which enables torque compensation in both pitch and roll using a shared elastic element, thereby improving structural compactness compared with conventional multi-element compensation schemes. By leveraging parallel gas springs and customized cam modules, the proposed architecture provides dual-axis torque assistance tailored to specific task requirements. The second key co
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
3. SUN: Persistent Programs For Language-Grounded Control-to-Learning-to-Real Policies
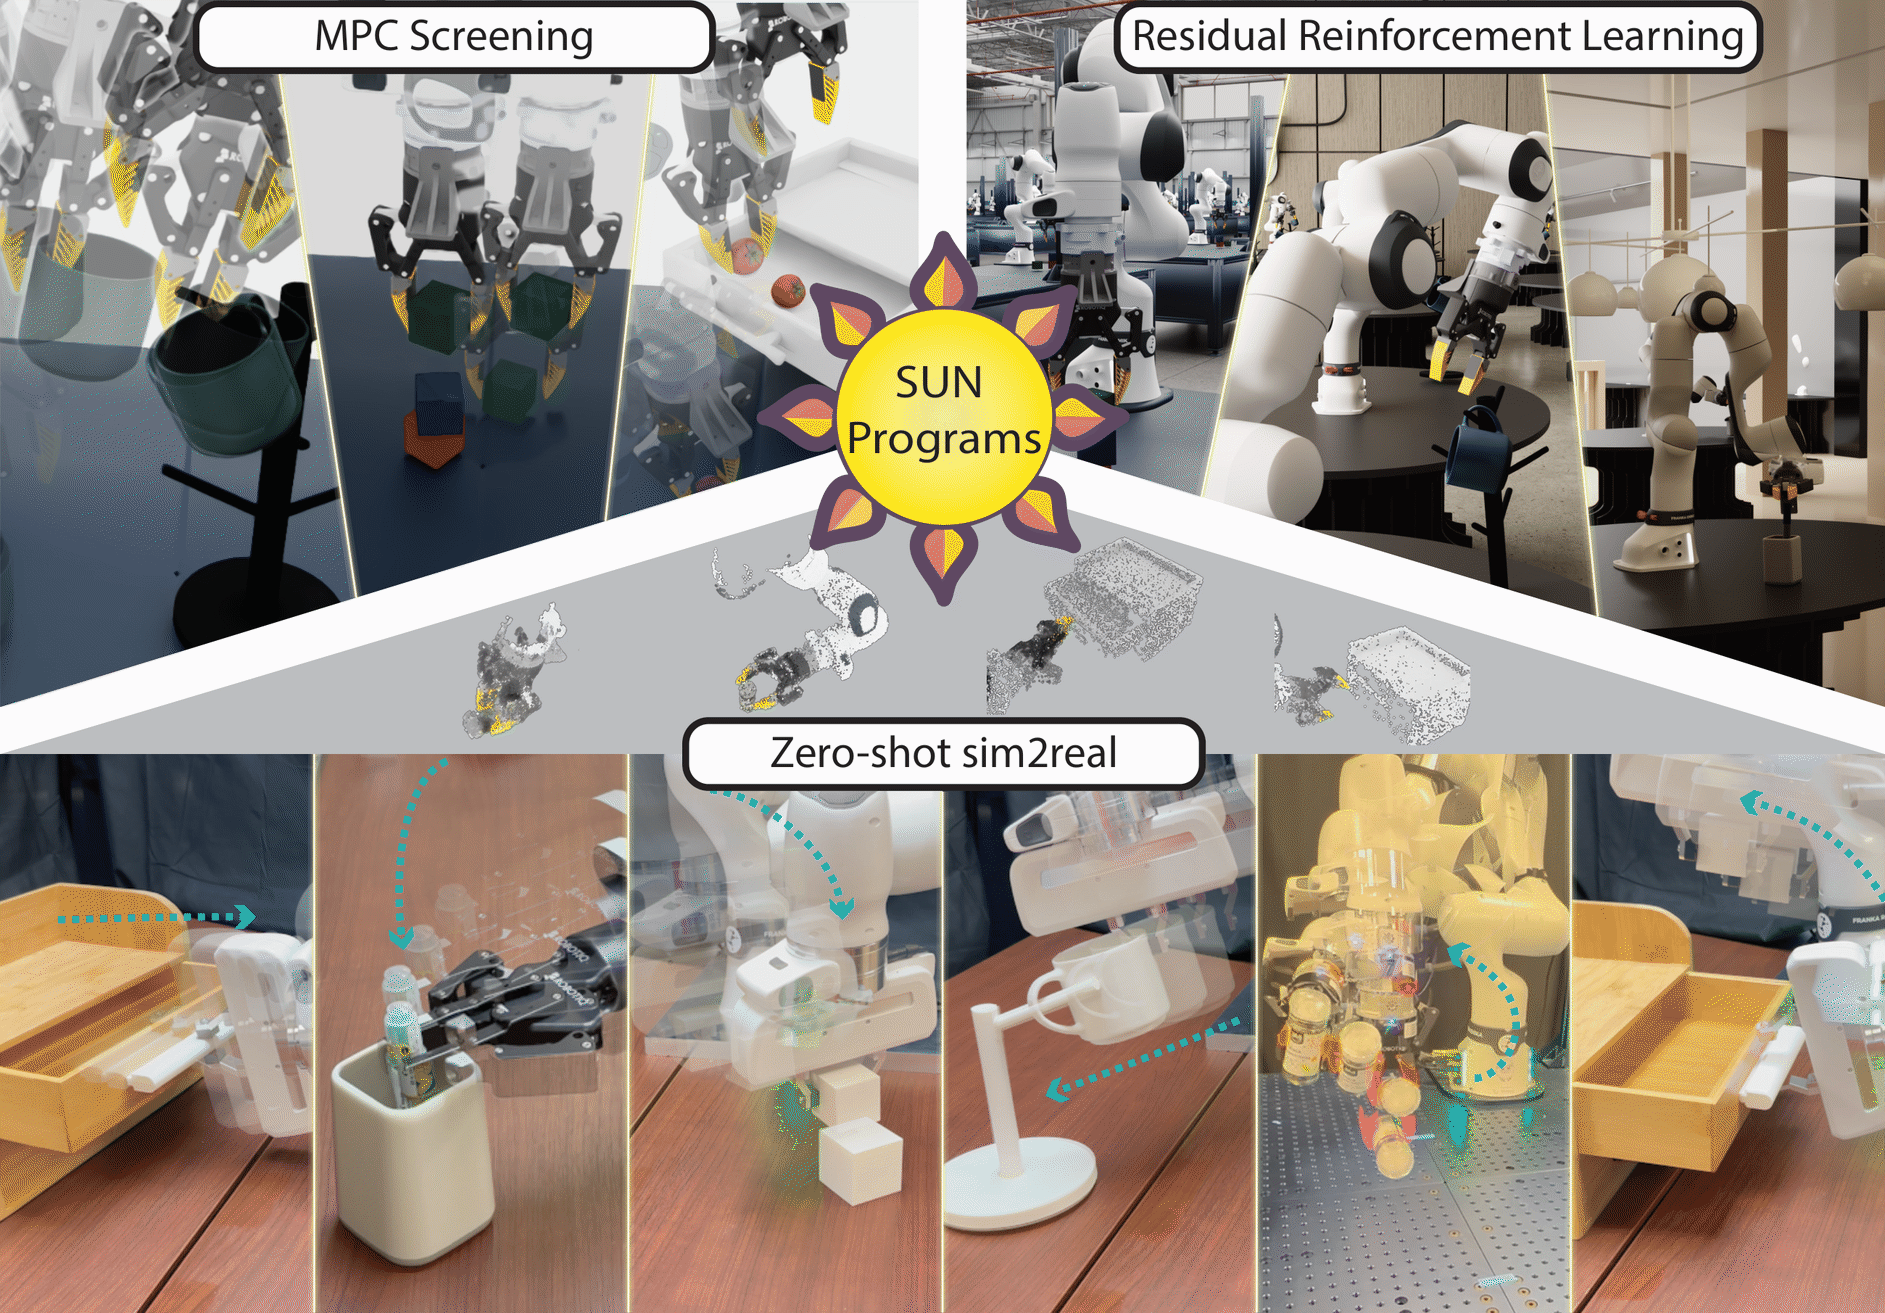
SUN: Persistent Programs For Language-Grounded Control-to-Learning-to-Real Policies
Authors / 作者: Weiqi Wang, Zhi Li, Yudong Lei, David Martinez, Xiaofeng Gao, Yuxin Jiang et al.
arXiv: 2608.31167 · PDF
Bridging model-based control and learned policies in long-horizon manipulation has harbored a silent disagreement: control executes specified objectives, learning amortizes that behavior into a reactive policy, yet existing protocols discard task semantics, leaving rewards hand-crafted and behavior drifting from what control verified.We introduce Semantically UNified (SUN) Programs, typed executables where geometric and contact relations are defined once and compiled into aligned Model Predictive Control (MPC) costs, satisfaction predicates, RL rewards, transition guards, and diagnostics. Our
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
4. Learning Agile Perceptive Traversal of Sparse 3D Structures for Humanoids
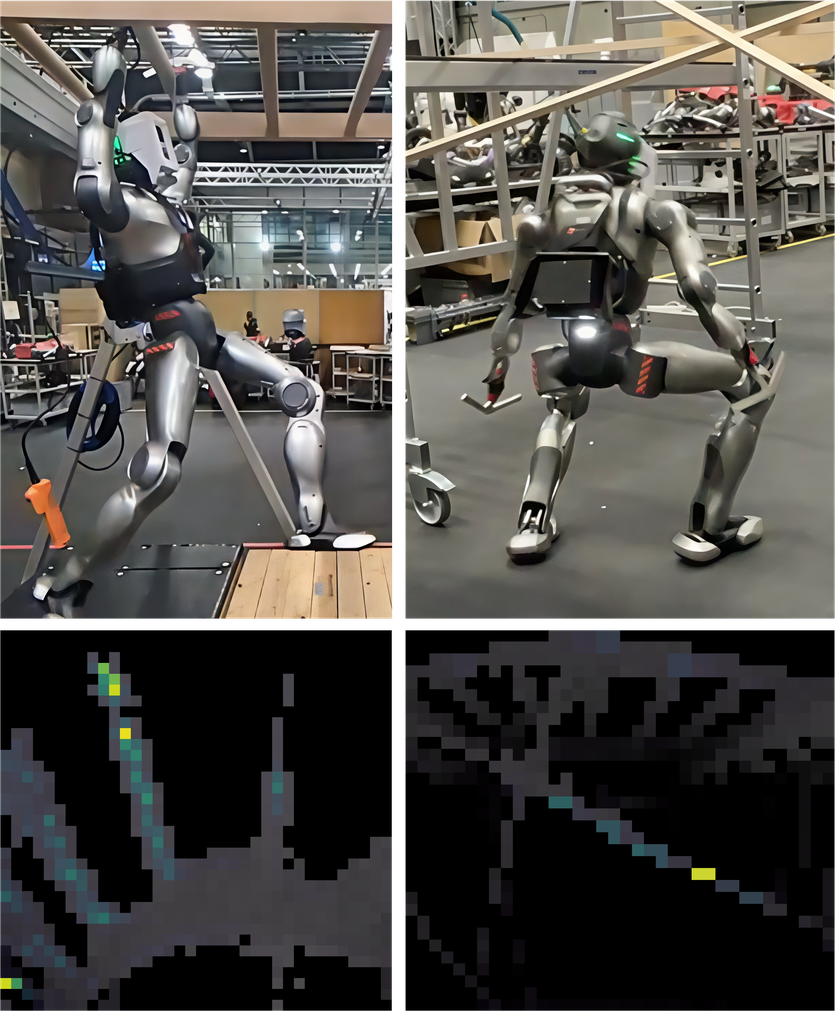
Learning Agile Perceptive Traversal of Sparse 3D Structures for Humanoids
Authors / 作者: Efe Ongan, Chong Zhang, Boyang Sun, Andrei Cramariuc, Cesar Cadena, Marco Hutter
arXiv: 2608.29769 · PDF
Traversing sparse 3D structures requires humanoid robots to perceive thin, overhanging geometry while executing agile, accurate whole-body motions. We study this problem through monkey-bar traversal, where the robot must jump to the structure, traverse it through sparse bar interactions, and land safely. For this task, we present a reinforcement-learning-based perceptive control system that operates directly on observations from a head-mounted solid-state lidar. To extract task-relevant geometry from the sparse returns, the policy consumes the raw lidar scan through an attention-based encoder
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
5. On the suboptimality of stochastic MPC with varying constraint horizon
On the suboptimality of stochastic MPC with varying constraint horizon
Authors / 作者: Allan Andre Do Nascimento, Andre Bertolace, Antonis Papachristodoulou, Kostas Margellos
arXiv: 2608.30017 · PDF
Enforcing stochastic state constraints over the full prediction horizon in Model Predictive Control (MPC) can be computationally demanding. Here we study stochastic MPC without terminal ingredients in which chance constraints are enforced only over a shorter constraint horizon. Using stochastic relaxed dynamic programming, we derive an explicit upper bound on the average expected closed-loop cost that depends on both prediction and constraint horizons. For linear quadratic problems with affine chance constraints and bounded uniform disturbances, we provide a deterministic reformulation via coo
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。