Robotics Digest
Robotics Paper Digest — 2026-08-31
🤖 Scanned 239 new arXiv papers (cs.RO / eess.SY / cs.LG, last 96 h), picked 5 for modular & legged robotics — summarized by DeepSeek.
🤖 扫描了近 96 小时 arXiv(cs.RO / eess.SY / cs.LG)的 239 篇新论文,围绕模块化与足式机器人精选 5 篇 — 由 DeepSeek 生成双语摘要。
1. Contact-Guided Exploration for Non-Prehensile Locomanipulation with Multi-Critic RL
基于多评论家强化学习的接触引导探索用于非抓取式移动操纵
Authors / 作者: Simone Tolomei, Mayank Mittal, Franco Angelini, Manolo Garabini, Paolo Salaris, Marco Hutter
arXiv: 2608.28140 · PDF
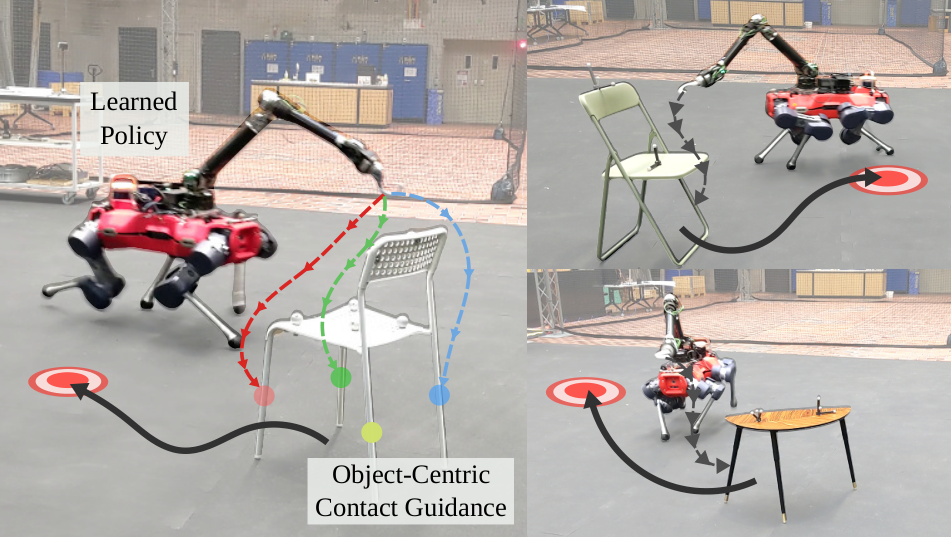
This paper proposes a contact-guided exploration strategy for non-prehensile locomanipulation within a multi-critic reinforcement learning framework. An exploration critic is trained with dense contact-seeking rewards and its influence is progressively decayed to recover a task-optimal policy. The approach is validated on a real quadrupedal mobile manipulator for chair transportation.
中文摘要: 本文提出了一种基于多评论家强化学习框架的非抓取式移动操纵的接触引导探索策略。通过训练一个带有密集接触搜索奖励的探索评论家,并逐步衰减其影响,从而恢复任务最优策略。该方法在真实四足移动操纵平台上进行了椅子搬运任务的验证,展示了可部署的非抓取式操纵能力。
💬 Strong real-world demonstration of quadruped locomanipulation using multi-critic RL with contact-guided exploration.
💬 通过多评论家RL和接触引导探索,在真实四足平台上展示了强烈的移动操纵能力。
Why read it / 推荐理由: Shows how to combine RL with contact-seeking exploration for whole-body locomanipulation on a real quadruped. 展示了如何将RL与接触引导探索相结合,在真实四足机器人上实现全身移动操纵。
2. Stay Seated: Learning Omnidirectional Humanoid Locomotion on a Passive Mobile Chair with Casters
保持坐姿:在带脚轮的被动移动椅子上学习全向人形运动
Authors / 作者: Kango Yanagida, Kazuki Miyazawa, Takato Horii
arXiv: 2608.28090 · PDF
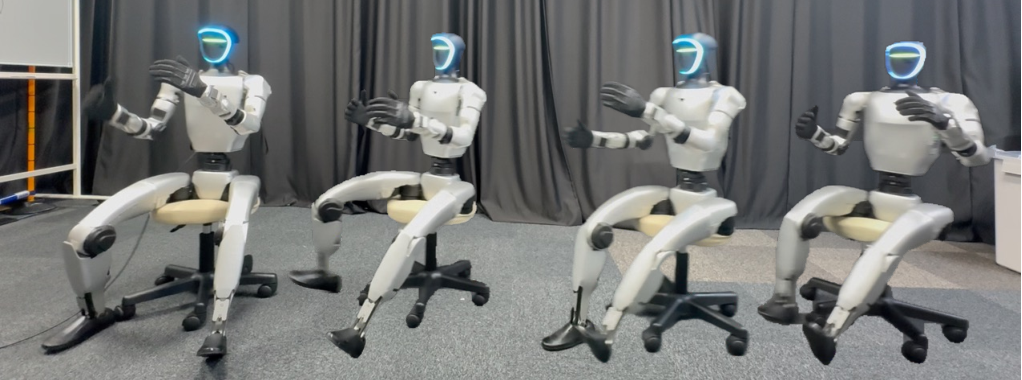
This work studies omnidirectional seated locomotion on a passive mobile chair for humanoid robots, extending a standing velocity-tracking environment with a passive-chair model. The policy is learned without motion-imitation rewards and uses only proprioception and velocity commands. Best seated policies outperform the standing policy in velocity tracking, with foot-slip regularization reducing cost of transport but increasing tracking error.
中文摘要: 本研究探讨了人形机器人在被动移动椅子上的全向坐姿运动,通过被动椅子模型扩展了站立速度跟踪环境。策略在没有运动模仿奖励的情况下学习,仅使用本体感觉和速度指令。最好的坐姿策略在速度跟踪上优于站立策略,而脚滑正则化降低了移动代价但增加了跟踪误差。
💬 Interesting extension of legged locomotion to a quasi-passive seated posture; the RL formulation without motion imitation is notable.
💬 将腿部运动扩展到准被动坐姿的有趣尝试,无运动模仿的RL公式值得关注。
Why read it / 推荐理由: Provides a novel RL-based controller for a legged robot in a non-standard posture, with insights on reward shaping and symmetry regularization. 为非标准姿态下的腿式机器人提供了新颖的RL控制器,并对奖励塑形和对称正则化提供了见解。
3. Anytime Primal—Dual Certification of the Maximum Disturbance Radius in Robust MPC
鲁棒MPC中最大扰动半径的随时原始-对偶认证
Authors / 作者: Wenqi Cai, Muhammad Bakr Abdelghany, Kyriakos G. Vamvoudakis, Anthony Tzes
arXiv: 2608.28056 · PDF
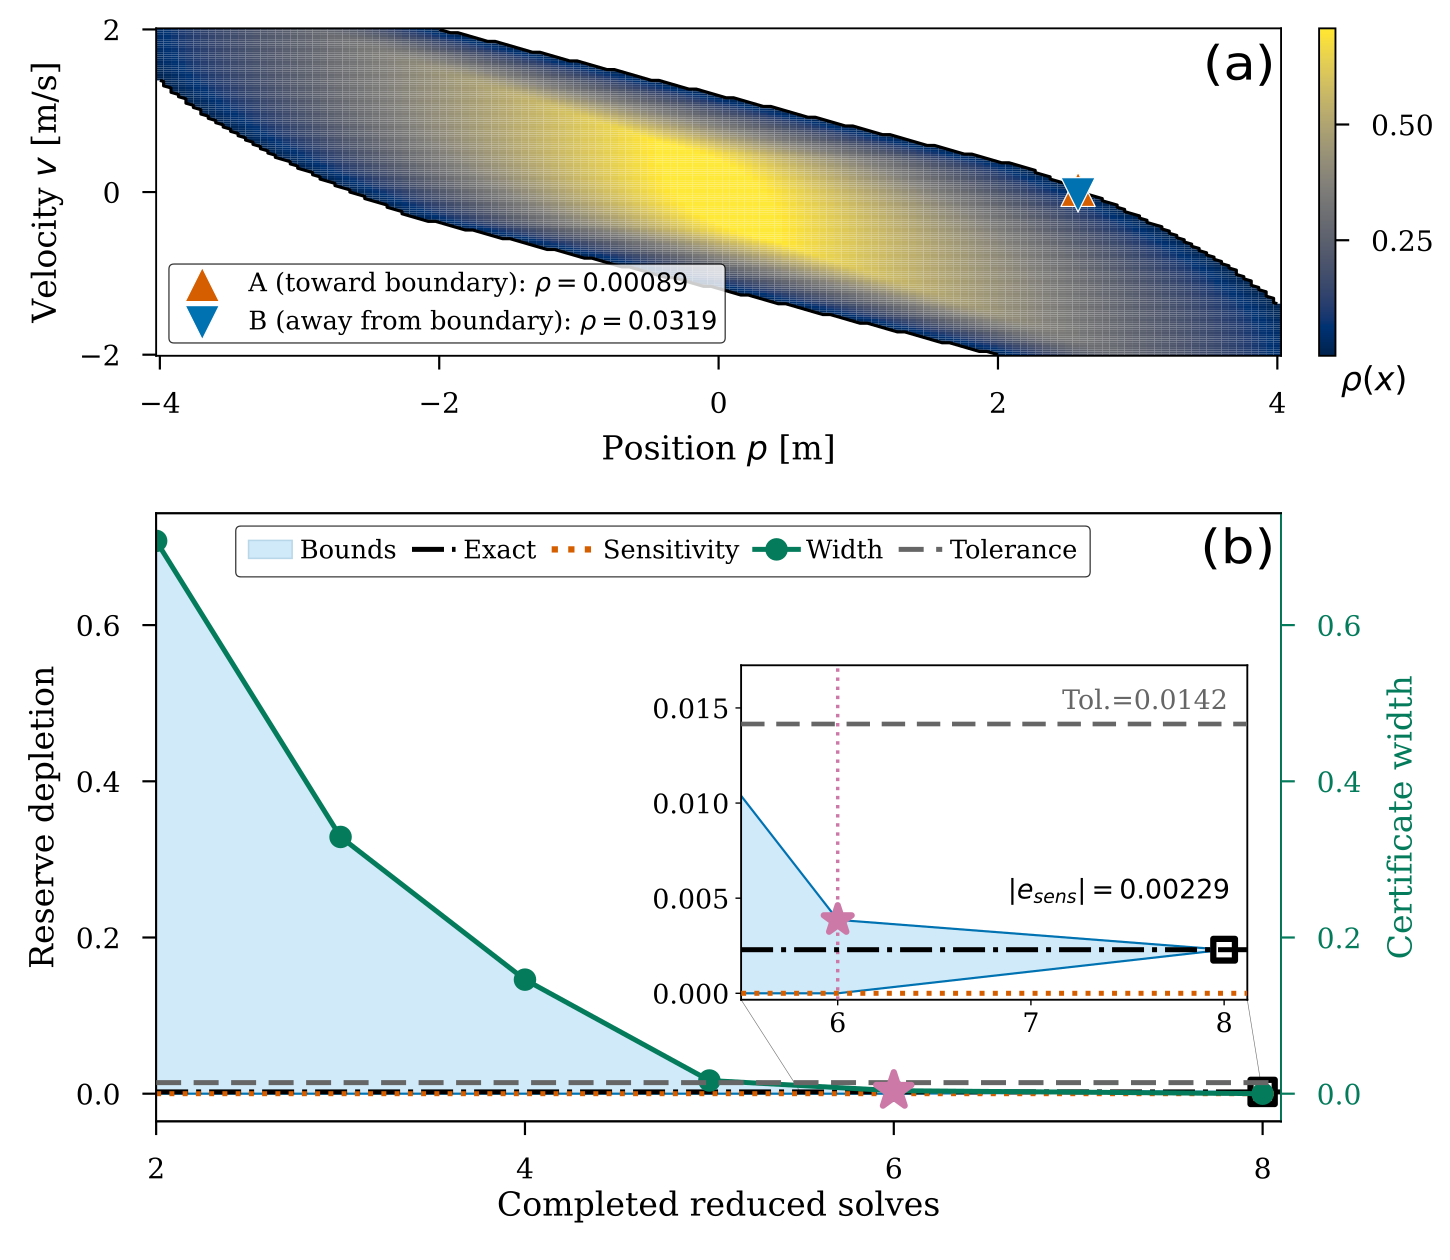
This paper introduces anytime primal-dual certification for the maximum disturbance radius in adjustable-set robust MPC. It proposes a two-sided reserve-depletion envelope with monotone bounds, enabling early termination. Numerical studies show no certificate violations and up to 4.97x speedup over warm-started full re-optimization.
中文摘要: 本文针对可调整集鲁棒MPC中的最大扰动半径,提出了一种随时原始-对偶认证方法。通过构造具有单调边界的两侧储备耗尽包络,支持提前终止。数值测试表明无证书违反,且相比热启动全重优化最高可实现4.97倍加速。
💬 Theoretical MPC contribution providing anytime certification of robustness margins, potentially valuable for safe legged locomotion.
💬 理论MPC贡献,提供鲁棒裕度的实时认证,对安全腿部运动控制具有潜在价值。
Why read it / 推荐理由: Offers a computationally efficient way to certify disturbance bounds in MPC, which could improve safety guarantees in legged control. 提供了一种计算高效的方法来认证MPC中的扰动界,从而增强腿部控制的安全保障。
4. Distributed Model Predictive Control for Optimal Consensus of Constrained Heterogeneous Multi-agent Systems
约束异构多智能体系统最优一致性的分布式模型预测控制
Authors / 作者: Nan Bai, Tao Liu, Qishao Wang, Zhisheng Duan
arXiv: 2608.28180 · PDF
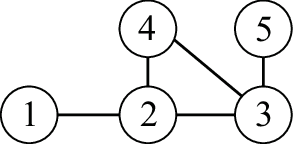
The paper addresses distributed optimal consensus control of constrained heterogeneous multi-agent systems using MPC. It jointly optimizes control input sequences and dynamically feasible consensus equilibrium, and develops a distributed primal-dual algorithm. Sufficient terminal conditions are established for recursive feasibility and asymptotic consensus.
中文摘要: 本文研究了基于MPC的约束异构多智能体系统分布式最优一致控制。在MPC框架中同时优化控制输入序列和动态可行的共识平衡点,并开发了分布式原-对偶算法。建立了保证递推可行性和渐近一致的充分终端条件,并通过数值模拟验证了有效性。
💬 Distributed MPC for heterogeneous multi-agent systems with consensus; could inspire modular legged robots with decentralized control.
💬 用于异构多智能体系统的分布式MPC,可启发分布式控制模块化腿式机器人。
Why read it / 推荐理由: Addresses coupled optimization and terminal conditions for distributed MPC, relevant for modular or multi-robot legged platforms. 解决了分布式MPC中的耦合优化和终端条件问题,与模块化或多机器人腿部平台相关。
5. PAMoR: Parameterized Affective Motion Generation in Real Time for Humanoid Robots
PAMoR:人形机器人实时参数化情感运动生成
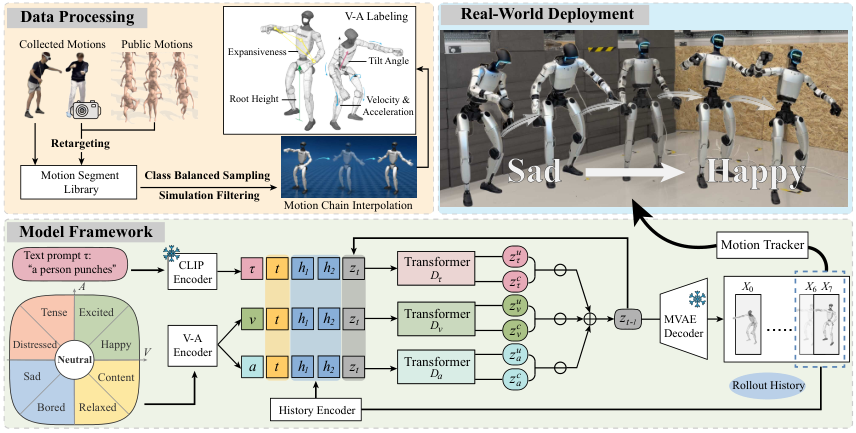
Authors / 作者: Yan Pan, Lingfan Bao, Tianhu Peng, Chengxu Zhou
arXiv: 2608.28213 · PDF
PAMoR turns affect into a measured control parameter using a valence-arousal coordinate computed from robot kinematics. It uses action and affect priors in a shared latent space to modulate whole-body motion generation on a 29-DoF Unitree G1 in real time. In a perceptual study, raters identified the commanded emotion on 0.38 of trials, above baselines.
中文摘要: PAMoR通过从机器人运动学计算的效价-唤醒度坐标,将情感转化为可测量的控制参数。它利用共享潜在空间中的动作先验和情感先验,在29自由度Unitree G1上实时调制全身运动生成。感知实验中,评估者在38%的试验中识别出了指定情感,高于基线。
💬 Humanoid motion generation with controllable affect; less directly about control, but useful for expressive whole-body motion.
💬 人形机器人运动生成,可控制情感表达;虽然与控制不直接相关,但有助于表达性全身运动。
Why read it / 推荐理由: Demonstrates real-time autoregressive generation of editable whole-body motion on a humanoid, relevant for HRI in legged robots. 演示了在人形机器人上实时自回归生成可编辑的全身运动,与腿式机器人的人机交互相关。