Robotics Digest
Robotics Paper Digest — 2026-08-30
🤖 Scanned 290 new arXiv papers (cs.RO / eess.SY / cs.LG, last 96 h), picked 5 for modular & legged robotics — summarized by DeepSeek.
🤖 扫描了近 96 小时 arXiv(cs.RO / eess.SY / cs.LG)的 290 篇新论文,围绕模块化与足式机器人精选 5 篇 — 由 DeepSeek 生成双语摘要。
1. Active Surface-Driven Reconfigurable Gripper: Robust Grasping and Sequential Manipulation of Thin Objects
Active Surface-Driven Reconfigurable Gripper: Robust Grasping and Sequential Manipulation of Thin Objects
Authors / 作者: Ziyi Zheng, Keqi Zhu, Hao Wu, Yanzhe Wang, Huixu Dong
arXiv: 2608.26883 · PDF
Robotic grippers face substantial challenges in grasping and manipulating thin objects. Most existing grippers rely on highly precise approach and grasp motions, which limits robustness and reduces applicability. This paper explores thin-object grasping using books as a representative example. Here, we propose a novel solution that integrates an active surface with underactuated compliance to achieve stable grasping of thin objects without complex control. First, an underactuated gripper with an active surface is designed. The active-surface thumb performs in-hand repositioning of the target b
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
2. Anytime Global Tensor Motion Planning
Anytime Global Tensor Motion Planning
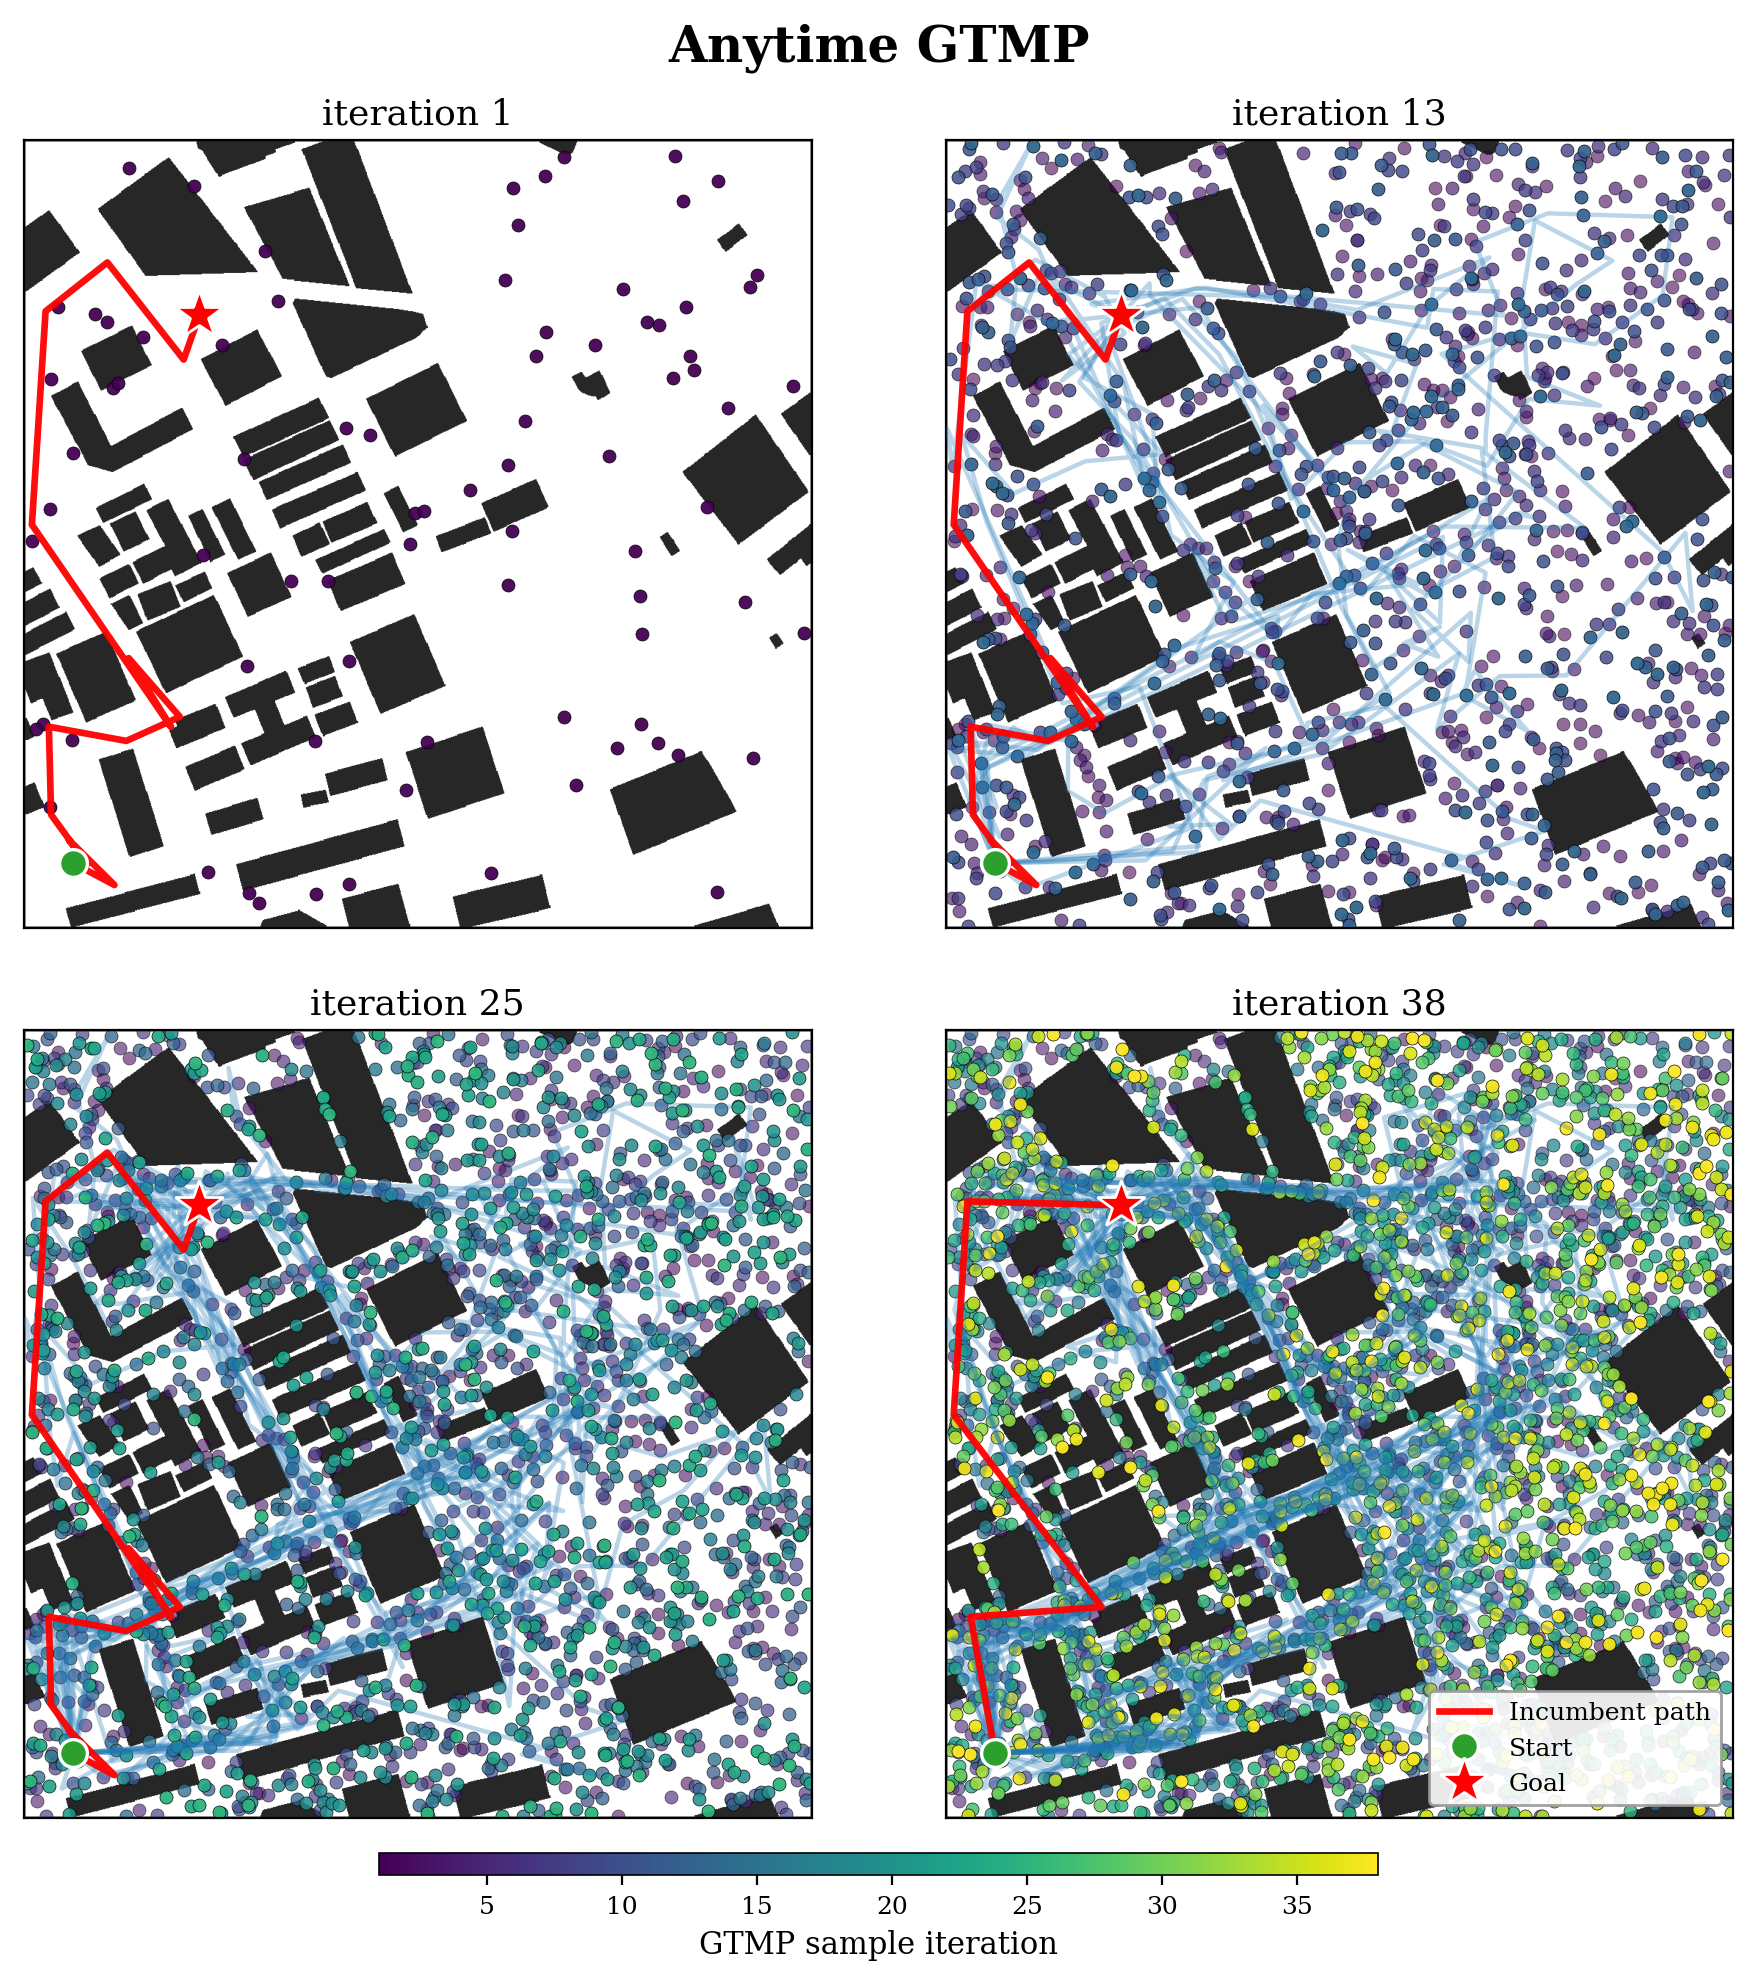
Authors / 作者: Sai Coumar, An T. Le, Zachary Kingston
arXiv: 2608.25830 · PDF
Global Tensor Motion Planning (GTMP) solves motion planning with batched tensor operations over a layered multipartite graph. We generalize GTMP so that adjacent-layer edges are realized by any black-box local planner (e.g., linear interpolation, splines, sampling-based planning, trajectory optimization, or generative sampling). We provide two anytime policies on top of this generalization: Anytime GTMP with random restarts at a fixed budget, which covers every homotopy class almost surely, and AO-GTMP with informed expansion with growing budgets, which converges to the optimal cost. We prove
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
3. EgoNav: Bridging Learned Waypoints and Geometry-Aware Local Control for Robust Indoor Navigation
EgoNav: Bridging Learned Waypoints and Geometry-Aware Local Control for Robust Indoor Navigation
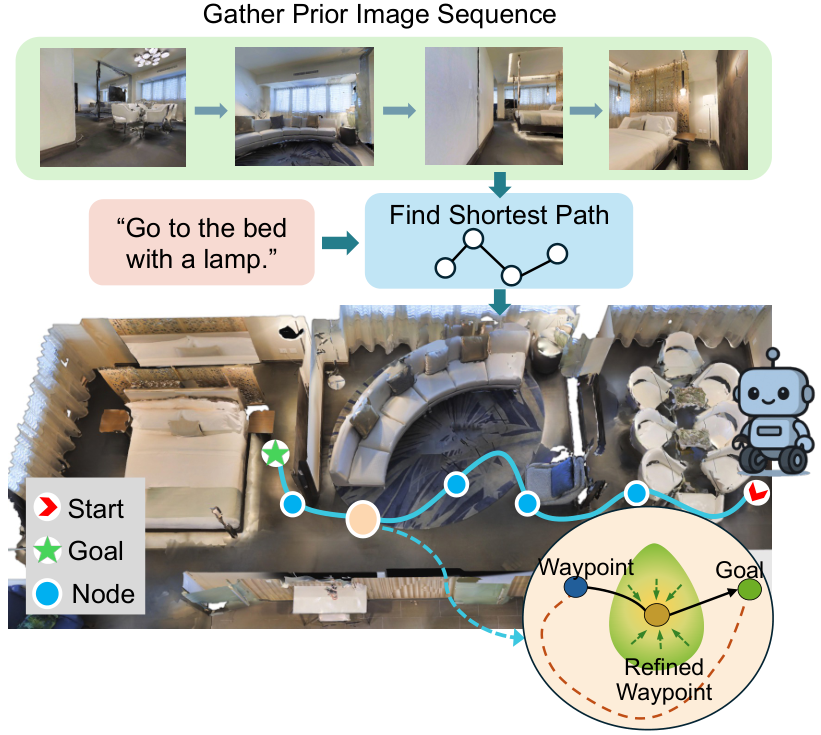
Authors / 作者: Jing Wang, Shiqi Zhao, Hairong Qu, Peng Yin
arXiv: 2608.25642 · PDF
Image-goal navigation using lightweight topological maps is a practical paradigm for indoor robot deployment: the map requires only geotagged images, and localization relies on visual matching rather than precise pose estimation. However, learned waypoint predictors can produce targets that violate geometric constraints or deviate from the global path. Executing these waypoints safely further requires a local planner capable of collision avoidance, yet existing systems either lack one or rely on fixed parameters that cannot adapt to confined spaces. To address these limitations while retaining
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
4. Planning a Shared Modular Fixture Layout Across Robotic Disassembly Stages
Planning a Shared Modular Fixture Layout Across Robotic Disassembly Stages
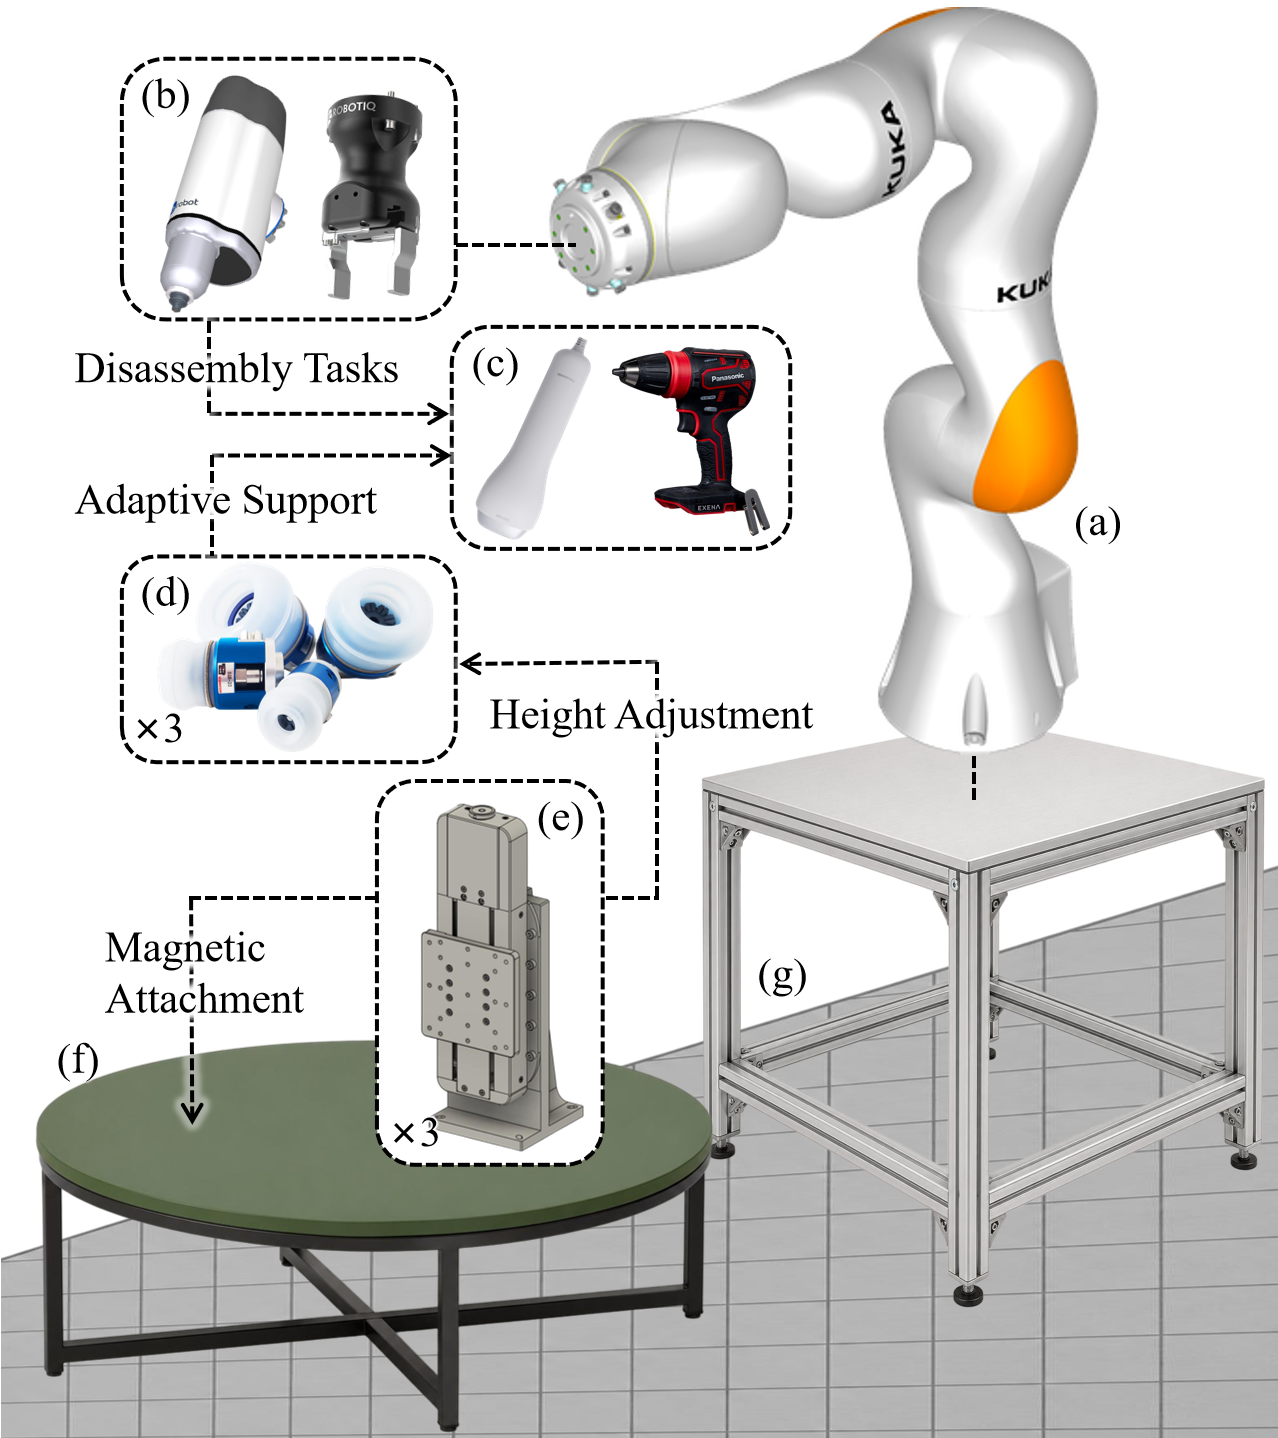
Authors / 作者: Haohui Pan, Takuya Kiyokawa, Kensuke Harada
arXiv: 2608.27151 · PDF
Stable support remains challenging in robotic disassembly of irregularly shaped products. As components are progressively removed, the available support surfaces, mass distribution, and task loads change throughout the process. A fixture layout designed for one workpiece state may therefore become infeasible at later stages, motivating unified support planning over the complete disassembly sequence. This paper presents a modular vacuum-based fixturing system that plans one shared support configuration for the complete disassembly sequence of a screwdriver or shaver, allowing each sequence to p
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
5. One Policy, Many Embodiments: Unified Camera-Centric Action Geometry Pre-training for Heterogeneous Embodied Manipulation
One Policy, Many Embodiments: Unified Camera-Centric Action Geometry Pre-training for Heterogeneous Embodied Manipulation
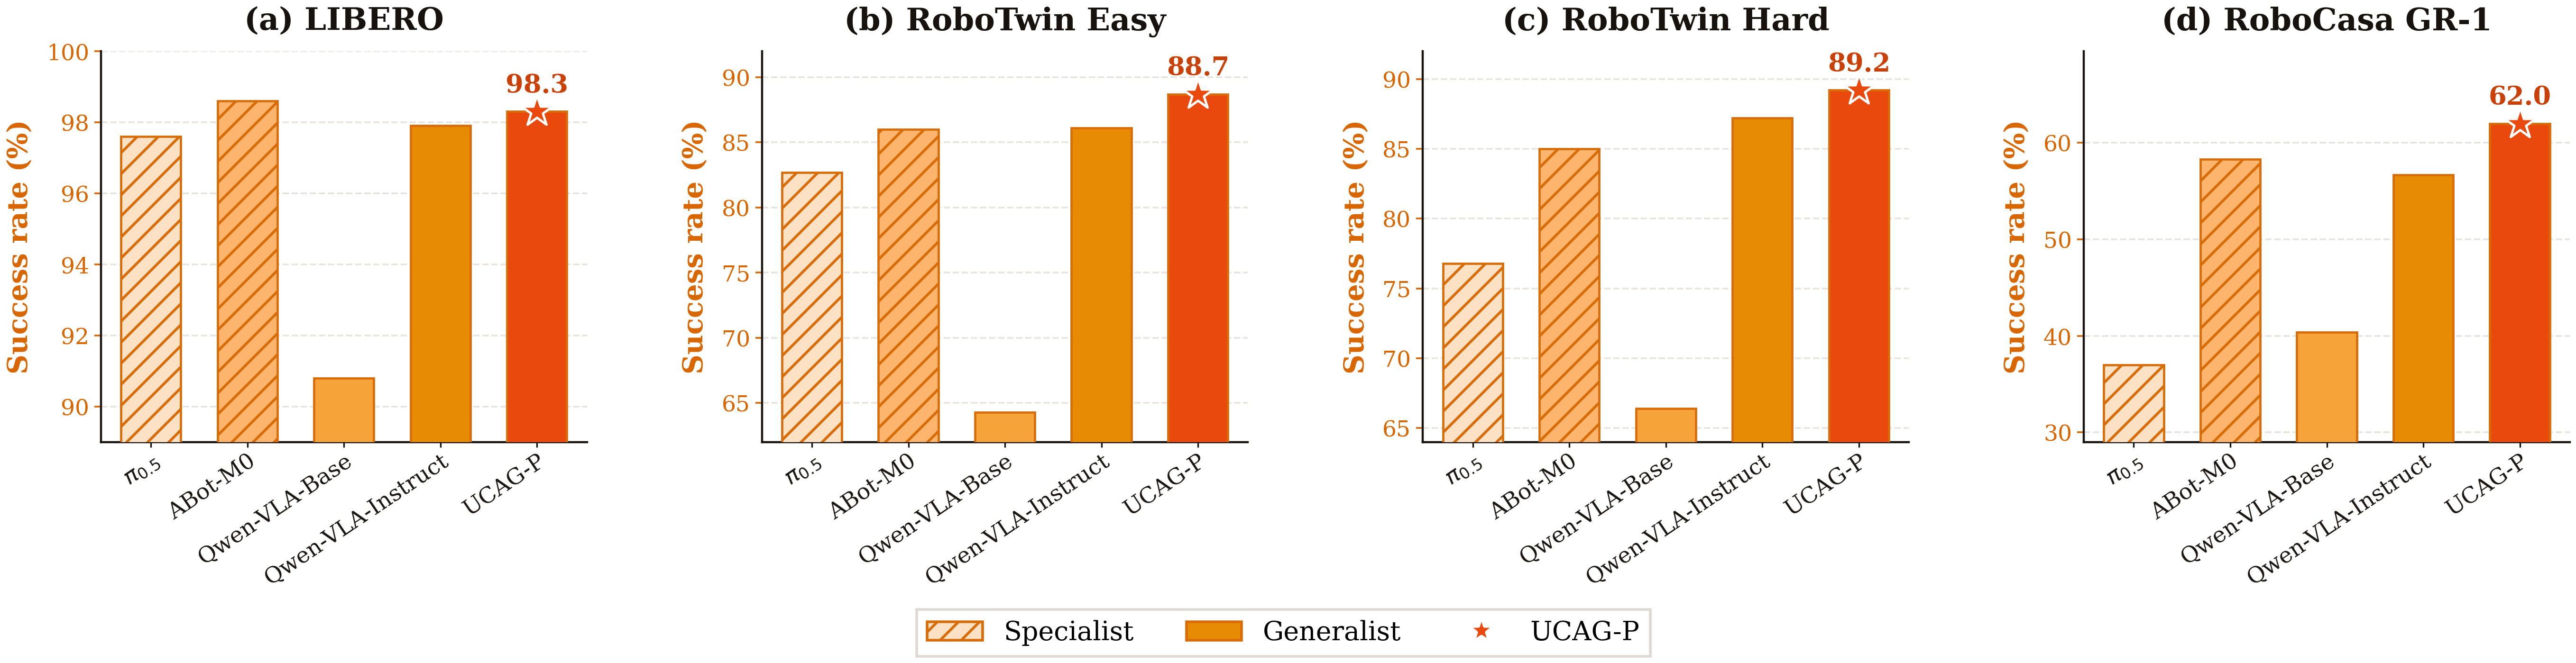
Authors / 作者: Xiaomi Embodied Intelligence Team, University of Macau, :, Shaoqing Xu, Fang Li, Guozhi Zhan et al.
arXiv: 2608.26058 · PDF
Scaling generalist vision-language-action (VLA) policies is severely bottlenecked by the inherent heterogeneity of embodied data, which spans diverse robot morphologies, camera configurations, and low-level action spaces. Existing paradigms typically address this mismatch through explicit action retargeting, human-to-robot video synthesis, or dataset-specific adaptation branches, fundamentally hindering the joint learning of a unified policy. We introduce UCAG-P, a camera-centric unified action formulation that structurally aligns heterogeneous embodied datasets into a shared geometric action
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。