Robotics Digest
Robotics Paper Digest — 2026-08-12
🤖 Scanned 328 new arXiv papers (cs.RO / eess.SY / cs.LG, last 48 h), picked 5 for modular & legged robotics — summarized by DeepSeek.
🤖 扫描了近 48 小时 arXiv(cs.RO / eess.SY / cs.LG)的 328 篇新论文,围绕模块化与足式机器人精选 5 篇 — 由 DeepSeek 生成双语摘要。
1. Whole-Body Planning for Humanoids Navigating Confined Spaces via Self-Collision Avoidance References
基于自碰撞避免参考的类人机器人狭窄空间全身规划
Authors / 作者: Carlos Gonzalez, Luis Sentis
arXiv: 2608.10220 · PDF
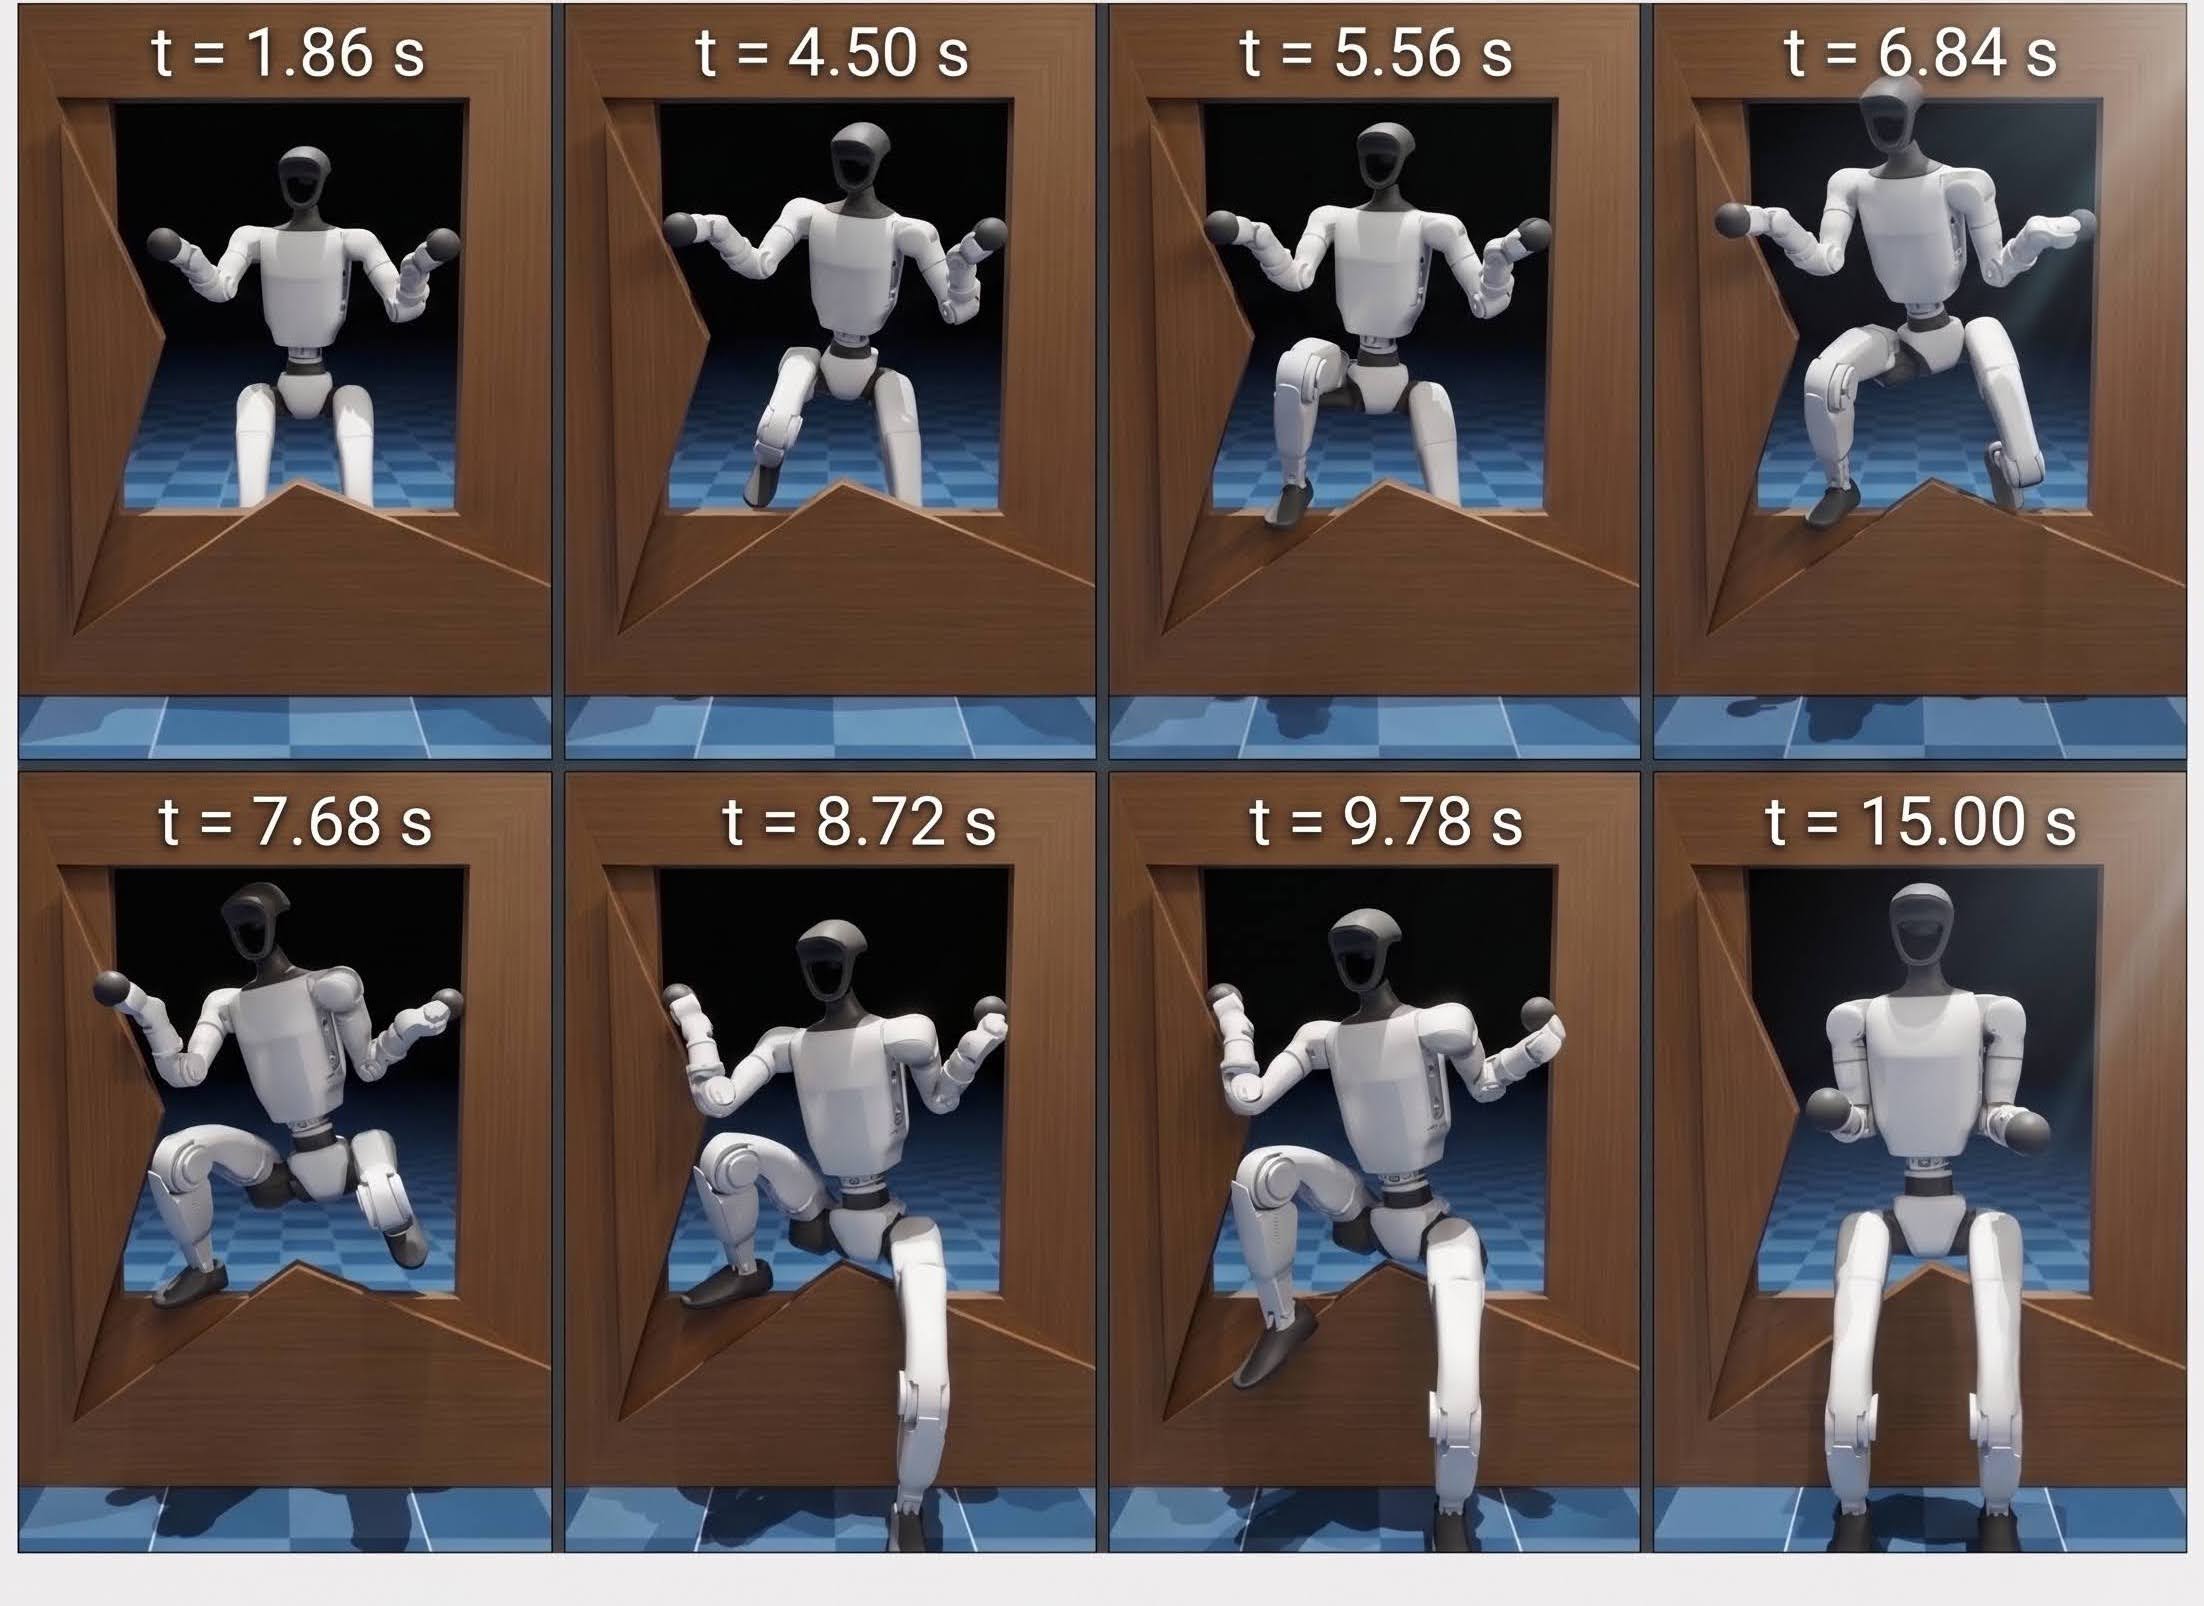
This paper proposes a three-stage whole-body planning framework for humanoid locomotion in confined spaces. It formulates kinematic path planning over reachable rigid-body volumes with differentiable collision avoidance, and uses the resulting plans to guide a full-order trajectory optimizer. A residual RL policy is trained for robust online execution, validated on the Unitree G1 humanoid in benchmark testbeds with restricted confinement ratios.
中文摘要: 本文提出了一种用于类人机器人在狭窄空间中运动的三阶段全身规划框架。该框架直接在可达的刚体体积上进行运动学路径规划,并集成了可微碰撞避免,从而合成考虑体积信息的引导路径,为全阶轨迹优化器提供高质量参考。在此基础上,训练残差强化学习策略以实现在线鲁棒执行。在Unitree G1类人机器人上,针对超过NIST应急响应标准的三个基准测试平台进行了验证,实现了受限空间比(Cr<1.5)。该方法在12至18秒的复杂任务中生成可行轨迹,而标准基线方法失败,同时学习到的策略在物理模拟中的广泛域随机化下能够成功跟踪这些计划。
💬 Directly addresses whole-body control and RL-based motion control for legged robots, with a clear methodological pipeline and strong validation.
💬 直接针对腿足机器人的全身控制和基于RL的运动控制,方法流程清晰,验证充分。
Why read it / 推荐理由: Offers a state-of-the-art whole-body planning and residual RL framework that is directly transferable to modular legged platforms. 提供了一种最先进的全身规划与残差RL框架,可直接迁移到模块化腿足平台。
2. Hip Energized Monopedal Hopping
髋关节激励的单足弹跳
Authors / 作者: Shane Rozen-Levy, Griffon McMahon, Daniel Koditschek
arXiv: 2608.10387 · PDF
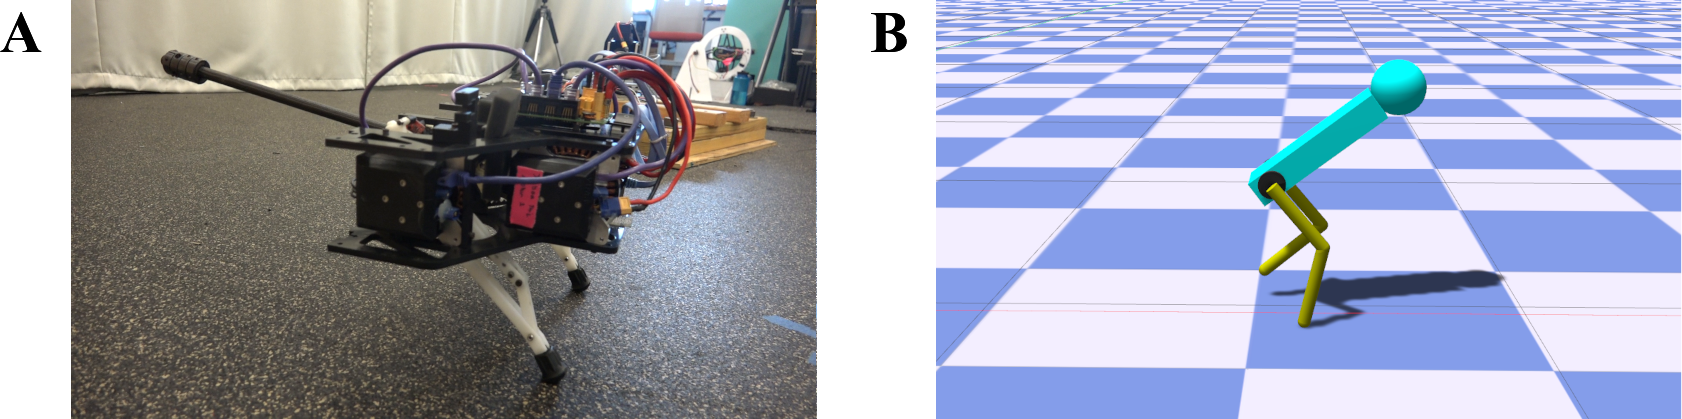
This paper presents a novel stepping strategy for pitch-unlocked planar monopeds, where reaction torques from pitch stabilization are recruited to add energy to the gait. A new stepping policy adjusts energy distribution to achieve desired fore-aft speed and apex height. Hybrid averaging yields closed-form fixed points and eigenvalues, validated in simulation and physical experiments on the Penn Jerboa.
中文摘要: 本文提出了一种针对俯仰自由度的平面单足机器人的新型步态策略,利用俯仰稳定控制产生的反作用扭矩来主动补偿阻尼带来的能量损失,从而为步态注入能量。通过调整质心位置,控制器增大俯仰稳定力矩,进而增加步态能量。新的落地策略调节径向和角度自由度之间的能量分配,以抵消散耗并实现用户指定的稳态前后速度和腾空高度。混合平均分析给出了固定点和特征值的闭式解,揭示了物理与控制参数对性能的影响。在五连杆双足模型和Penn Jerboa的仿真及物理实验中,该控制器实现了1.02至1.77 m/s的稳定运动速度。
💬 A creative energy-injection mechanism for legged locomotion with strong analytical grounding and real-robot demonstration.
💬 一种创造性的腿足运动能量注入机制,具有坚实的理论分析和真实机器人验证。
Why read it / 推荐理由: Demonstrates how passive dynamics and control can be synergistically used to achieve fast and stable hopping, relevant to the design of efficient leg modules. 展示了如何协同利用被动动力学与控制来实现快速稳定的弹跳,对高效腿模块设计具有参考价值。
3. Topological Feasibility Guarantees for Differentiable Predictive Control
可微预测控制的拓扑可行性保证
Authors / 作者: Guangyu Wu, Ján Drgoňa
arXiv: 2608.10332 · PDF
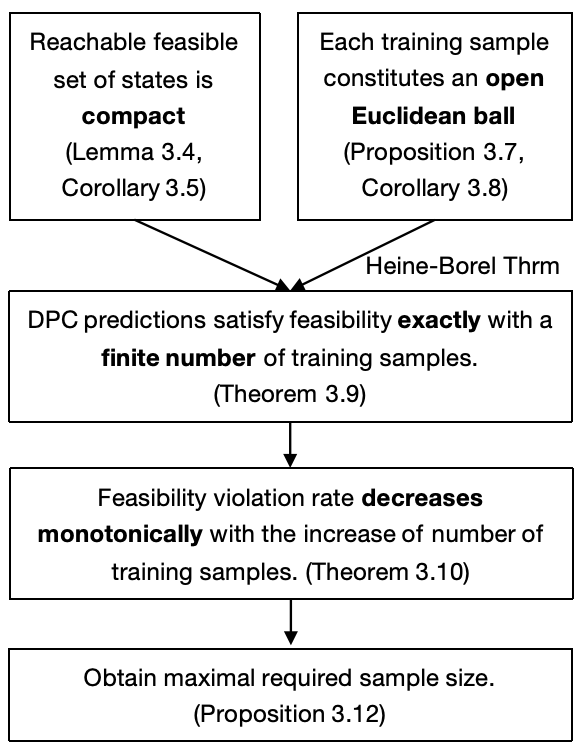
This paper establishes deterministic feasibility guarantees for differentiable predictive control (DPC) without online safety filters. Using a novel topological analysis of the reachable safe set, it derives strict guarantees from a finite number of training samples and proposes a self-supervised loss with Control Barrier Functions. Extensive closed-loop simulations confirm the theoretical findings.
中文摘要: 本文针对可微预测控制(DPC)建立了无需在线安全滤波器的确定性可行性保证。通过对诱导可达安全集的拓扑分析,从有限训练样本中推导出严格的可行性条件,并提出了一种利用控制障碍函数(CBF)的代理损失的自监督离线策略学习策略。该代理损失不仅显著改善了策略训练,还使得能够从有限样本中获得严格的确定性可行性保证。闭环仿真实验验证了理论结果,表明该方法在保证安全性的同时提升了策略性能。这项工作为离线学习的MPC策略提供了安全性保证的新途径,对腿足机器人的实时控制具有潜在应用价值。
💬 Provides rigorous safety guarantees for learning-based MPC, a crucial missing piece for reliable legged robot control.
💬 为基于学习的MPC提供了严格的安全保证,是腿足机器人可靠控制中关键缺失的一环。
Why read it / 推荐理由: The feasibility guarantee methodology is directly applicable to certifying learned controllers for modular legged robots. 该可行性保证方法可直接用于认证模块化腿足机器人的学习控制器。
4. Risk-Aware Kinodynamic Motion Planning Under Uncertainty For Safe Navigation on Planetary Environments
行星环境下考虑不确定性的风险感知运动学动力学运动规划
Authors / 作者: Sachin Sunil Kelkar, Tanmay Dokania, Yashwanth Kumar Nakka
arXiv: 2608.11175 · PDF
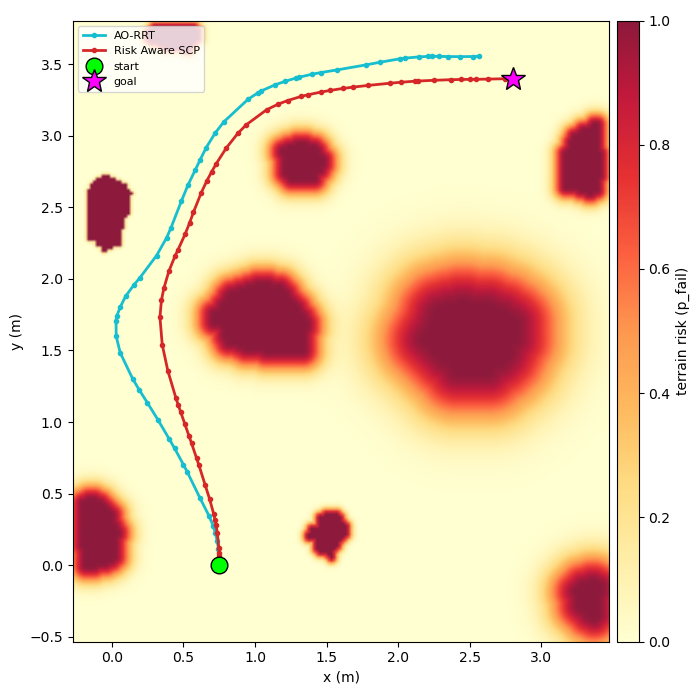
This paper addresses cost-optimal kinodynamic motion planning with risk awareness for autonomous exploration. A sampling-based planner (AO-RRT) generates risk-aware trajectories, which are then optimized via sequential convex programming with a Conditional Value-at-Risk (CVaR) metric. Simulations and hardware experiments show over 97% risk reduction.
中文摘要: 本文针对自主探索中的运动规划问题,提出了一种风险感知的代价最优运动动力学规划方法。方法分为两步:首先采用基于采样的AO-RRT规划器生成动态可行、风险感知且渐近代价最优的轨迹;随后将运动规划转化为非线性优化问题,并使用序列凸规划(SCP)求解,以AO-RRT轨迹作为初始解。通过使用条件风险价值(CVaR)进行风险量化,在仿真和硬件实验中展示了超过97%的风险降低。该方法对于未知地形交互的机器人(如腿足机器人)的安全导航具有重要意义,其风险感知框架可推广到地形力学不确定的场景。
💬 Addresses risk-aware planning under terrain uncertainty, directly relevant to traverse-capability-aware path planning for legged robots.
💬 解决了地形不确定性下的风险感知规划,直接关系到腿足机器人的可穿越能力感知路径规划。
Why read it / 推荐理由: The CVaR-based SCP framework can be adopted to plan safe paths for modular legged robots on uncertain terrain. 基于CVaR的SCP框架可被用于在不确定地形上为模块化腿足机器人规划安全路径。
5. Dual Stress: Runtime Safety Monitoring for Safety-Constrained MPC Navigation
双应力:安全约束MPC导航的运行时安全监控
Authors / 作者: Jamil Chahine, Wenqi Cai, John Abanes, Anthony Tzes
arXiv: 2608.10791 · PDF
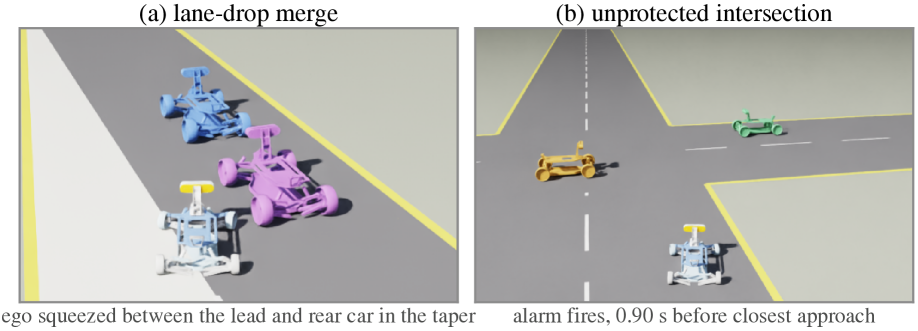
This paper introduces a runtime hazard monitor based on the KKT multipliers of a safety-constrained MPC, producing a ‘dual stress’ signal that complements geometric warnings. In simulations, the stress alarm flags 4.7 times as many collisions missed by a battery of geometric detectors, and combined warning coverage improves significantly.
中文摘要: 本文提出了一种利用安全约束MPC的KKT乘子进行运行时危险监测的新方法。MPC在每一步优化中计算的KKT乘子反映了维持安全所需的边际控制能力,其水平加权和构成“双应力”信号,能够补充传统基于几何量的危险预警。在与十五个几何检测器的对比实验中,双应力信号识别出的被几何检测器遗漏的碰撞数量是反向遗漏的4.7倍(85对18)。两种通道结合后,在制动可行的碰撞场景中,对四分之三的碰撞提前发出警告,而仅使用几何检测器时这一比例不到一半。该方法为安全关键的腿足机器人导航提供了新的监控维度。
💬 A novel use of MPC dual variables for safety monitoring, with clear potential for legged locomotion safety.
💬 将MPC对偶变量创新性地用于安全监控,对腿足运动安全具有明确潜力。
Why read it / 推荐理由: Offers a new safety metric that can enhance existing MPC-based controllers for legged robots with minimal overhead. 提供了一种新的安全度量,可以在最小化开销的情况下增强现有的基于MPC的腿足机器人控制器。