Robotics Digest
Robotics Paper Digest — 2026-07-31
🤖 Scanned 298 new arXiv papers (cs.RO / cs.SY / cs.LG, last 48 h), picked 5 for modular & legged robotics — summarized by DeepSeek.
🤖 扫描了近 48 小时 arXiv(cs.RO / cs.SY / cs.LG)的 298 篇新论文,围绕模块化与足式机器人精选 5 篇 — 由 DeepSeek 生成双语摘要。
1. PAC-MAN: Perception-Aware CBF-RL for Whole-Body Safety in Humanoid Dodgeball
PAC-MAN: Perception-Aware CBF-RL for Whole-Body Safety in Humanoid Dodgeball
Authors / 作者: Lizhi Yang, Junheng Li, Aaron D. Ames
arXiv: 2607.28623 · PDF
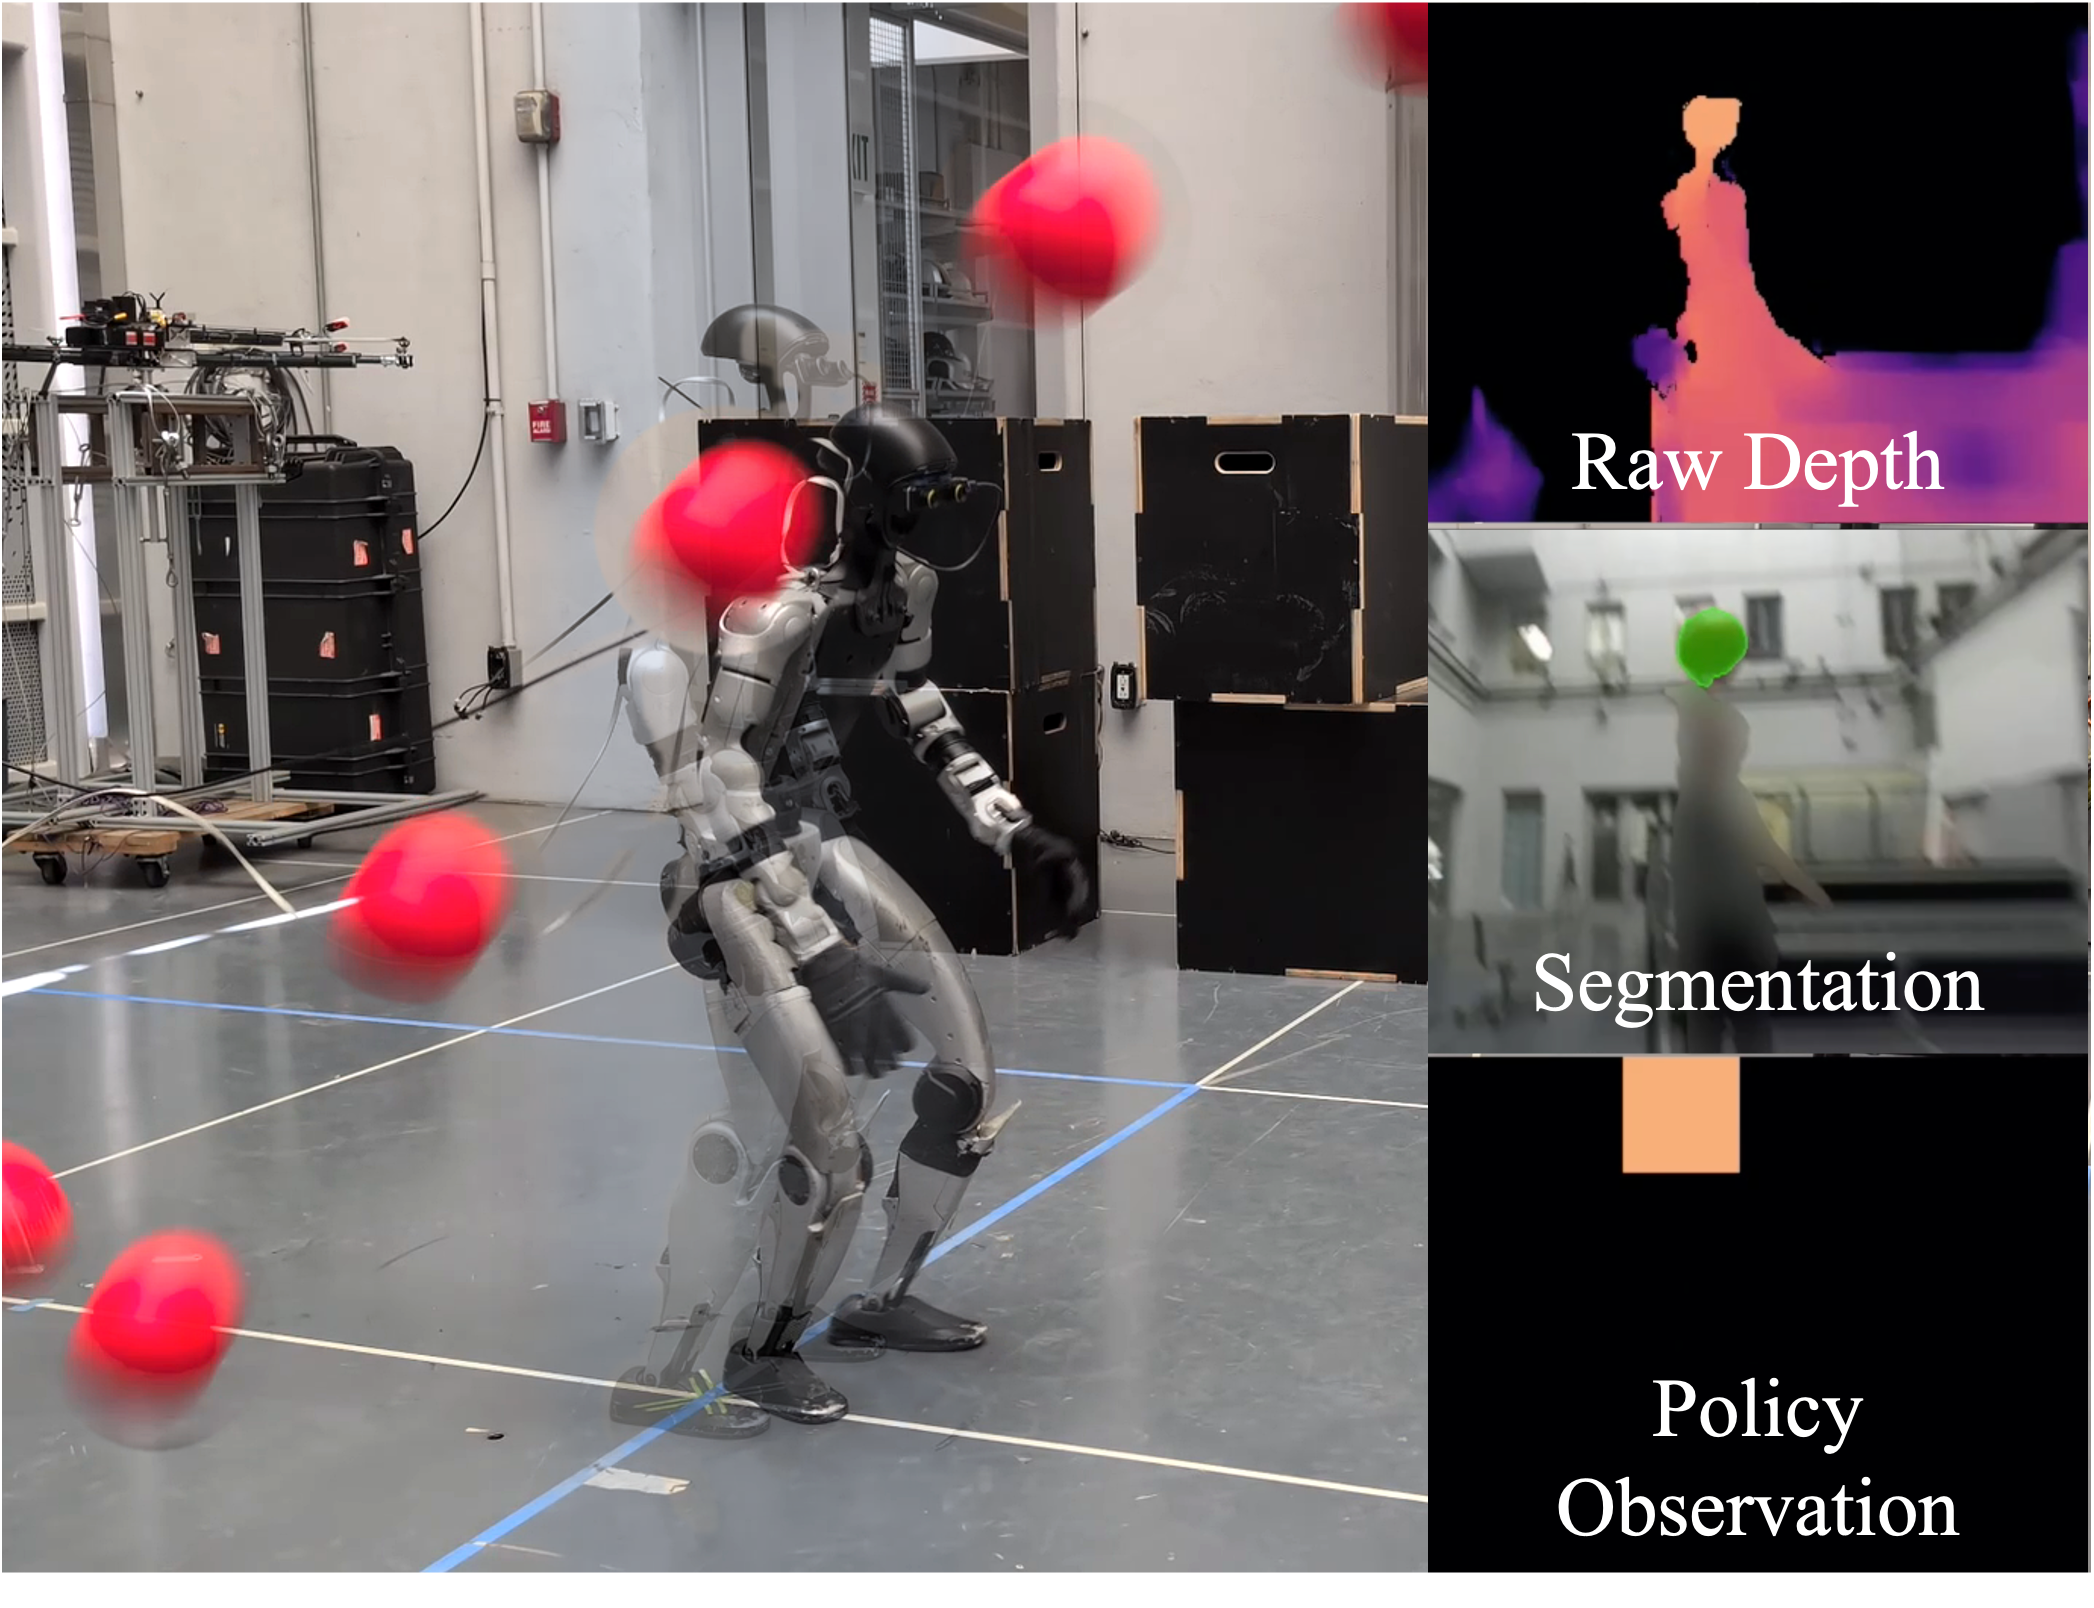
We present PAC-MAN, a perception-aware CBF-RL framework that couples control-barrier safety with deployment-realistic onboard sensing for whole-body humanoid dodgeball. The deployed policy sees the ball only as segmentation-masked depth from a head-mounted camera, while training-time CBF guidance represents clearance to every body link, and an adversarial motion prior regularizes the resulting evasive reflexes. We evaluate on a controlled any-link contact benchmark with seeded throws in two regimes: single throws and a deployment loop in which the robot walks back to its station and recovers b
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
2. TEA-AgriVLN: Traversability Estimation Alarm for Agricultural Vision-and-Language Navigation
TEA-AgriVLN: Traversability Estimation Alarm for Agricultural Vision-and-Language Navigation
Authors / 作者: Xiaobei Zhao, Xingqi Lyu, Xin Chen, Xiang Li
arXiv: 2607.28474 · PDF
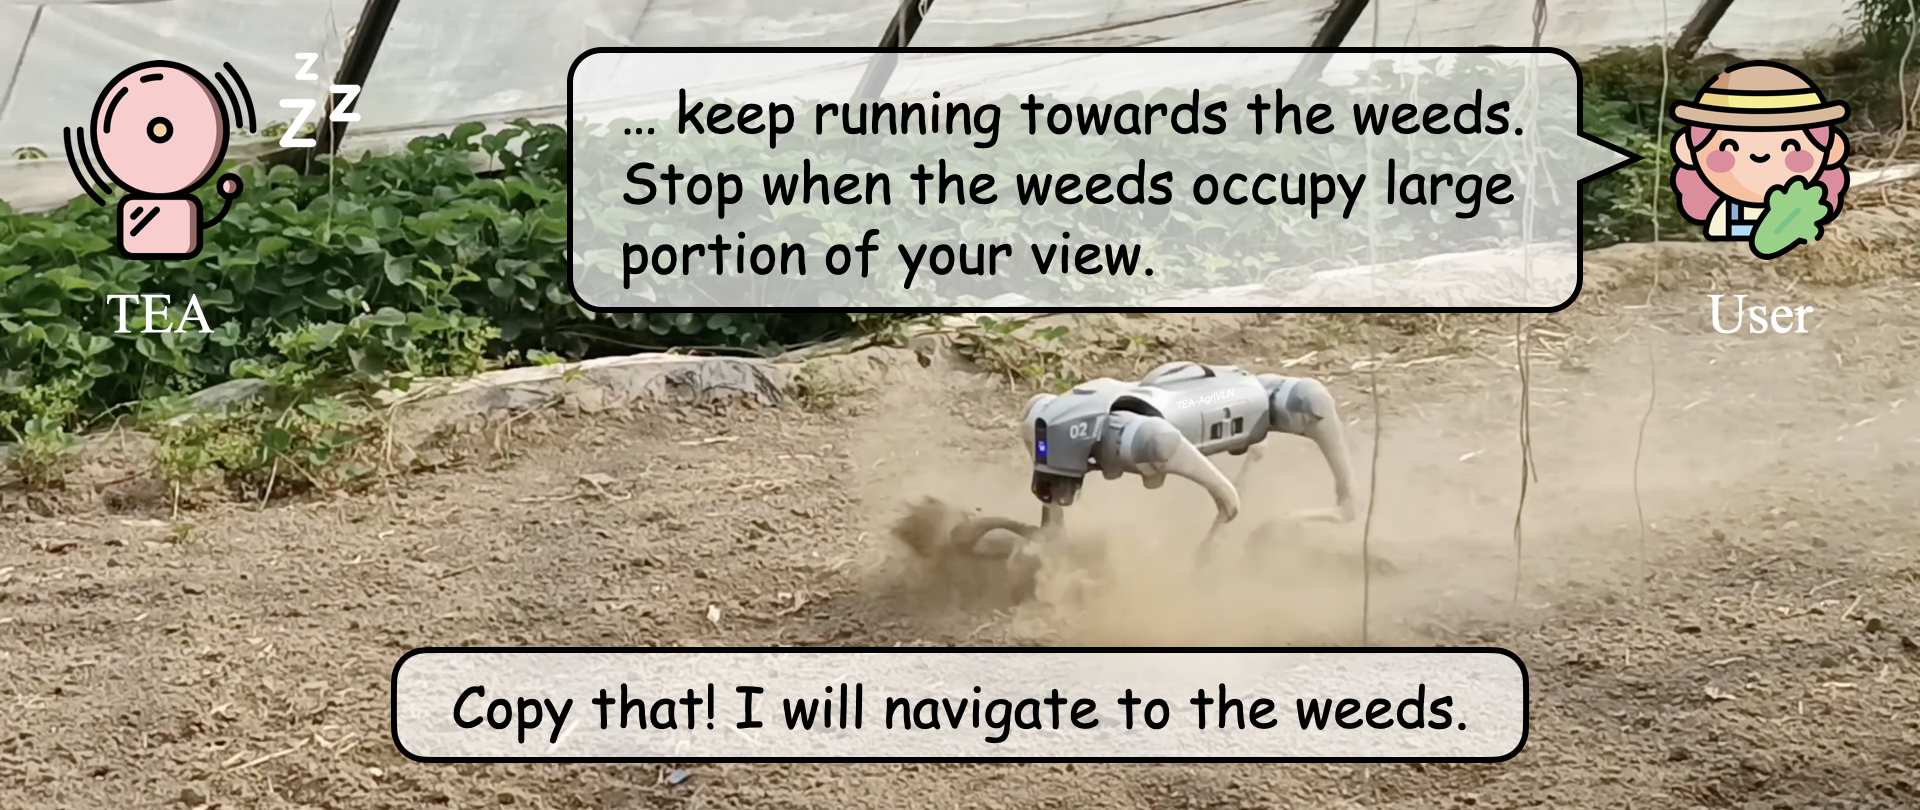
Vision-and-Language Navigation in Continuous Environments (VLN-CE) requires an agent to follow a natural language instruction, predicting a sequence of low-level actions to navigate a robot from a starting point to a target location. The A2A benchmark and the AgriVLN method pioneeringly extended VLN-CE from indoor scenes to agricultural scenes, while we observed a challenging distinction: In indoor scenes, whether a zone is traversable tends to be clear to classify, such as wood floors are traversable but concrete walls are not. In agricultural scenes, however, this issue tends to be ambiguous
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
3. RL$^2$-VLA: Adaptive RL Latent Compositional Steering with Test-Time Scaling for Vision-Language-Action Models
RL$^2$-VLA: Adaptive RL Latent Compositional Steering with Test-Time Scaling for Vision-Language-Action Models
Authors / 作者: Derek Ming Siang Tan, Shailesh Shailesh, Srikrishna Iyer, William Wei Jie Teo, Yuanliang Ju, Qiao Gu et al.
arXiv: 2607.26991 · PDF
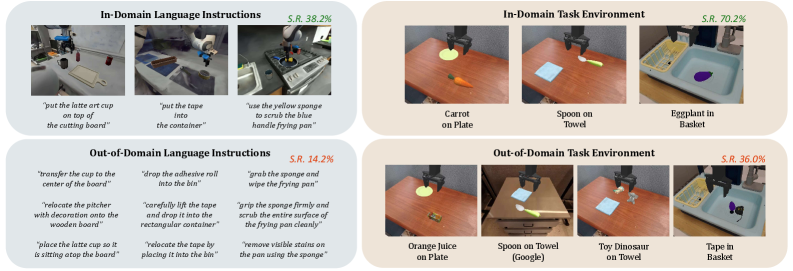
Despite the impressive visuomotor capabilities enabled by Vision-Language-Action (VLA) models, their performance often degrades on challenging and out-of-domain tasks. Recent test-time steering and scaling methods improve performance without extensive data collection and retraining, but action samples often remain concentrated around similar behaviors and therefore inherit correlated failure modes. Moreover, existing methods apply the same intervention strategy at every timestep, regardless of whether the base policy is already likely to succeed. To address these limitations, we introduce $RL^
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
4. Risk-Aware Motion Planning with Learned Trajectory Primitives and Probabilistic Safety Assessment
Risk-Aware Motion Planning with Learned Trajectory Primitives and Probabilistic Safety Assessment
Authors / 作者: Marc Kaufeld, Dian Zhuang, Johannes Betz
arXiv: 2607.26802 · PDF
This paper presents a radial basis function network (RBFN)-informed motion planning framework for safe and efficient urban autonomous driving. The proposed approach combines RBFN-based candidate trajectory generation with an analytic collision probability assessment and optimization-based trajectory refinement. The network learns jerk-minimal trajectories, enabling the MPC to operate within a reduced and dynamically consistent search space. Candidate motion primitives are selected based on an accurate probabilistic risk measure. This design decreases solver complexity while preserving safety a
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。
5. RoboBRIDGE: A Modular Framework for Bridging Policies to Robust Real-World Robotic Agents
RoboBRIDGE: A Modular Framework for Bridging Policies to Robust Real-World Robotic Agents
Authors / 作者: Sihyung Yoon, Minjong Yoo, Sanghyun Ahn, Seojeong Choi, Honguk Woo
arXiv: 2607.27881 · PDF
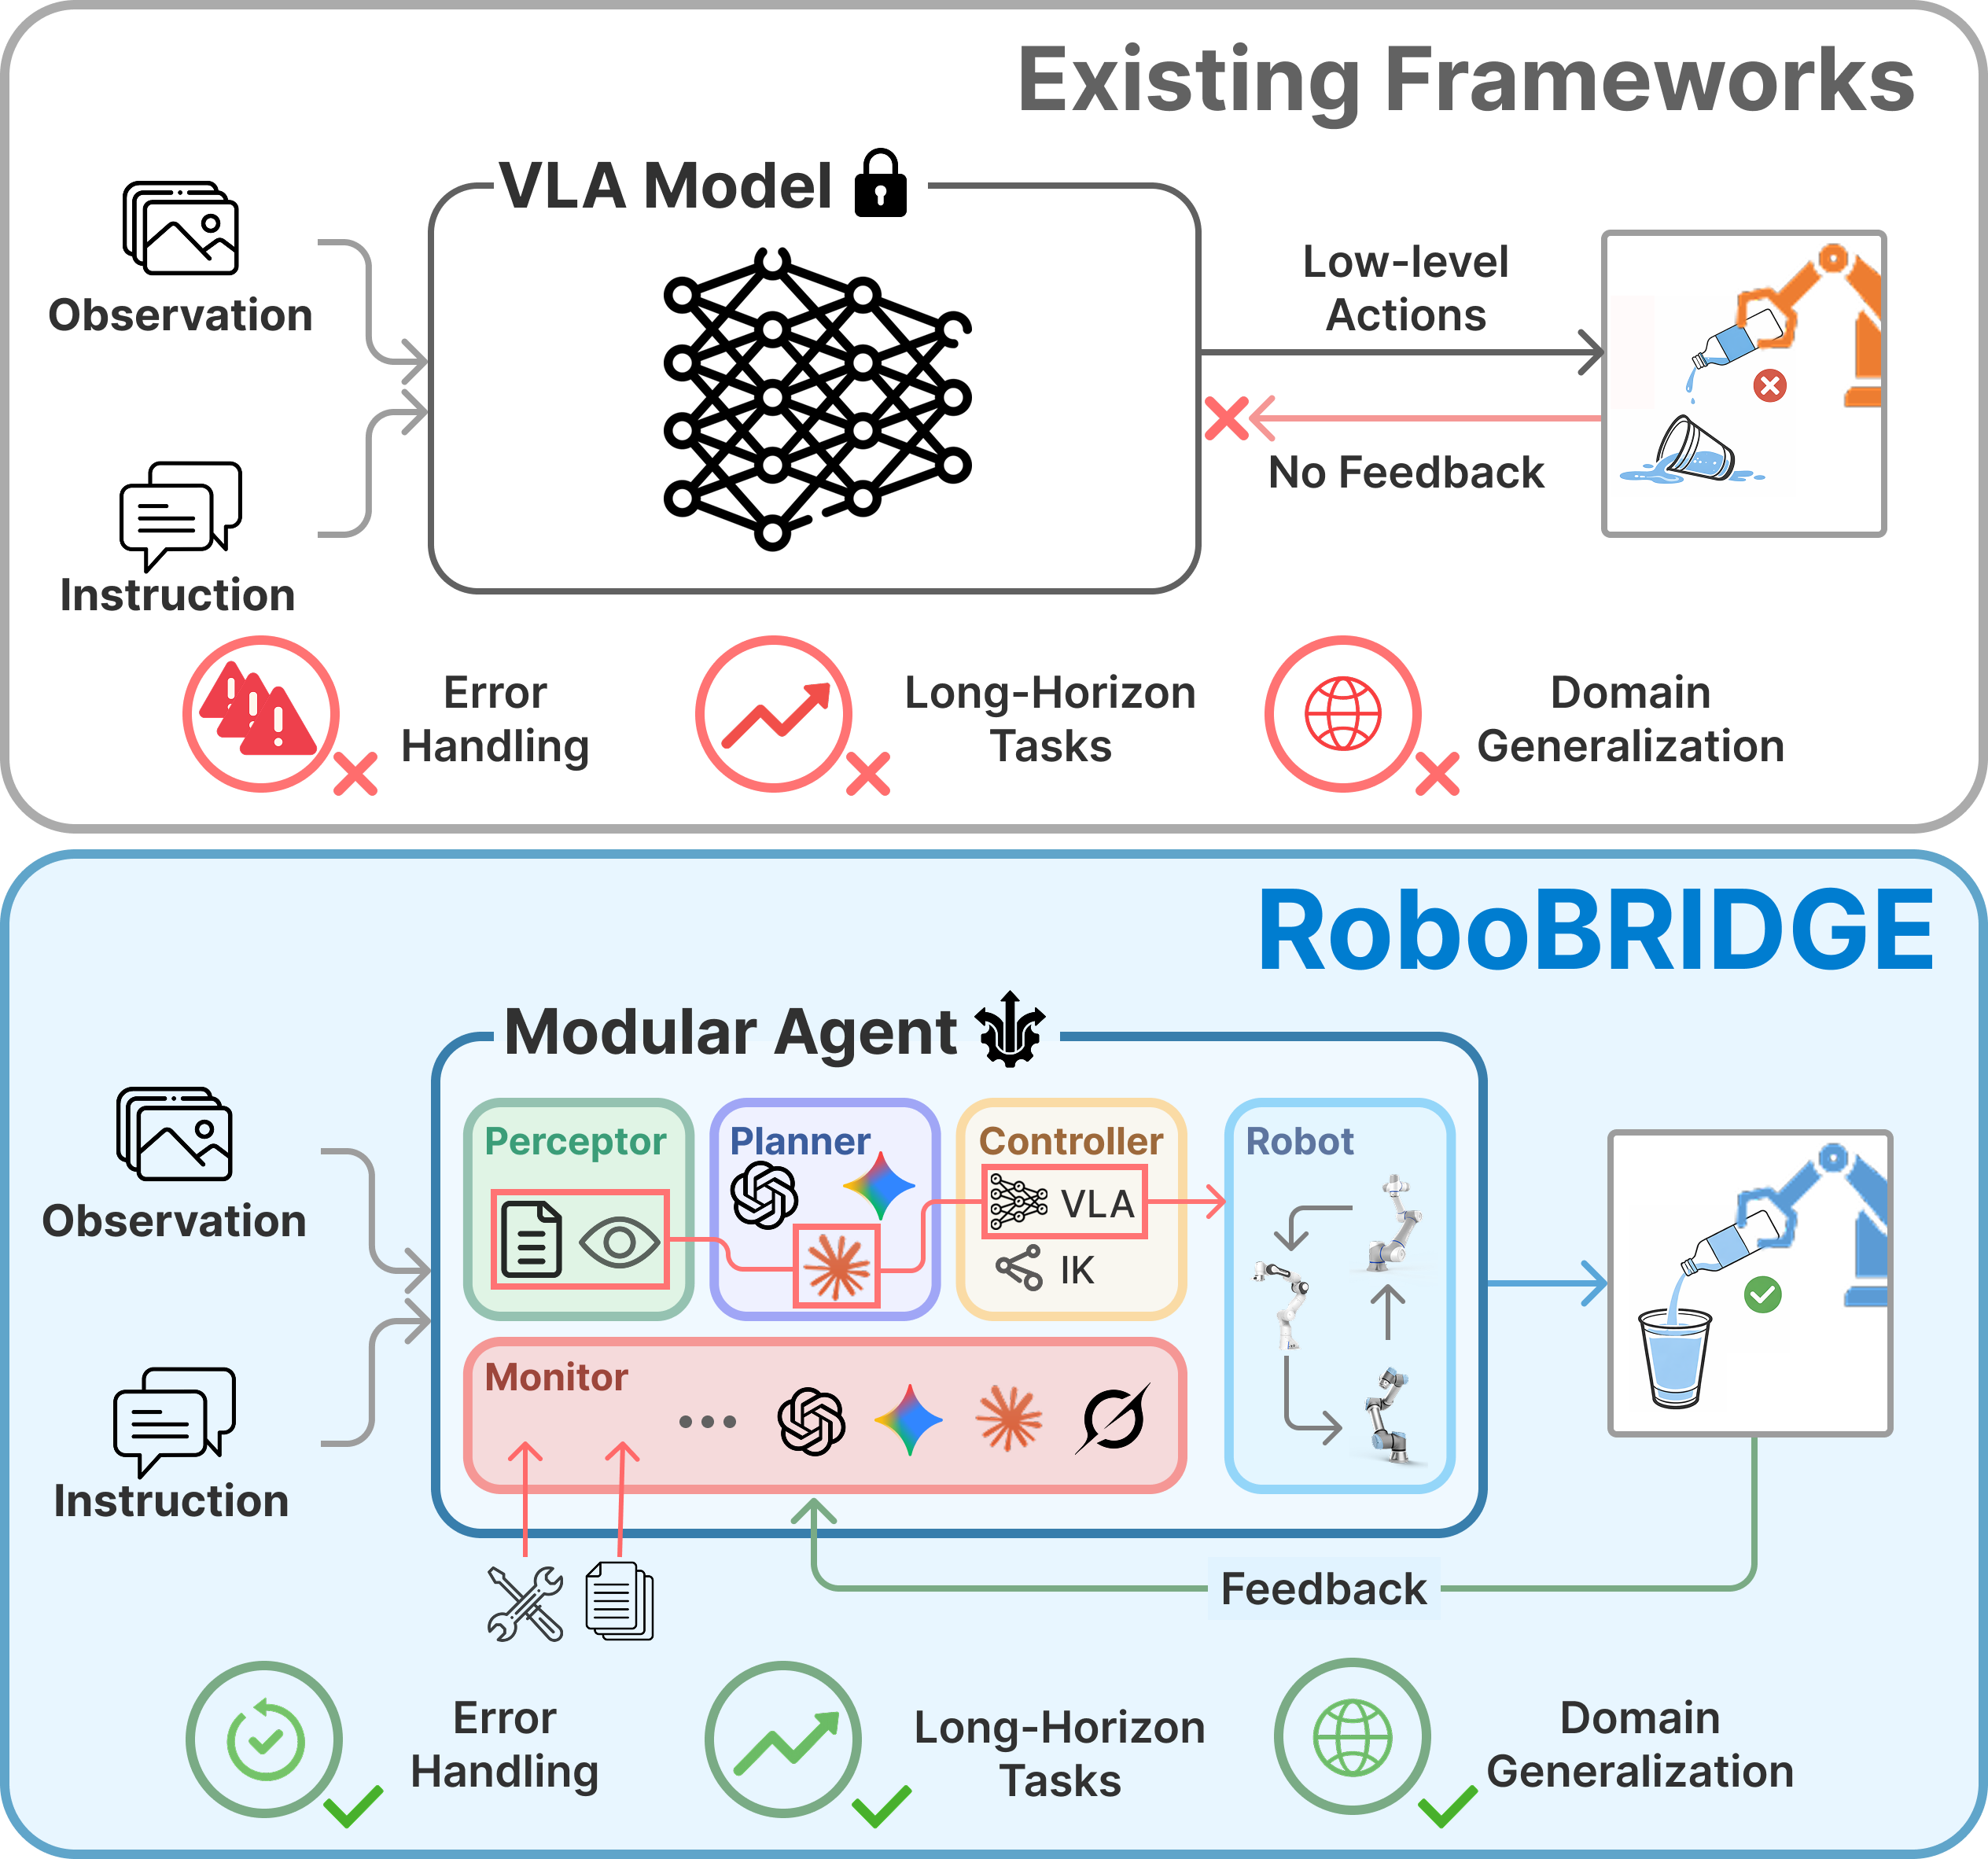
Vision-Language-Action (VLA) models have attracted growing interest as a scalable approach to robotic manipulation. While these models are effective action predictors, deploying them as robotic agents exposes critical gaps: no mechanism for failure recovery, inconsistent execution over long horizons, and limited robustness to shifts in observations, tasks, or embodiments. Existing solutions address these limitations individually through model retraining or environment-specific modules, yet what is needed is a general framework that systematically transforms a pretrained VLA into a robotic agen
中文摘要: (自动翻译暂不可用 — 请阅读英文摘要。)
💬 Selected automatically by relevance score.
💬 由相关性评分自动选出。
Why read it / 推荐理由: High keyword relevance to modular legged robotics. 与模块化足式机器人方向的关键词高度相关。